Open catalogue · hardware atlas of endovascular robots
Every catheter and guidewire robot, described the same way.
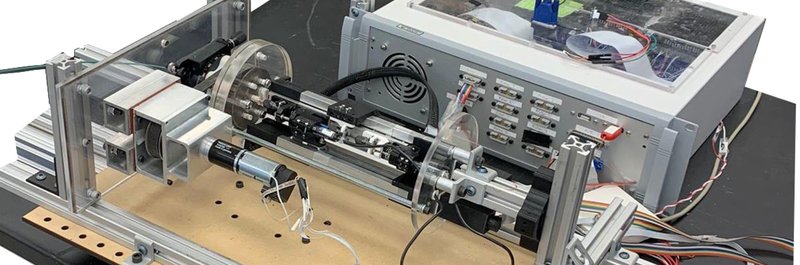
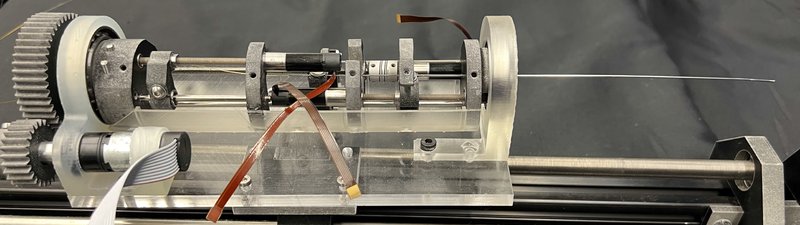
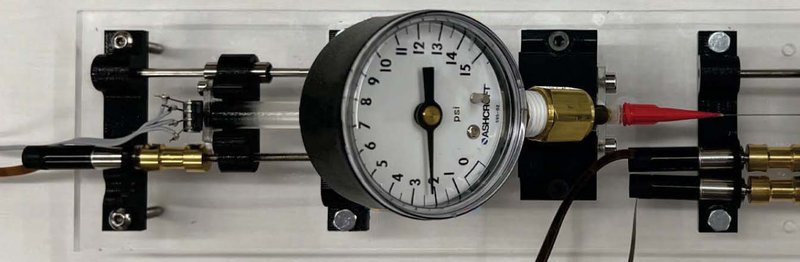
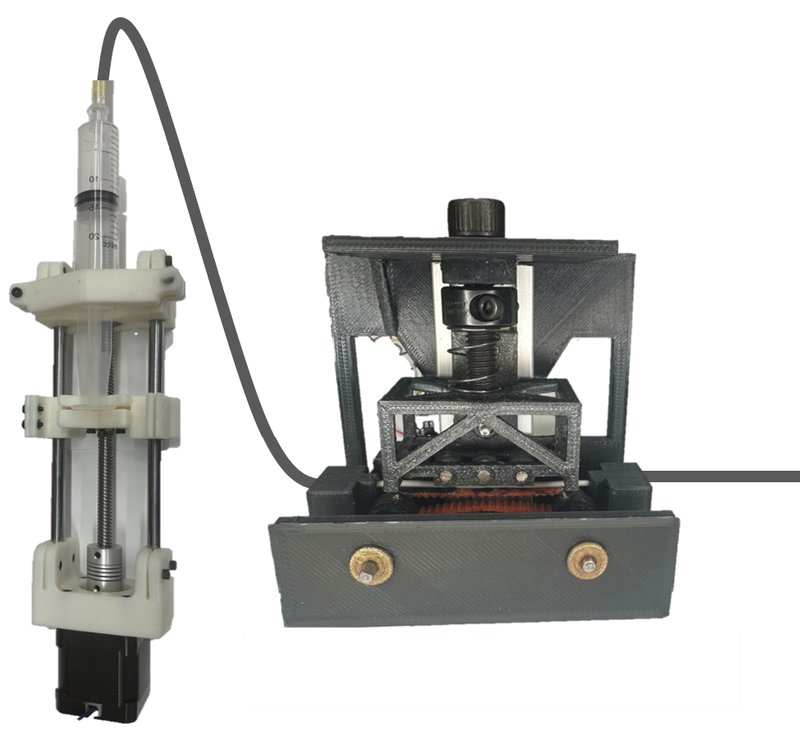
The Catheter Robot Atlas is an open catalogue of the robots that push and twist catheters and guidewires inside blood vessels: what each one looks like, how it drives the devices, and how far it has been tested.
Companion catalogue to the review Endovascular Catheter and Guidewire Robots: A Hardware Atlas (in preparation).
Browse the 126 robots →Schema & APIAdd or fix a recordFour families
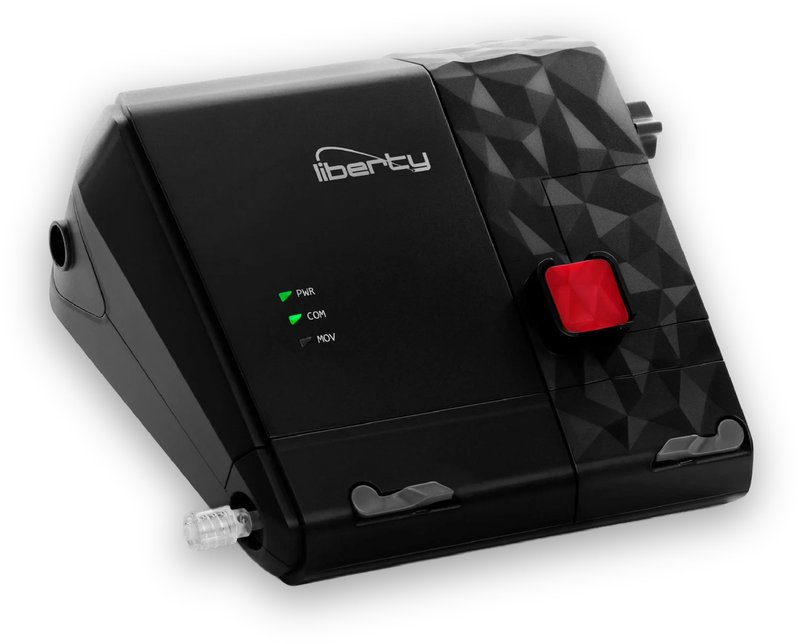
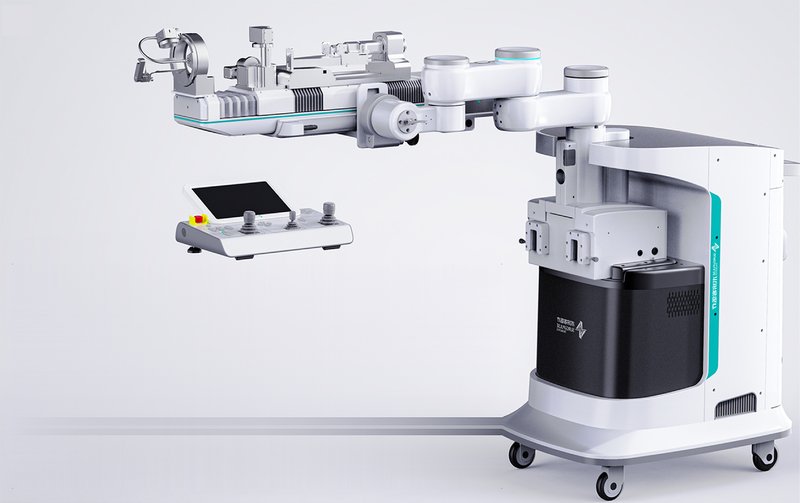
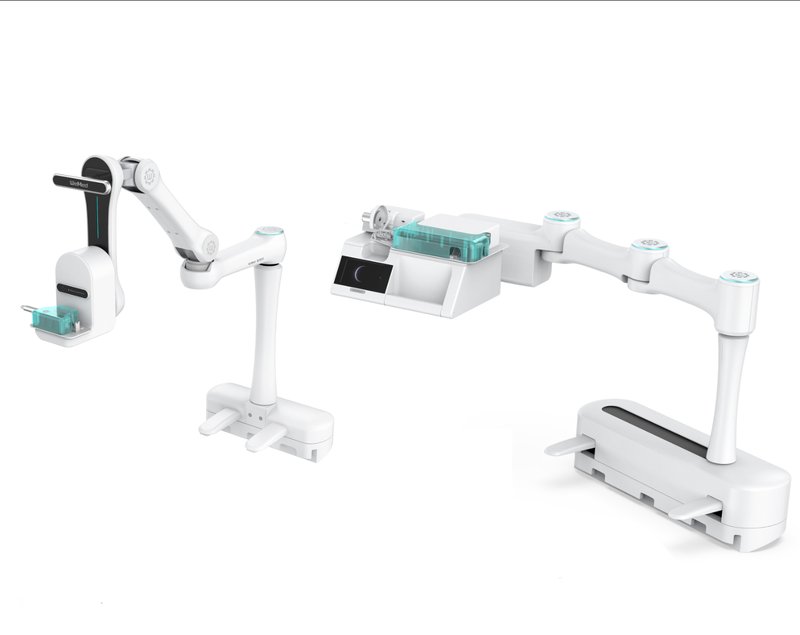
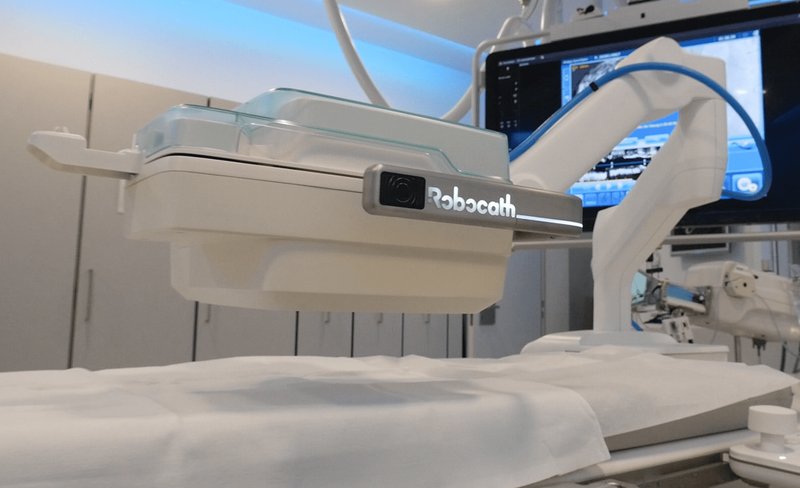
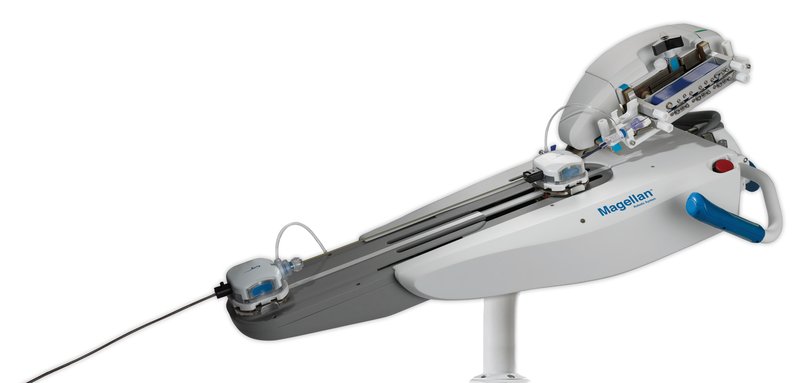
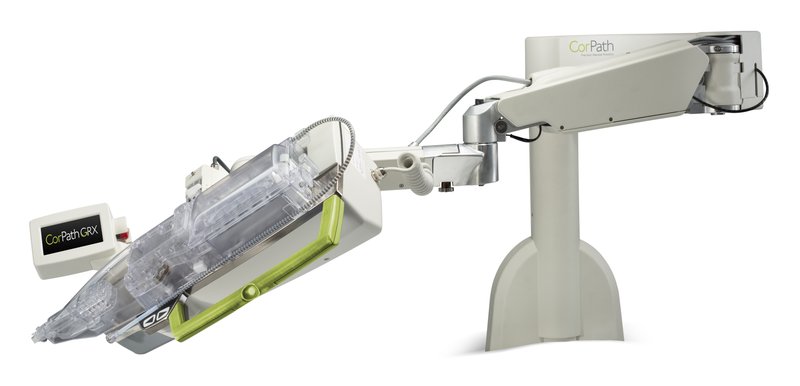
Commercial and clinical-stage systems
Products and clinical-stage systems from companies, including commercial magnetic systems.
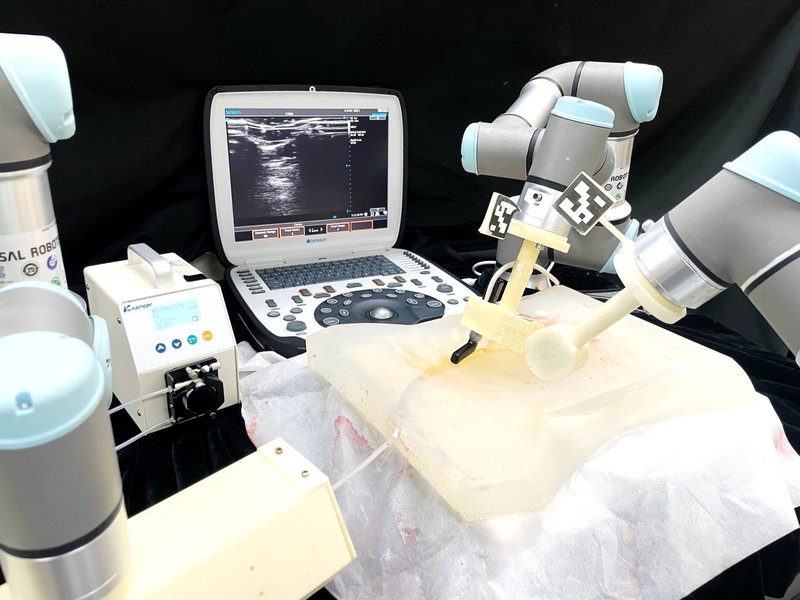
Academic bedside robots
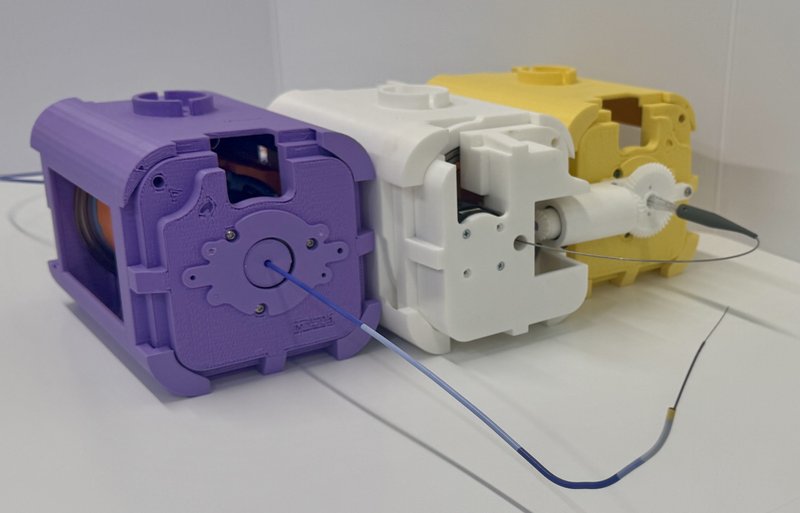
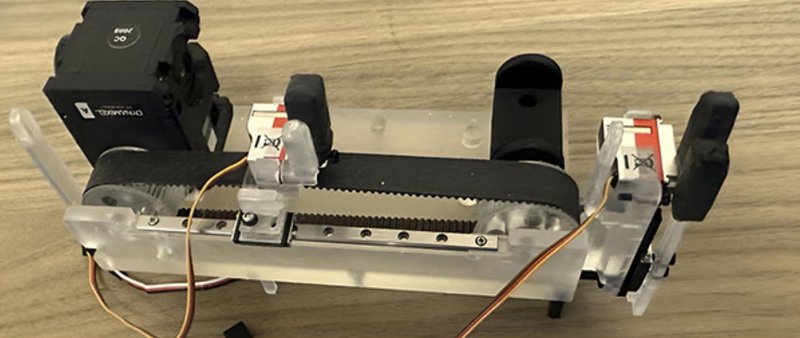
Research robots at the bedside that push and twist catheters and guidewires.
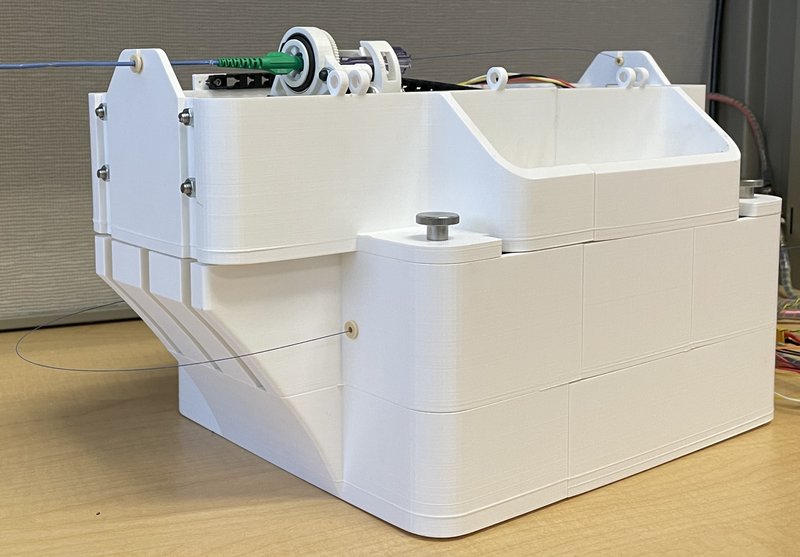
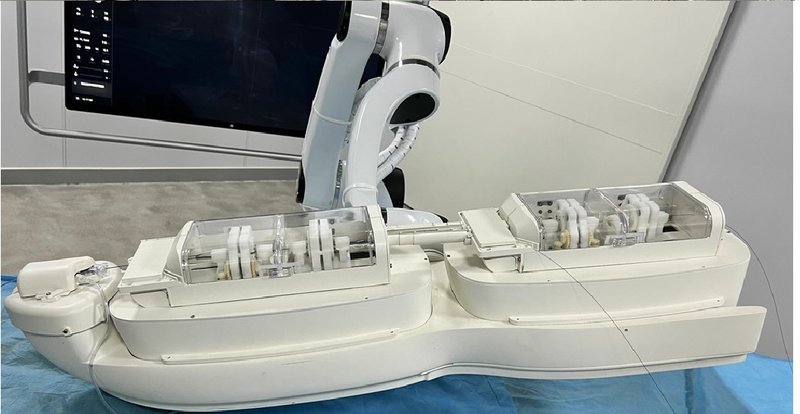
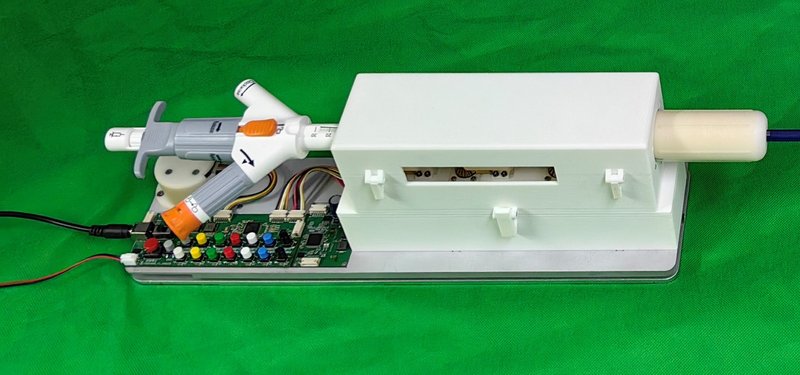
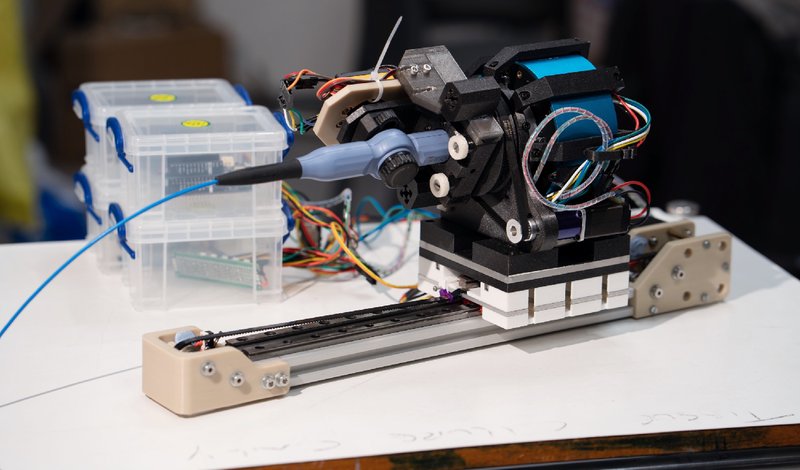
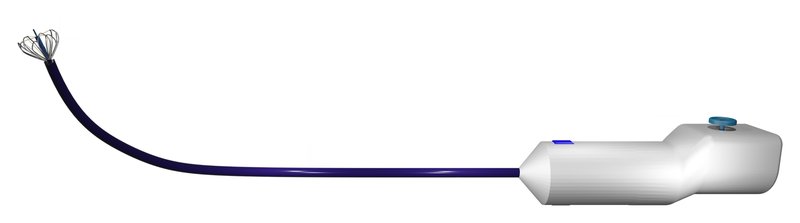
Actuated-tip devices
Devices whose own tip bends (tendons, shape-memory alloy, fluid, notched tubes), with or without a bedside drive.
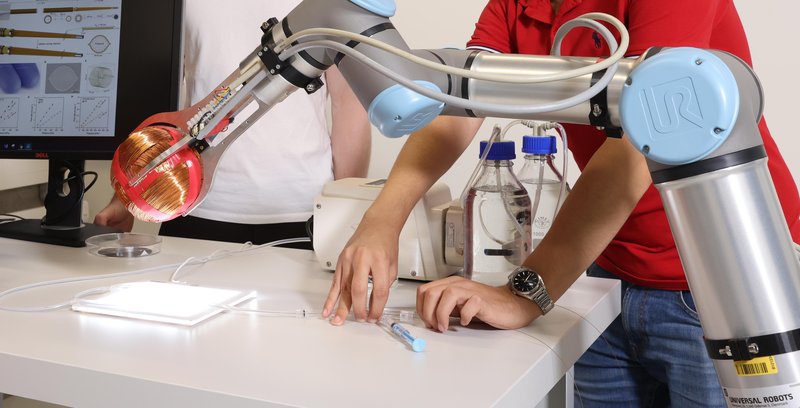
Magnetic navigation
Academic systems that steer a magnetic device tip with an external field.
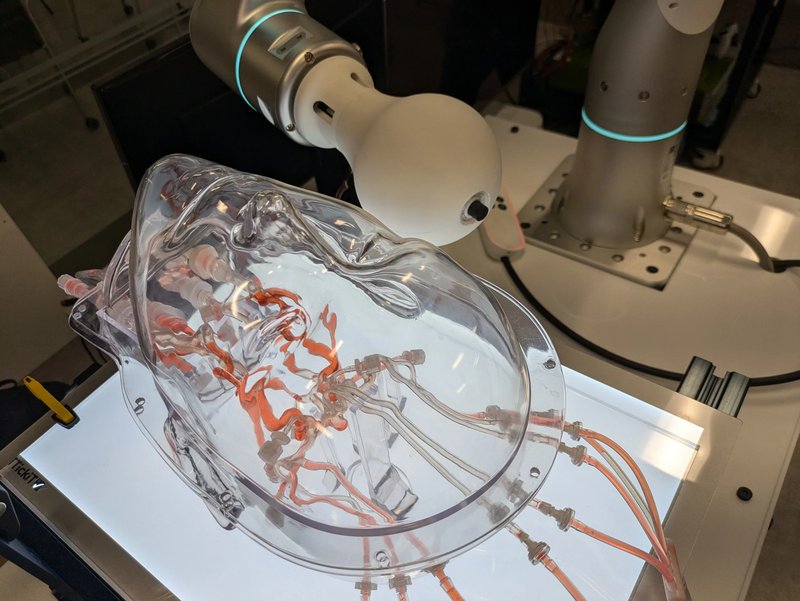
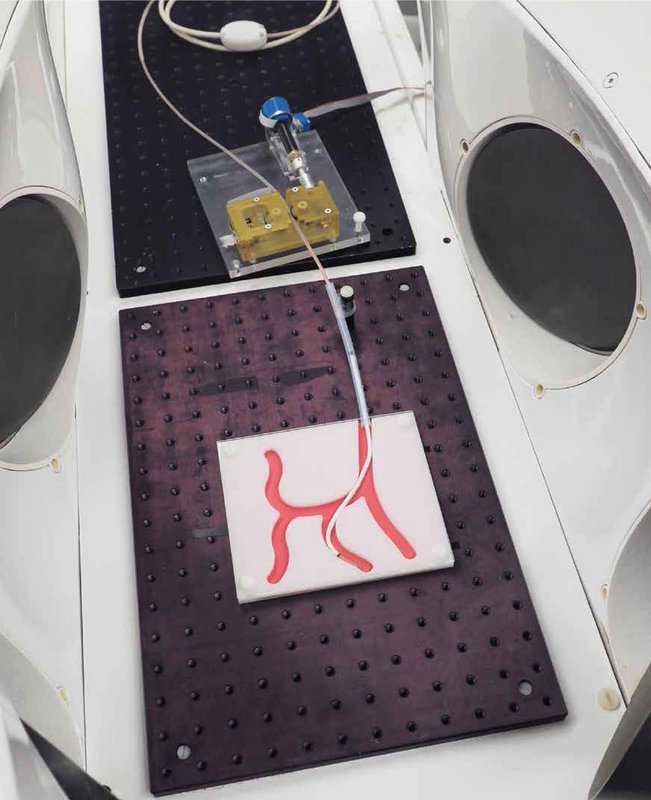
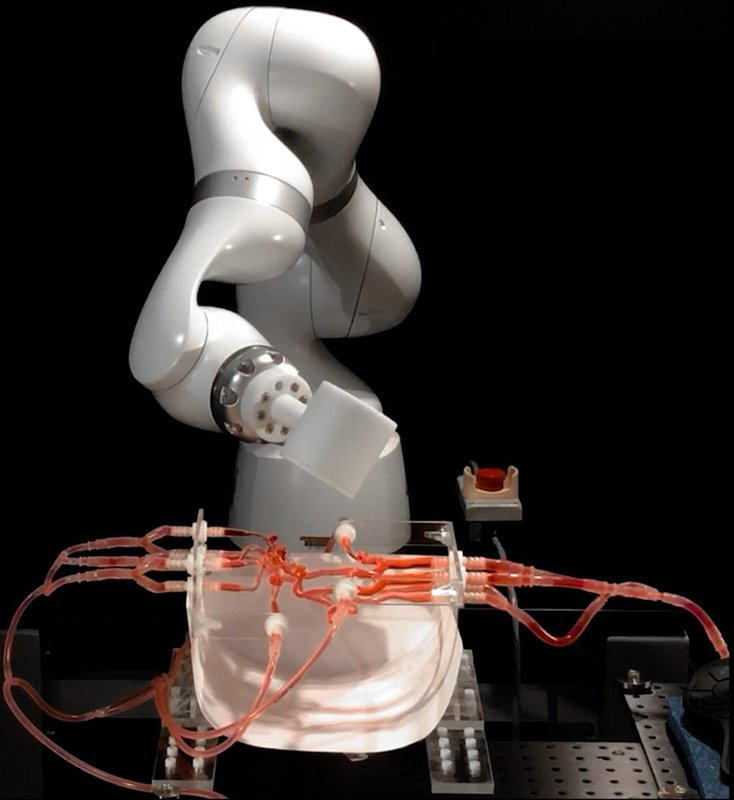
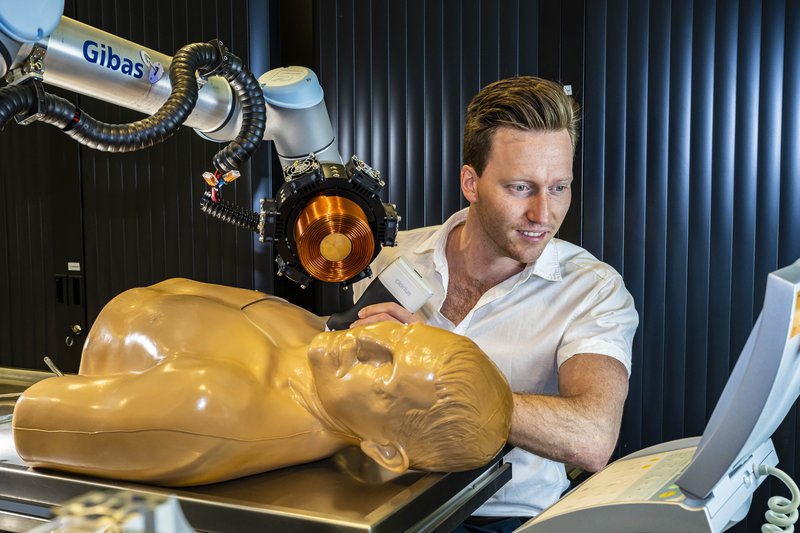
How it works
One schema
Compare before you read
Every robot is one record with the same fields: devices driven, degrees of freedom, push and twist mechanism, sensing, sterility, the highest level of testing, and whether a simulation-trained controller has run on it. A value the sources do not report is written N.R., never guessed.
Linked to the source
Every field has a paper behind it
Records cite their papers by DOI and say how deeply each was read (full text, abstract, web page). Pictures are shown only when their licence allows it; otherwise the record links to the picture at its source.
Machine-readable
One JSON file, no key
The whole catalogue is api/robots.json and robots.csv, validated against a JSON Schema, with schema.org markup for dataset search. Read the docs.
Where this is going
Now
Catalogue what exists
126 robots from two seed papers, citation snowballing and logged searches, each checked against its full text where one was available.
Next
Open it for corrections
Records as YAML files in a public repository, so a lab can add its robot or fix a number with a pull request; more pictures cleared with their owners.
Long term
Numbers every robot reports
A short common list (stroke, push and twist accuracy, force, sterile barrier, test level) so that new robots arrive with comparable numbers.
Contribute
Built a catheter robot, or found an error?
Each record is one YAML file; adding or fixing one is a pull request checked by python3 tools/validate_records.py.
How to contribute →