Magnetic navigation · cardiomag_fischer2022
CardioMag
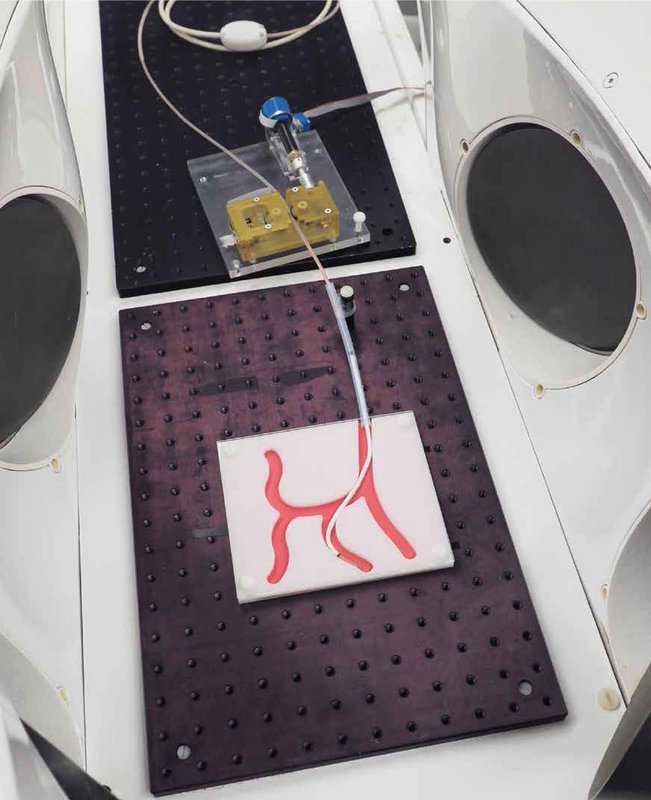
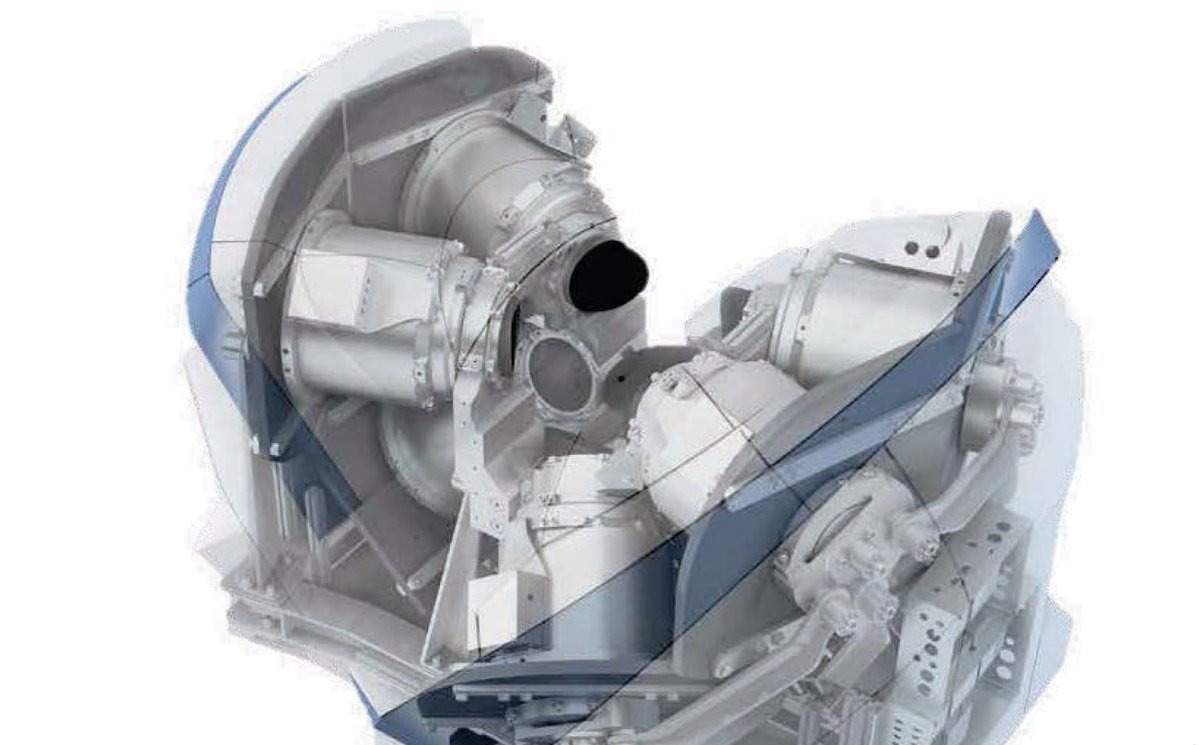
CardioMag eMNS with magnetic catheter and magnetic localisation (ETH)
 1 / 3
- Family
- Magnetic navigation (magnetic-navigation)
- Devices
- own catheter: OD 2.8 mm / ID 2 mm Flexan tube with 3 mm OD x 6 mm permanent magnet at tip, Hall sensor 12 mm behind magnet
- Degrees of freedom
- field direction and gradient from 8 electromagnets; advance by Maxon-motor catheter advancer at 10 mm/s
- Push
- Magnetic
- Twist
- Field direction
- Tested up to
- Phantom
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Phantom
- What was tested
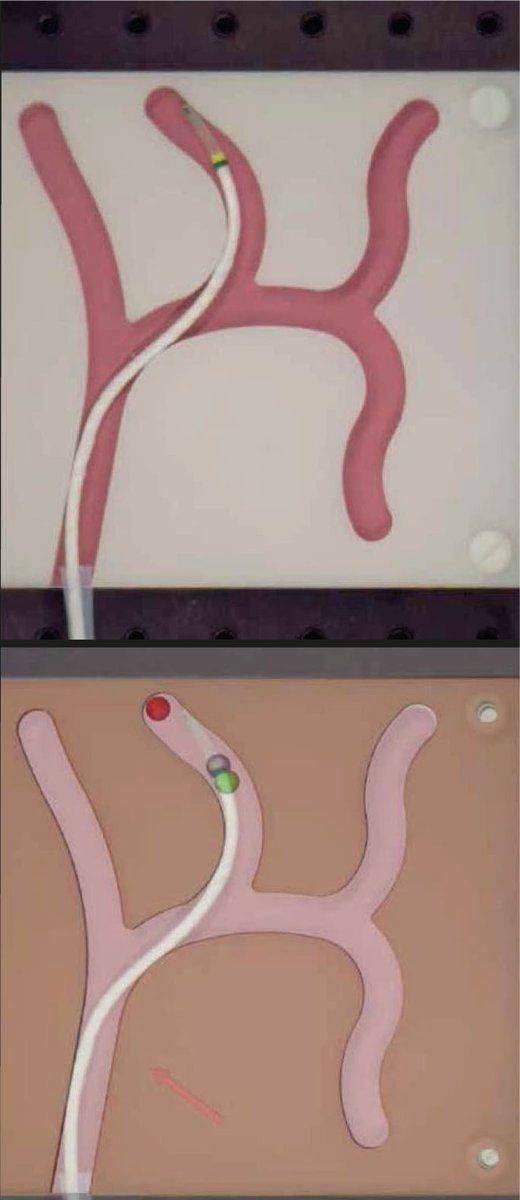
- 2D vascular models a and b; catheter navigated through all branches; localisation tested over 40 trials on path 1-3 of model a
- Key numbers
- eMNS fields 20 mT, gradient 0.15 mT/mm; mean localisation error 3.64 mm (sd 1.61) model b, 2.74 mm with extra field change; model a mean 7.94 mm (sd 2.94), 5.65 mm with extra gradient; position estimate 38.3 ms
Mechanism
- Push (translation)
- magnetic
- Twist (rotation)
- field direction
- Device range
- N.R.
- Target anatomy
- endoluminal, 2D vascular models (24 mm and 11 mm channels)
Sensing and interface
- Force sensing
- Hall-effect sensor for localisation (range +/- 36 mT per axis), no force sensing
- Leader and haptics
- no
- Imaging
- localisation from magnetic field; fluoroscopy minimised; overhead camera as ground truth
- Sterility
- N.R.
Size
- Footprint (mm)
- eMNS about 0.3 m scale bar in Fig. 1 (size N.R. in text)
- Mass (kg)
- N.R.
Simulation
- Simulation model
- linear model of the eMNS (coil currents to field), calibrated; no physics simulator of the catheter
- Sim-trained controller
- none found
Versions
- Lineage
- single (RA-L 2022); same eMNS platform as Navion's academic origin; 2017-19: ETH (Nelson) magnetic catheters in Aeon Phocus: tethered magnet catheter with force and 5-DOF pose control (Chautems 2017 ICRA) and variable-stiffness 2- and 3-segment catheters (Chautems 2017 IROS; 2019 Adv. Intell. Syst.) (Hwang 2020 Figs. 8a, 8g) (hwang2020_review)
Sources
- Using Magnetic Fields to Navigate and Simultaneously Localize Catheters in Endoluminal Environments · IEEE Robotics and Automation Letters, 2022 · doi:10.1109/lra.2022.3181420 [fischer2022_using]
- A review of magnetic actuation systems and magnetically actuated guidewire- and catheter-based microrobots for vascular interventions · Intelligent Service Robotics, 2020 · doi:10.1007/s11370-020-00311-0 [hwang2020_review]
Notes
- Notes
- Centre-line automation plus localisation from field only. Commercial Navion is A4's.
This record
- Read level
- full
- Picture
- fischer2022_using Fig. 3(a) (setup inside CardioMag: advancer, catheter, phantom between the coils) ↗ — licence: publisher copyright (IEEE); grade A
- Picture changes
- native extract, crop left panel only
- Found by
- actuated-tip: Search of actuated-tip and magnetic devices.
- Data
- JSON · YAML:
records/robots/cardiomag_fischer2022.yaml - Correction
- Suggest a correction [repository not created yet]