Actuated-tip devices · bellows_barnes2025
Bellows guidewire
Soft fluidic bellows guidewire with teleoperated drive and imitation-learning policy
 1 / 6
- Family
- Actuated-tip devices (actuated-device)
- Devices
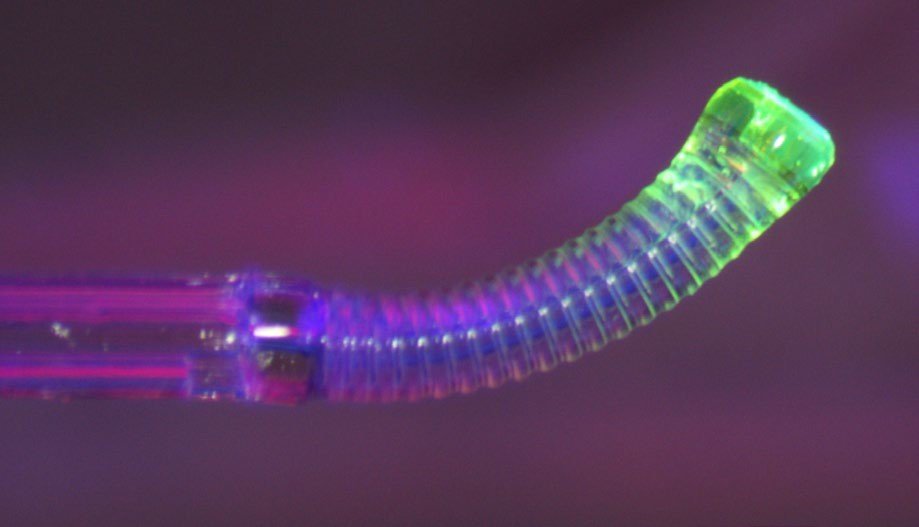
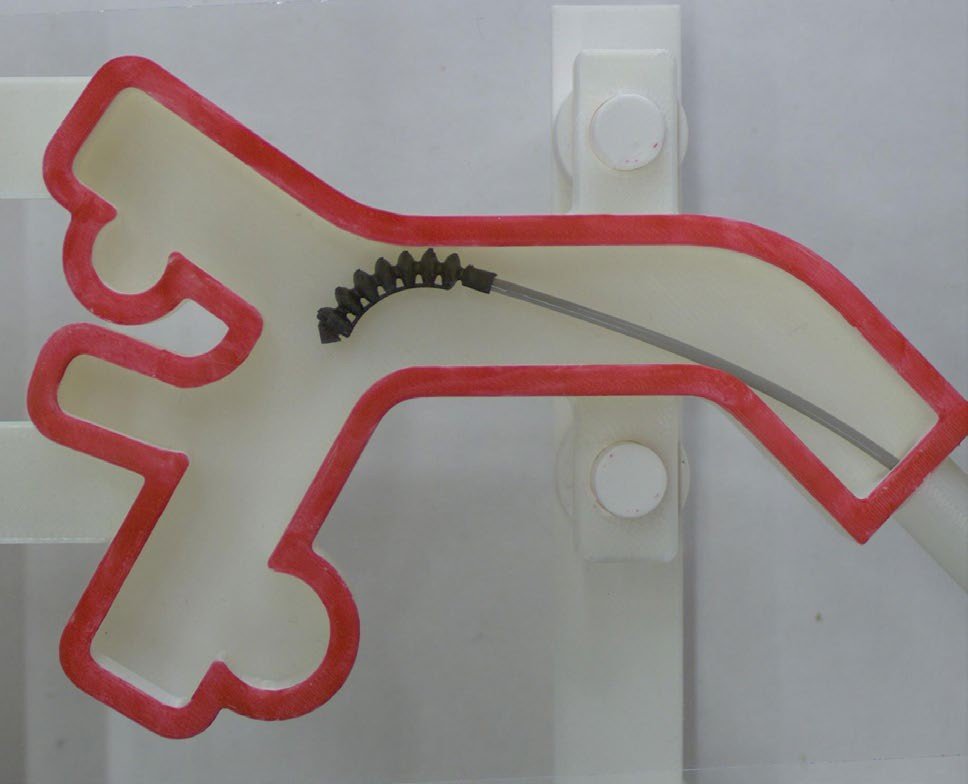
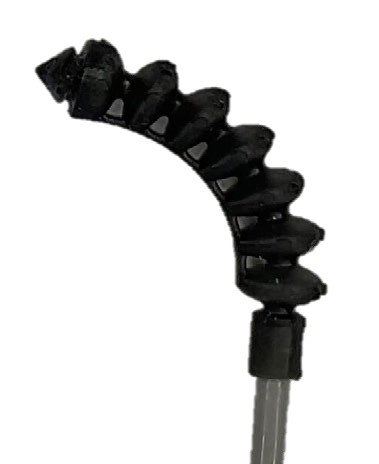
- own 3D-printed fluid-driven soft robot, 5 mm bellows (large-scale analogue of a microguidewire, not a clinical size)
- Degrees of freedom
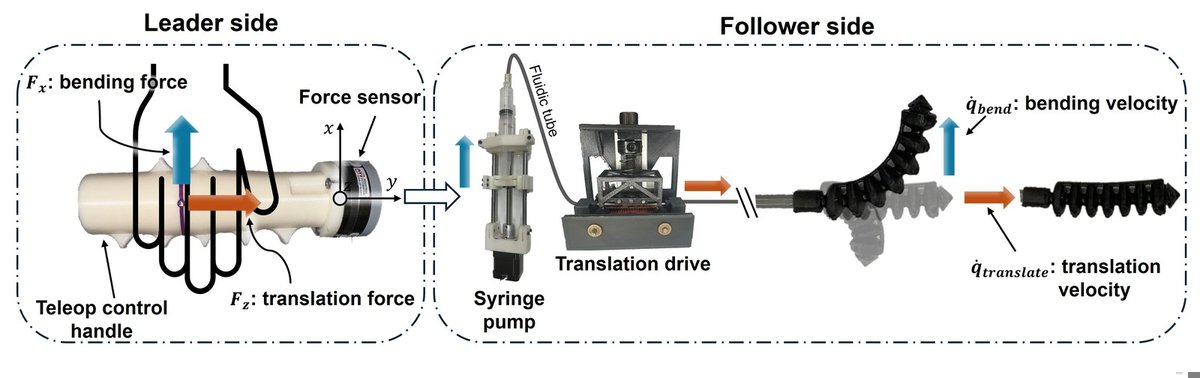
- 2 (bending velocity, translation velocity)
- Push
- Tip-actuated
- Twist
- None
- Tested up to
- Phantom
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Phantom
- What was tested
- 36 training mazes from 1584 possible, rearranged test set 3 mazes, novel test set 3 mazes; 647 demonstrations (218 normal, 429 recovery incl. DAgger)
- Key numbers
- 83 % success on unseen layouts, 75 % on unseen patient-derived geometry (abstract); ablations 22 % to 61 % success; segmentation tip error 0.6 mm median, 1.9 mm 95th, 8.0 mm max
Mechanism
- Push (translation)
- tendon/tip-actuation
- Twist (rotation)
- none
- Device range
- N.R.
- Target anatomy
- neuro, large-scale (enlarged) 2D-projected bifurcation mazes
Sensing and interface
- Force sensing
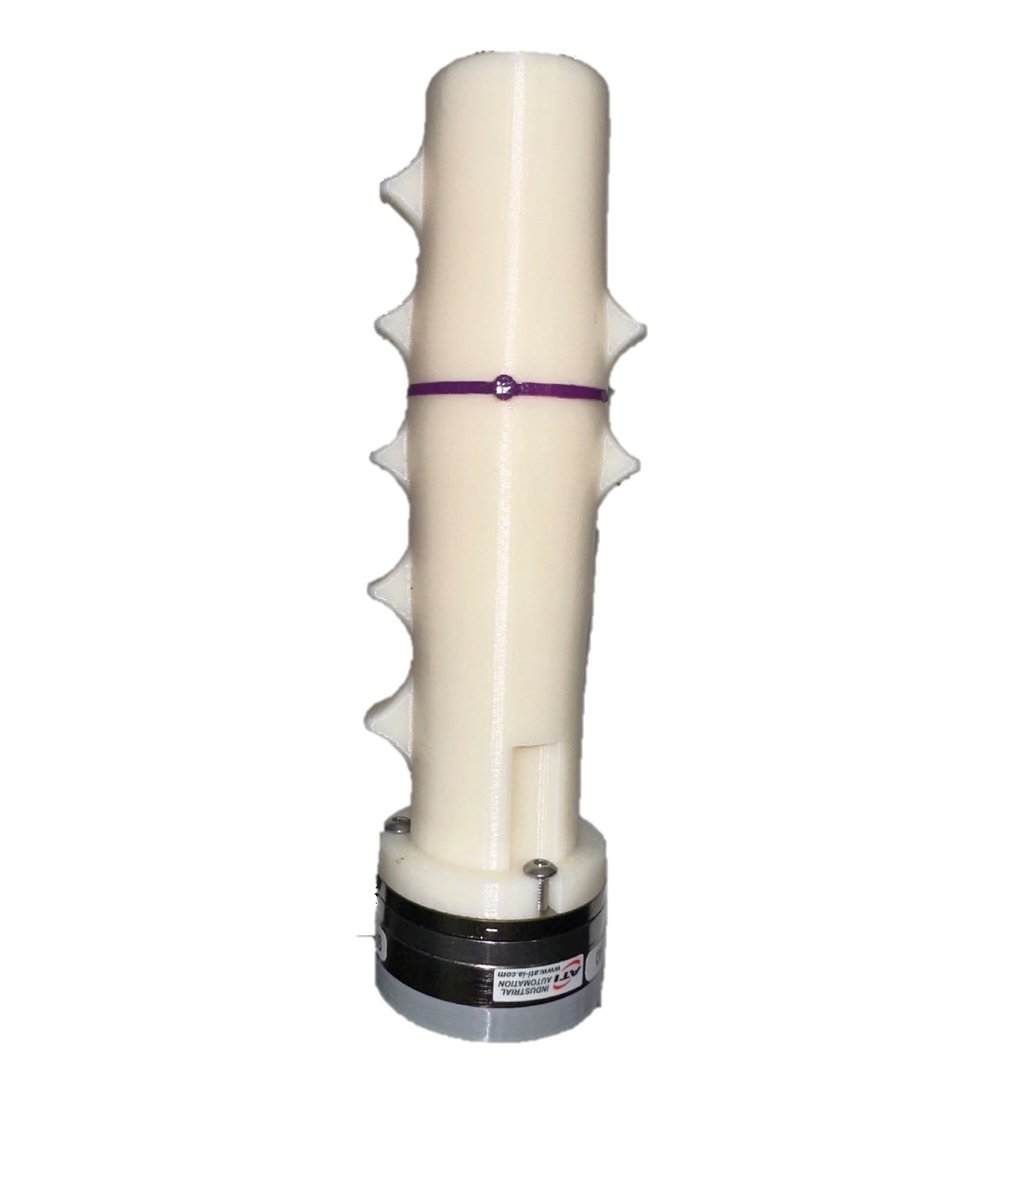
- force sensor in leader handle only (teleoperation); none on follower
- Leader and haptics
- no force feedback; operator pushes a force-sensing handle, forces map proportionally to bend and translate velocity
- Imaging
- overhead camera converted to simulated fluoroscopy; no real X-ray
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- no physics model; only a fluoroscopy rendering of camera frames (Sec. III-B)
- Sim-trained controller
- none found: the policy trains on real teleoperated demonstrations with simulated fluoroscopy images; the paper contrasts itself with digital-twin-trained policies
Versions
- Lineage
- arXiv 2510.09497 v2 (July 2026), submitted to IEEE
Sources
- Towards Autonomous Soft Robotic Endovascular Navigation via Imitation Learning · link [barnes2025_toward]
Notes
- Notes
- Hardware is a large-scale analogue; quote the 5 mm bellows size next to any claim about neurovascular use.
This record
- Read level
- full
- Picture
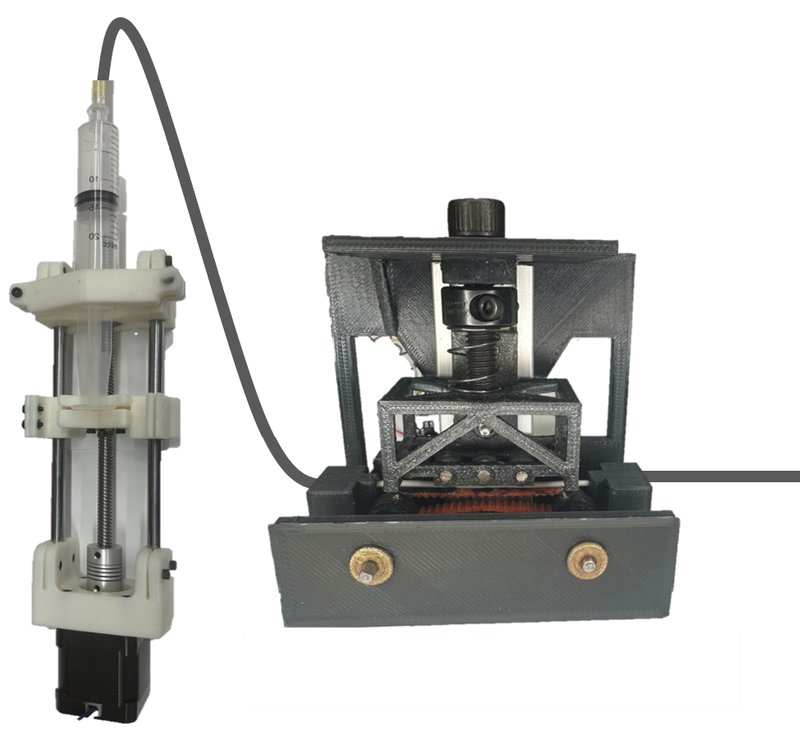
- barnes2025_toward project page softrobotnavigation.github.io/resources/imgs/hardware_setup.png (middle panel: translation drive with bellows wire) ↗ — licence: project page image (authors), licence not stated; grade B
- Picture changes
- crop; labels "Fluidic tube", "Translation drive" and an arrow erased (LaMa, mask of dark text pixels) then near-white residue set to white
- Found by
- actuated-tip: Search of actuated-tip and magnetic devices.
- Data
- JSON · YAML:
records/robots/bellows_barnes2025.yaml - Correction
- Suggest a correction [repository not created yet]