Actuated-tip devices · hydraulic_gopesh2021
Hydraulic catheter
Hydraulic steerable microcatheter tip (hyperelastic, saline-driven chambers)
 1 / 3
- Family
- Actuated-tip devices (actuated-device)
- Devices
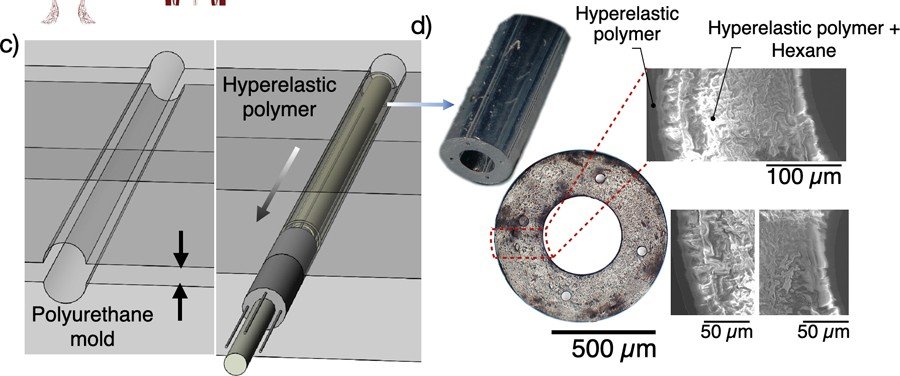
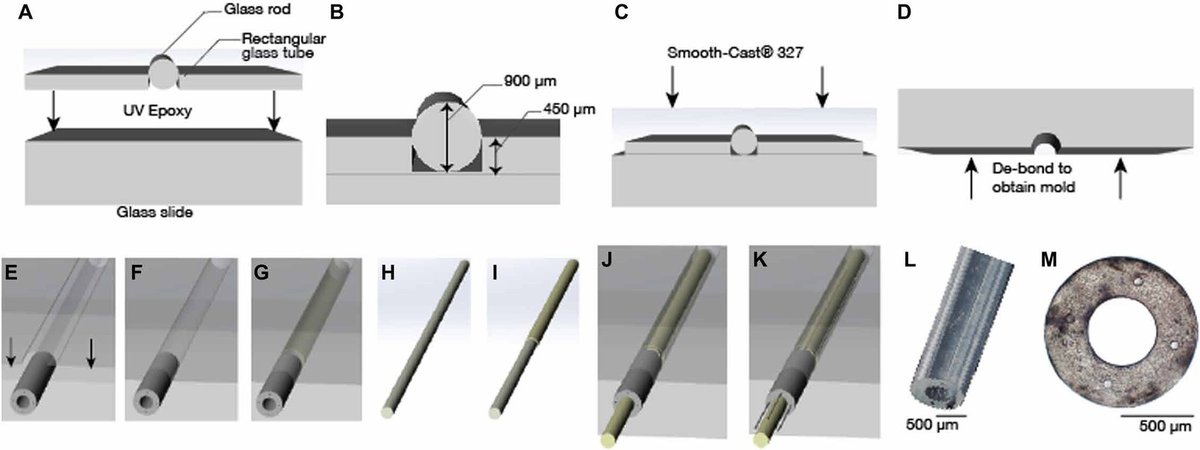
- own hydraulic microcatheter: 900 um outer diameter with four 50 um saline channels and a 400 um lumen, 15 mm steerable tip, 160 cm long Pebax shaft (gopesh2021_soft p. 3-5, 9); used through a 5 F guide with a 0.014-in Synchro2 micro-guidewire and AXIUM PRIME coils (p. 10)
- Degrees of freedom
- 3D tip orientation by pressurising one or more of four channels; no DOF count (gopesh2021_soft p. 1, 3)
- Push
- Tip-actuated
- Twist
- None
- Tested up to
- Animal
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Animal
- What was tested
- 2 Yucatan miniature pigs (47 kg), one per acute terminal session (gopesh2021_soft p. 11): navigation external carotid -> ascending pharyngeal -> parotid artery and coil deployment; patient-derived silicone phantoms (femoral to ICA; ICA to a PCOM aneurysm) with pulsatile flow, trial count N.R.
- Key numbers
- 180-degree bend at 350 kPa, rupture at 1200 kPa (safety factor about 4); response time < 1 s through 1.6 m of 50 um tubing; length-to-diameter ratio 10,000:1; no endothelial injury or perforation on angiography (gopesh2021_soft p. 3-10)
Mechanism
- Push (translation)
- tendon/tip-actuation (hydraulic: four saline channels bend the tip; insertion by hand)
- Twist (rotation)
- none reported: bending direction set by which channel is pressurised; shaft rotation N.R.
- Device range
- 160 cm; 180-degree bend (curvature 400 1/m) at 350 kPa, rupture at 1200 kPa (gopesh2021_soft p. 4)
- Target anatomy
- neuro: in vivo external carotid -> ascending pharyngeal -> parotid artery with coil deployment in the parotid artery (not intracranial); PCOM aneurysm coiling in a silicone phantom (gopesh2021_soft p. 6-9)
Sensing and interface
- Force sensing
- none
- Leader and haptics
- no: handheld controller connected by microtubing (p. 9); in vivo a 1-ml syringe per channel locked with a one-way stopcock (p. 6); bench: Elveflow OB-1 pressure controller (p. 9)
- Imaging
- fluoroscopic roadmap (Siemens Artis Zeego); gold radiopaque markers at three positions and barium-filled Pebax (gopesh2021_soft p. 5, 10)
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- ANSYS finite-element model of the tip (two-parameter Mooney-Rivlin) to choose channel radius and radial position; the channel count was fixed at four by the authors (gopesh2021_soft p. 4, 10)
- Sim-trained controller
- none found
Versions
- Lineage
- Sci. Robotics 2021 (gopesh2021_soft); patent application US20190209811A1 'Hydraulically driven surgical apparatus'; Mooney-Rivlin constants in Gopesh and Friend, Soft Robot. 2020 (ref. 91); medRxiv preprint 2021.06.28.21258767
Sources
- Soft robotic steerable microcatheter for the endovascular treatment of cerebral disorders · Science Robotics, 2021 · doi:10.1126/scirobotics.abf0601 [gopesh2021_soft]
Notes
- Notes
- Hand-controlled: no bedside drive in the paper. The earlier '400 kPa' (web) is not in the paper; 350 kPa bends the tip 180 degrees. | X2 2026-11-08: raised to full text.
This record
- Read level
- full — full (gopesh2021_soft)
- Picture
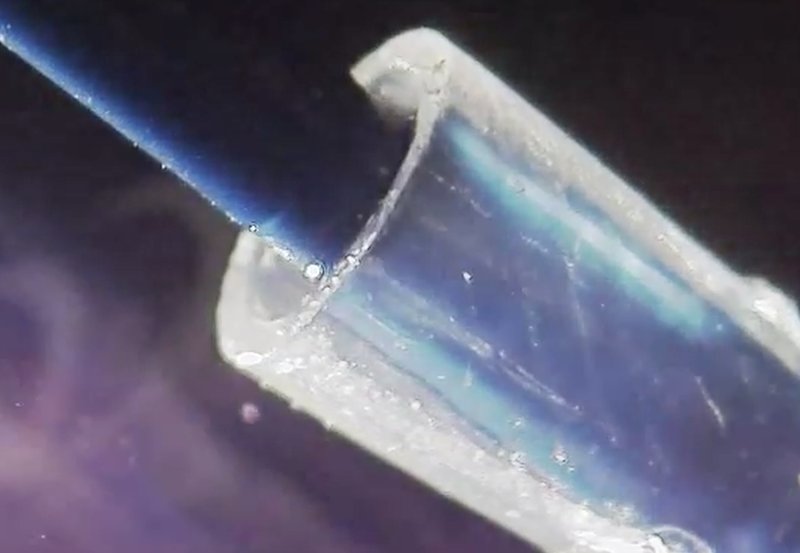
- https://today.ucsd.edu/news_uploads/steerable_catheter_1.png (UCSD news release, today.ucsd.edu/story/bioinspired-steerable-catheter; right part: hydraulic tip photo) ↗ — licence: press image (UC San Diego), terms not stated; grade B
- Picture changes
- crop removing the left fluoroscopy inset
- Found by
- actuated-tip: Search of actuated-tip and magnetic devices.
- Data
- JSON · YAML:
records/robots/hydraulic_gopesh2021.yaml - Correction
- Suggest a correction [repository not created yet]
