Actuated-tip devices · cathpilot_zhou2022
CathPilot
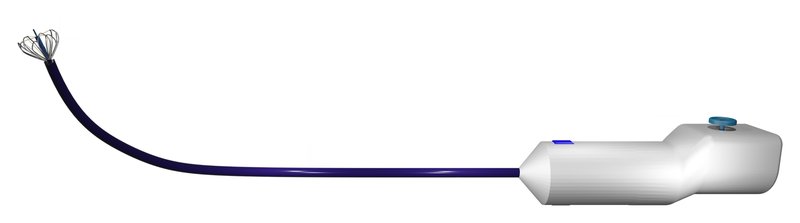
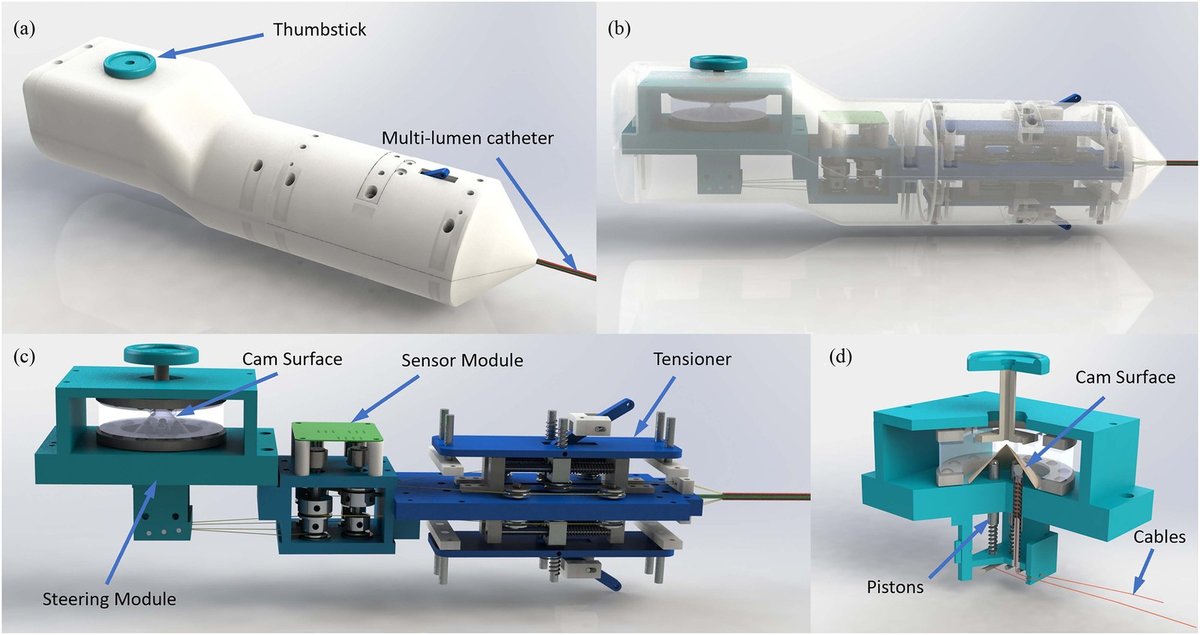
CathPilot (expandable cable-driven tip platform steered through a 3-D cam handle)
 1 / 8
- Family
- Actuated-tip devices (actuated-device)
- Devices
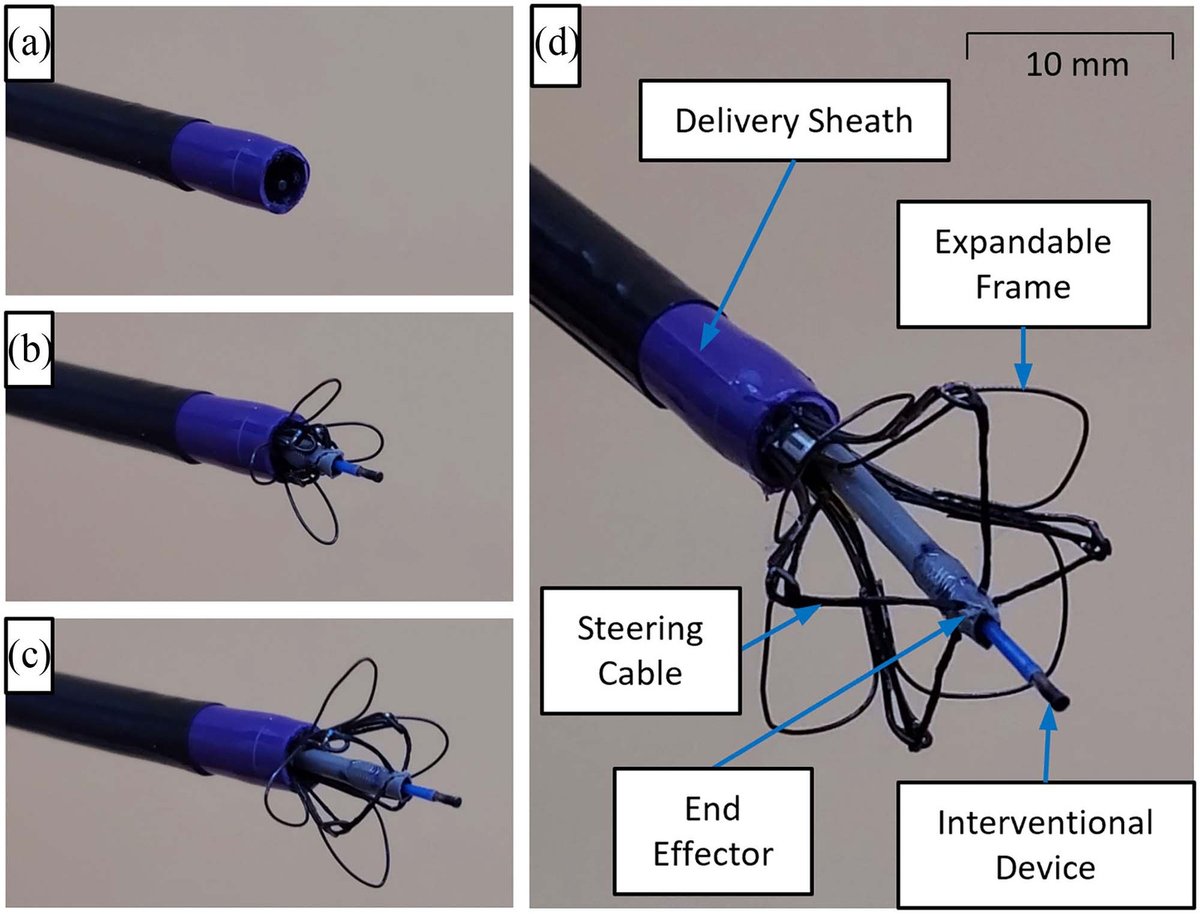
- CathPilot catheter positions a standard guidewire tip; frame deliverable through a 12 Fr sheath (OD 5.3 mm), expanding to 20 mm (TMECH 2022 Sec. III)
- Degrees of freedom
- 2 (planar positioning of the guidewire end-effector within the expanded frame)
- Push
- Tip-actuated
- Twist
- Not reported
- Tested up to
- Animal
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Animal
- What was tested
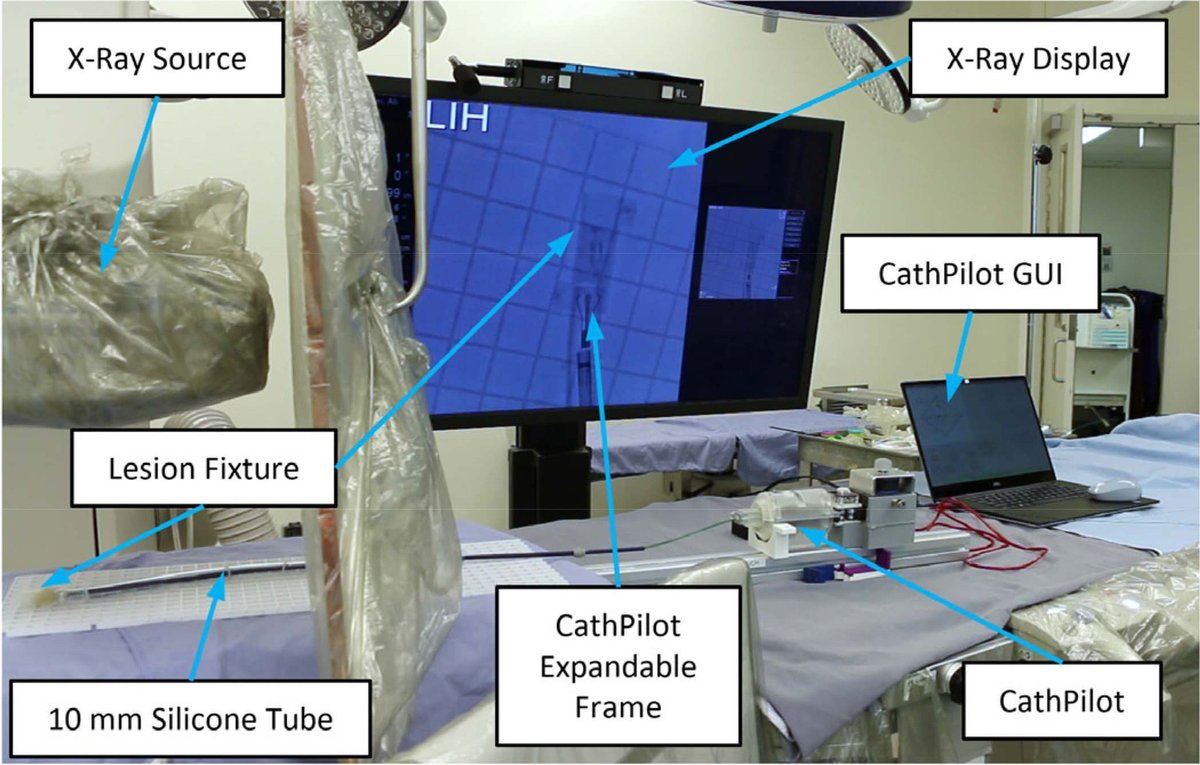
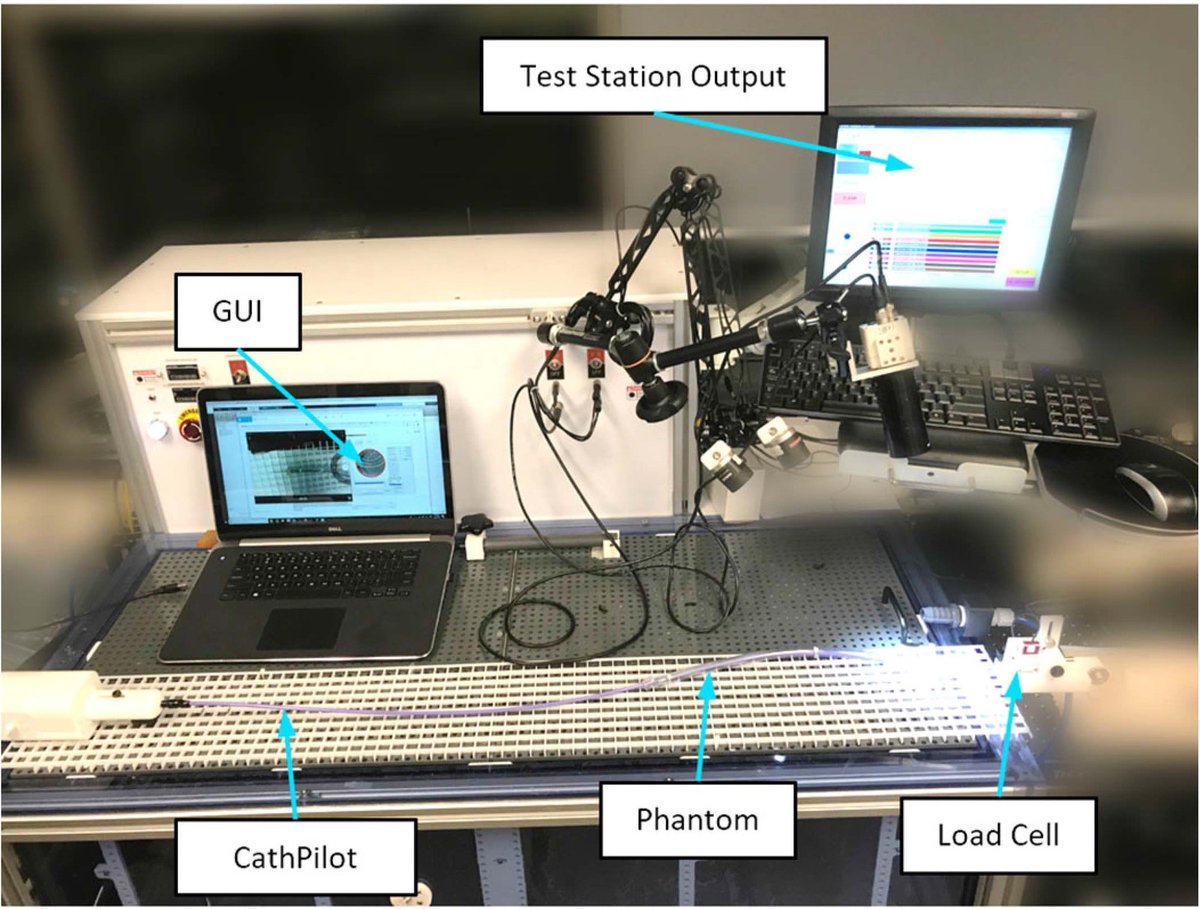
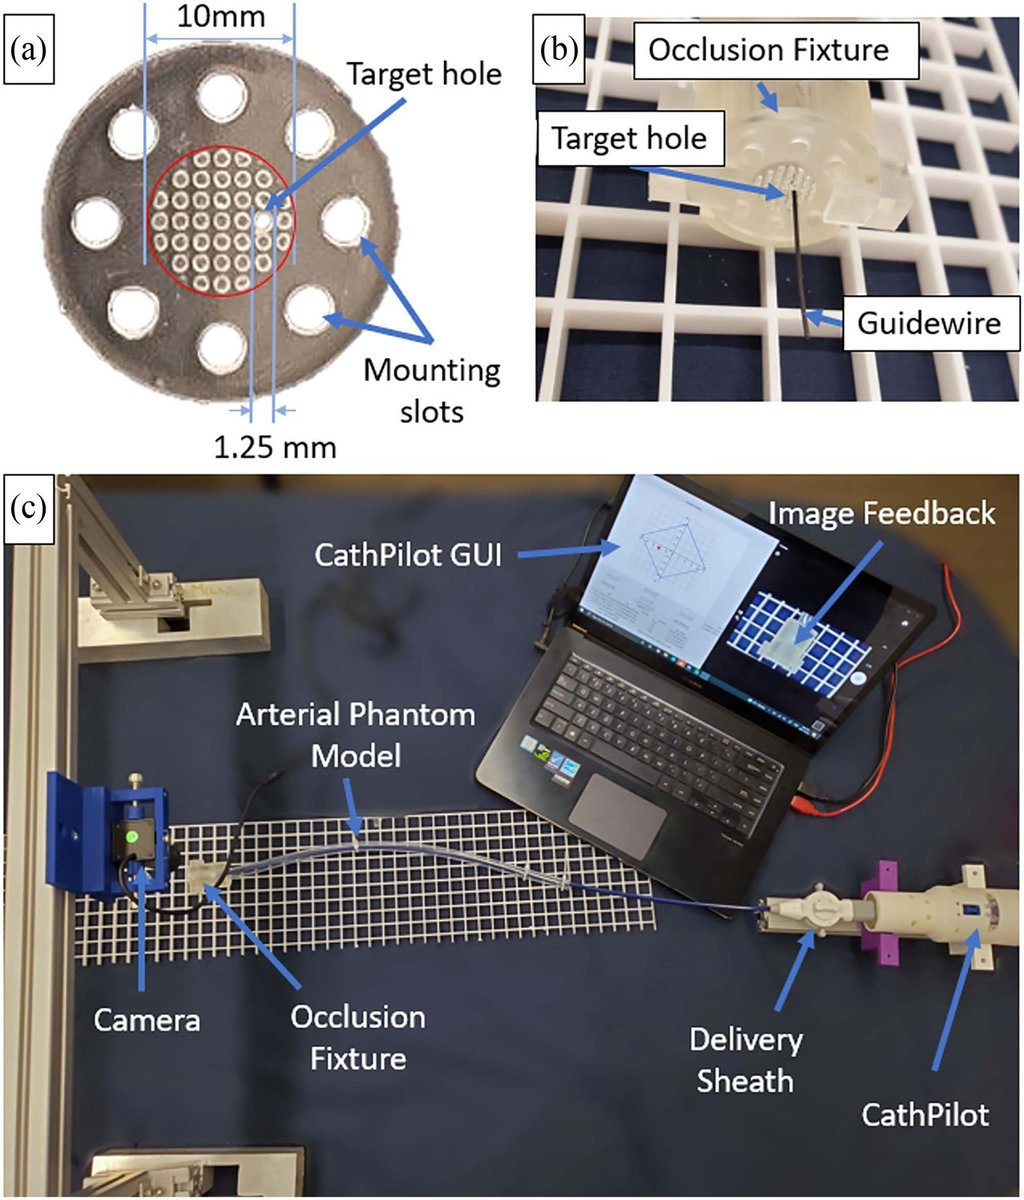
- TBME 2023: tortuous vessel phantom (target reach vs non-steerable and steerable catheters), ex-vivo human CTO samples (fresh and fixed), in-vivo porcine aorta in one male pig of 56.6 kg
- Key numbers
- target-reach success 31% non-steerable, 69% steerable, 100% CathPilot; CTO crossing 83% fresh and 100% fixed; up to four times higher force delivery and pushability (TBME 2023 abstract); submillimetre positioning (TMECH 2022 abstract)
Mechanism
- Push (translation)
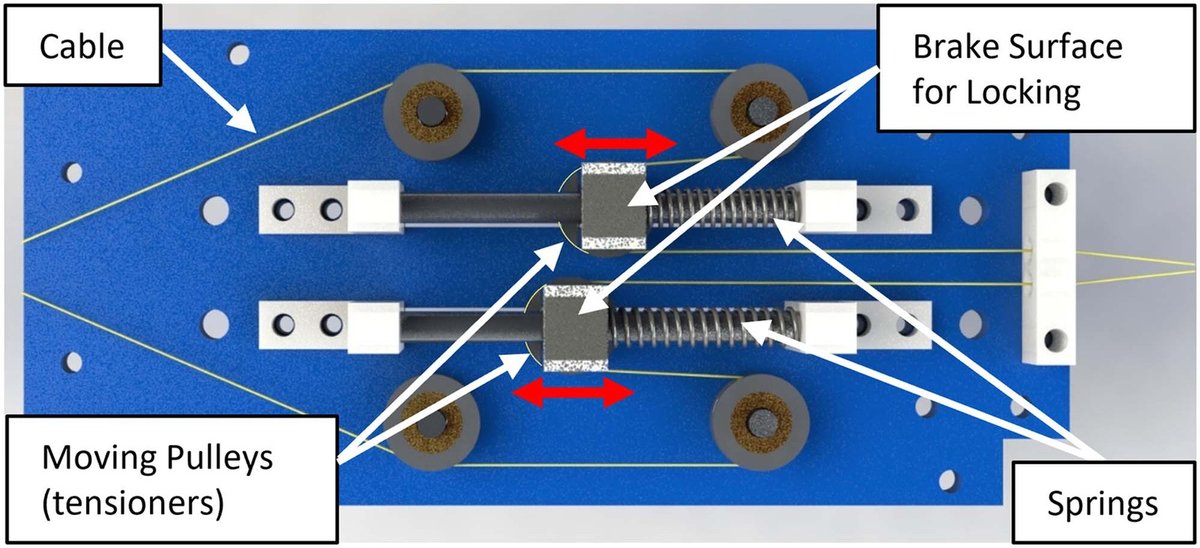
- tendon/tip-actuation (four PTFE cables, 0.012 in, from handle to an end-effector suspended in an expandable frame)
- Twist (rotation)
- N.R. (planar 2-DOF)
- Device range
- standard guidewire through the end-effector; several frame opening diameters tested
- Target anatomy
- peripheral arteries, chronic total occlusion (CTO) crossing
Sensing and interface
- Force sensing
- none (passive)
- Leader and haptics
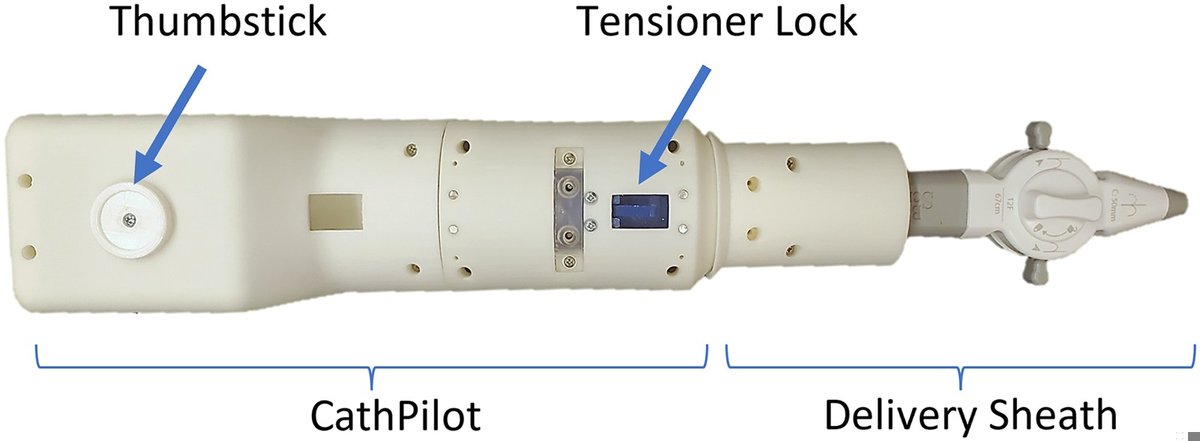
- handle with a 2-DOF 3-D cam surface sets all four cable lengths: fully manual mechanical teleoperation, no motors (TMECH 2022 Sec. III)
- Imaging
- X-ray fluoroscopy (N.R. further)
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found
- Sim-trained controller
- none found
Versions
- Lineage
- 2022 TMECH design and bench verification; 2023 TBME performance validation, ex-vivo CTO crossing and in-vivo porcine safety
Sources
- The CathPilot: A Novel Approach for Accurate Interventional Device Steering and Tracking · IEEE/ASME Transactions on Mechatronics, 2022 · doi:10.1109/tmech.2022.3188955 [zhou2022_cathpilot]
- The CathPilot: Performance Validation and Preclinical Safety and Feasibility Assessment · IEEE Transactions on Biomedical Engineering, 2023 · doi:10.1109/tbme.2023.3276199 [zhou2023_cathpilot]
Notes
- Notes
- Not motorised: the 'teleoperation' is a cable-and-cam transmission; included as a boundary case because the coordinator's snowball list names it. Tavallaei is the author of the Western University RCNS papers (western_thakur2009).
This record
- Read level
- full — full (TMECH 2022, TBME 2023)
- Picture
- zhou2022_cathpilot_TMECH Fig. 1 (CAD of manipulator unit, multilumen catheter, user-input handle) ↗ — licence: CC BY-NC-ND 4.0 (article licence line); zhou2023_cathpilot_TBME is CC BY 4.0; grade B
- Picture changes
- native extract (2000x595); text labels (OCR) and 3 blue arrows on white background erased (LaMa); faint grey residue in the erased label areas set to white; top 95 px cropped; 40 px white padding (render background); not upscaled
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/cathpilot_zhou2022.yaml - Correction
- Suggest a correction [repository not created yet]