Magnetic navigation · msmsr_li2024
CMNS
Multi-section magnetic soft robot with collaborative multirobot navigation system (CMNS)
 1 / 4
- Family
- Magnetic navigation (magnetic-navigation)
- Devices
- own telescoping two-tube soft robot: Tube-I OD 1.8 / ID 1.2 mm, Tube-II OD 3.5 / ID 2.5 mm
- Degrees of freedom
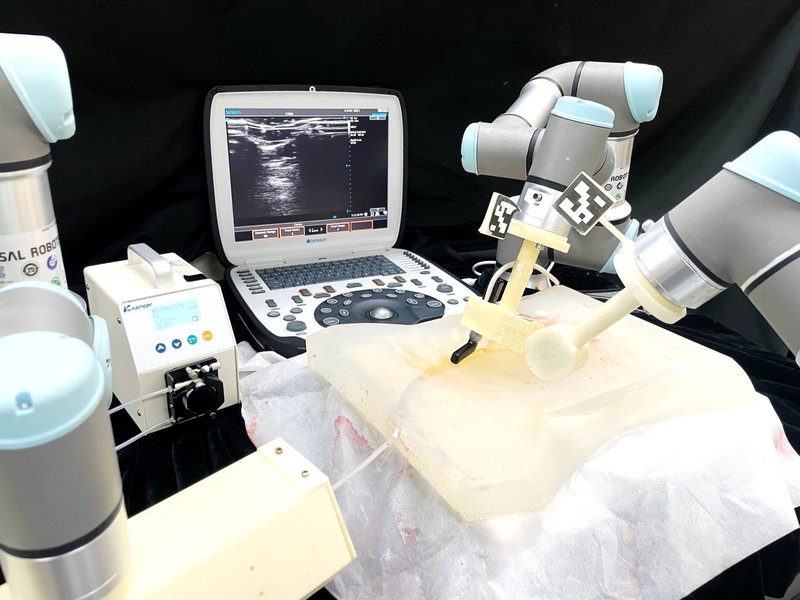
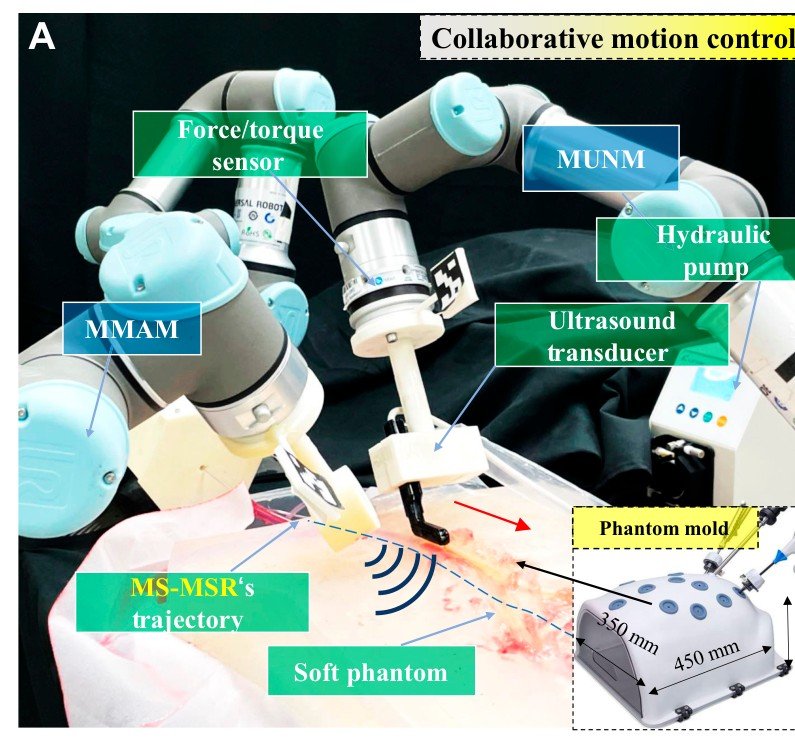
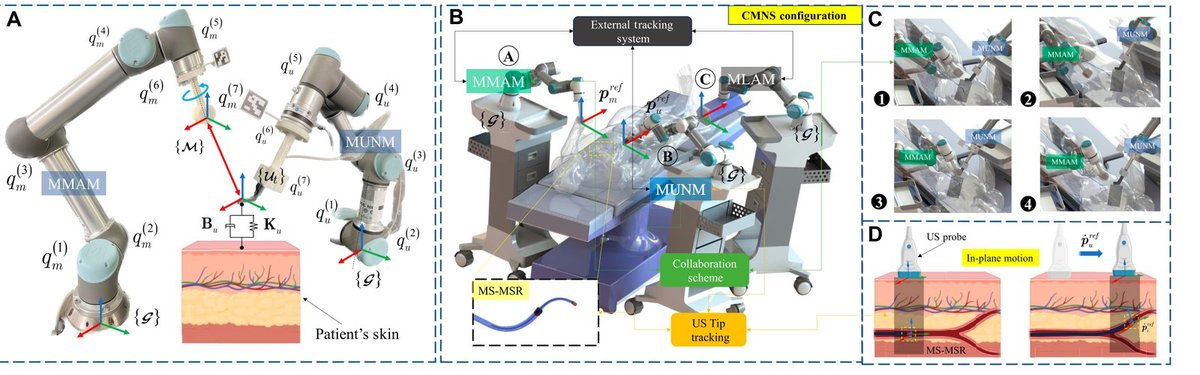
- UR3e carries a 30 mm NdFeB N42 permanent magnet; second manipulator carries ultrasound probe; seven-joint redundancy handled by QP controller
- Push
- Magnetic
- Twist
- Field direction
- Tested up to
- Phantom
- Sim-to-real
- Model-based only — Commands computed in a simulator or from a physical model ran on the robot; nothing was learned.
Testing
- Highest level
- Phantom
- What was tested
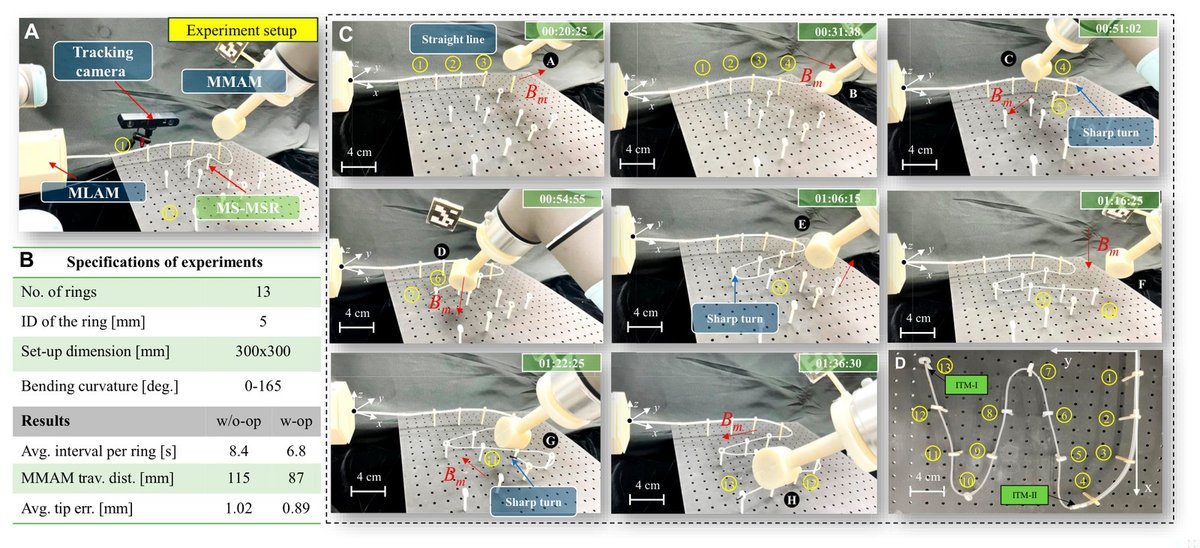
- multi-bifurcation intravascular phantom navigation; counts N.R.
- Key numbers
- shape error 3.1-3.9 deg, tip error about 1.0-1.4 mm (Table 2); bending range -125 to 125 deg tested
Mechanism
- Push (translation)
- magnetic (steering) + telescoping tube motion
- Twist (rotation)
- rotation of external magnet
- Device range
- N.R.
- Target anatomy
- intravascular phantoms with multiple bifurcations
Sensing and interface
- Force sensing
- none
- Leader and haptics
- no
- Imaging
- ultrasound tracking of the tip, closed loop
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- optimised Cosserat rod model with external heterogeneous field (full)
- Sim-trained controller
- model-based control using the Cosserat model on the hardware; no learned policy
Versions
- Lineage
- single (Cyborg Bionic Syst. 2024)
Sources
- Multi-Section Magnetic Soft Robot with Multirobot Navigation System for Vasculature Intervention · Cyborg and Bionic Systems, 2024 · doi:10.34133/cbsystems.0188 [li2024_multisection]
Notes
- Notes
- Picture can be cropped from the CC BY PDF once downloaded.
This record
- Read level
- full — full text from (no PDF)
- Picture
- li2024_multisection Fig. 1(B) embedded photo (CMNS with two UR arms, magnet, ultrasound probe and phantom; the figure's circles and labels are vector overlays and are not in the raster) ↗ — licence: CC BY 4.0 (Cyborg Bionic Syst.; PMC open-access metadata licence_code CC BY); grade A
- Picture changes
- native extract from the PMC open-data PDF; no crop, no edits; not upscaled
- Found by
- actuated-tip: Search of actuated-tip and magnetic devices.
- Data
- JSON · YAML:
records/robots/msmsr_li2024.yaml - Correction
- Suggest a correction [repository not created yet]