Actuated-tip devices · balloongw_barre2025
Balloon guidewire
Tendon-driven steerable guidewire with retractable distal balloon (+ handheld actuation)
 1 / 7
- Family
- Actuated-tip devices (actuated-device)
- Devices
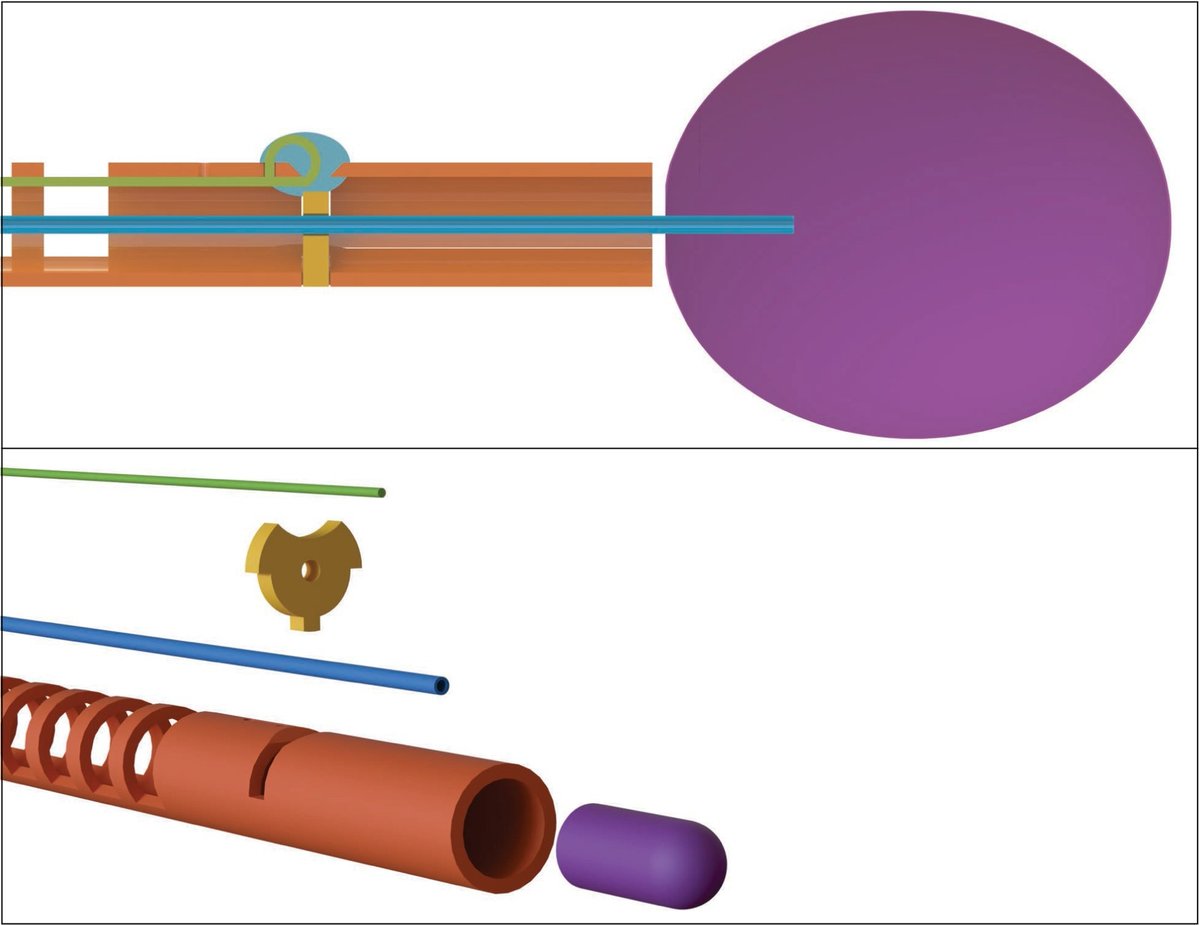
- own notched-nitinol tendon guidewire (0.48 mm OD nitinol tube, 20 mm UAN bending segment, 76 um nitinol tendon in 2026 paper); balloon wire uses 0.15 mm nitinol tendon
- Degrees of freedom
- bend, feed, roll (handheld); plus balloon inflation (2025)
- Push
- Tip-actuated
- Twist
- Rotating drive unit
- Tested up to
- Phantom
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Phantom
- What was tested
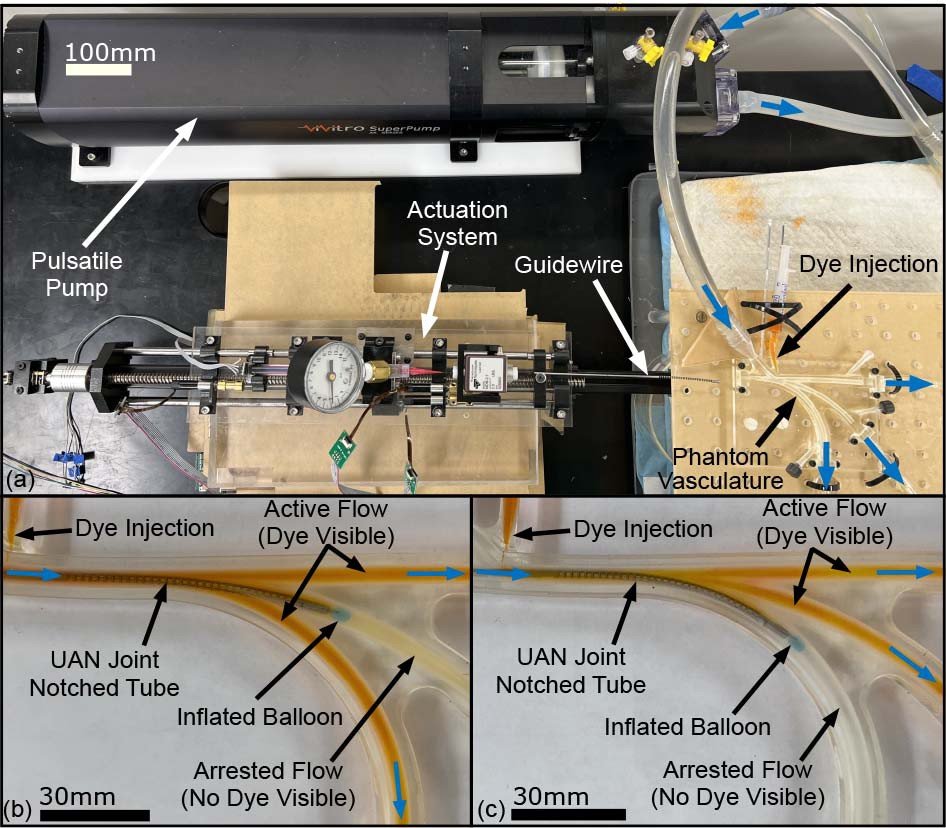
- 2025: phantom vessel under pulsatile flow, traversal, balloon inflation, flow arrest (one demonstration); 2026: one navigation of an abdominal aorta phantom, wire buckled between phantom entry and device (abstract-level counts N.R.)
- Key numbers
- balloon radii inflated 0.75-2.50 mm in 0.25 mm steps; 1.22 mm OD balloon on guidewire; Abaqus model of balloon inflation; pressure-channel test: position change 0.038 mm and curvature change 0.2 % (barre2025 Sec. V, context only partly read)
Mechanism
- Push (translation)
- tendon/tip-actuation
- Twist (rotation)
- motorised spool roll (handheld, 2026)
- Device range
- up to 1.5 m of wire spooled (2026)
- Target anatomy
- endovascular, phantom vessel 3 mm ID with three branches
Sensing and interface
- Force sensing
- N.R.
- Leader and haptics
- no (joystick, momentary switch)
- Imaging
- C-arm in phantom test; MR compatibility N.R.
- Sterility
- N.R.
Size
- Footprint (mm)
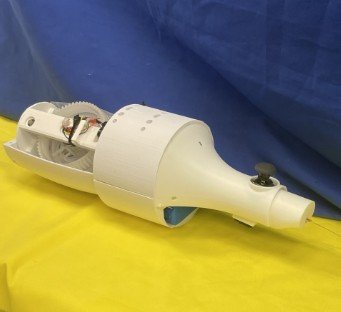
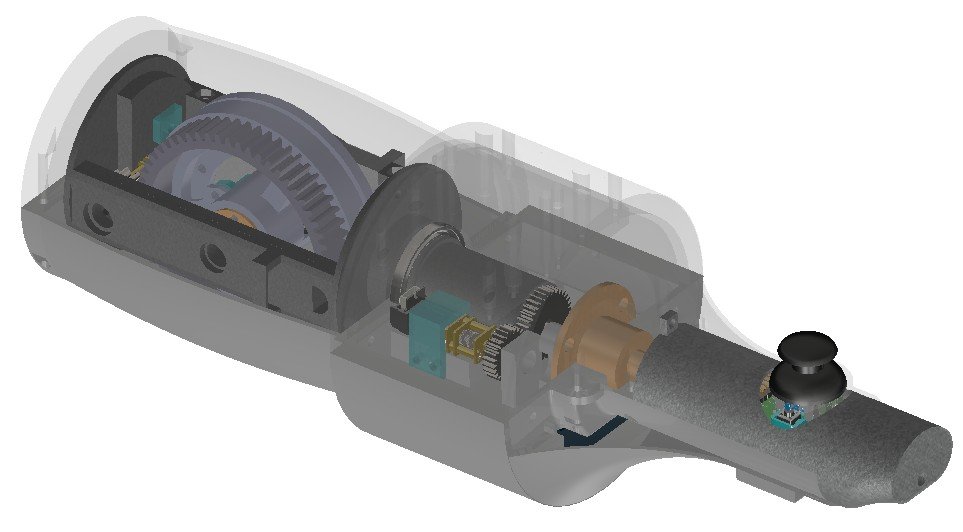
- handheld housing 341.7 x 110.4 (Fig. 1e)
- Mass (kg)
- 0.836 (handheld device)
Simulation
- Simulation model
- Abaqus FE model of balloon inflation plus analytical curvature model (barre2025 Sec. III-IV, partial read)
- Sim-trained controller
- none found
Versions
- Lineage
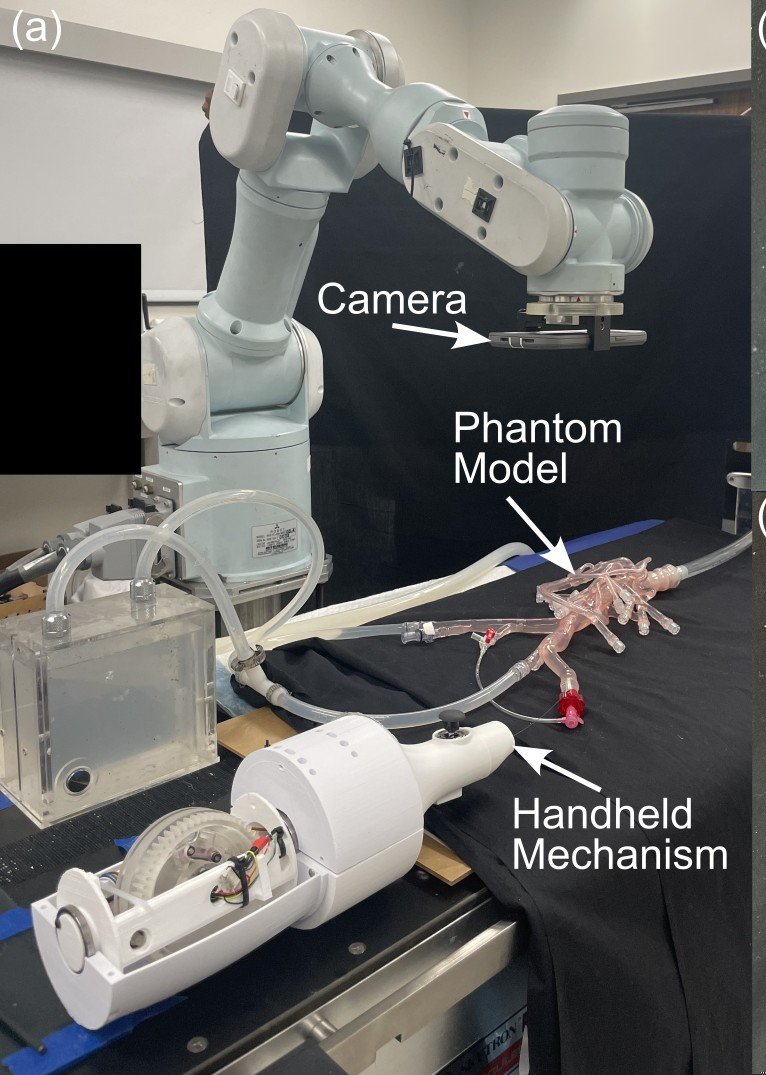
- 2025 balloon guidewire (barre2025_towards); 2026 handheld actuation mechanism for tendon-driven guidewire, 0.836 kg, up to 1.5 m of wire, joystick feed/roll/bend (chavenet2026_handheld)
Sources
- Towards a Tendon-Driven Robotically Steerable Guidewire With a Retractable Distal Balloon · IEEE Robotics and Automation Letters, 2025 · doi:10.1109/lra.2025.3590303 [barre2025_towards]
- Development of a Handheld Actuation Mechanism for a Tendon-driven Robotically Steered Guidewire · link [chavenet2026_handheld]
Notes
- Notes
- Entry kept separate from COAST because the tube is a single notched outer tube, not three coaxial tubes.
This record
- Read level
- full — full text downloaded, read selectively (key numbers by grep); arXiv chavenet2026 read intro+methods
- Picture
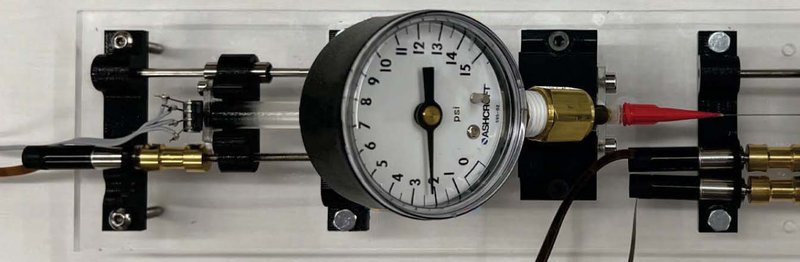
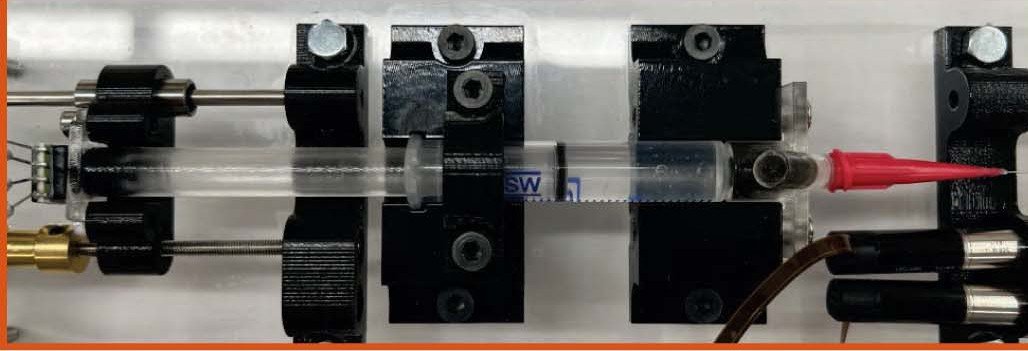
- barre2025_towards Fig. 3(a) (actuation system, top view) ↗ — licence: publisher copyright (IEEE); grade B
- Picture changes
- native extract (2036 px); cropped at x=1345 to keep the orange zoom-box leader (which crosses the load cell) out; orange box edges beside the gauge erased (LaMa, 2 passes)
- Found by
- actuated-tip: Search of actuated-tip and magnetic devices.
- Data
- JSON · YAML:
records/robots/balloongw_barre2025.yaml - Correction
- Suggest a correction [repository not created yet]