Academic bedside robots · kcl_cardioxplorer_xu2024
CardioXplorer
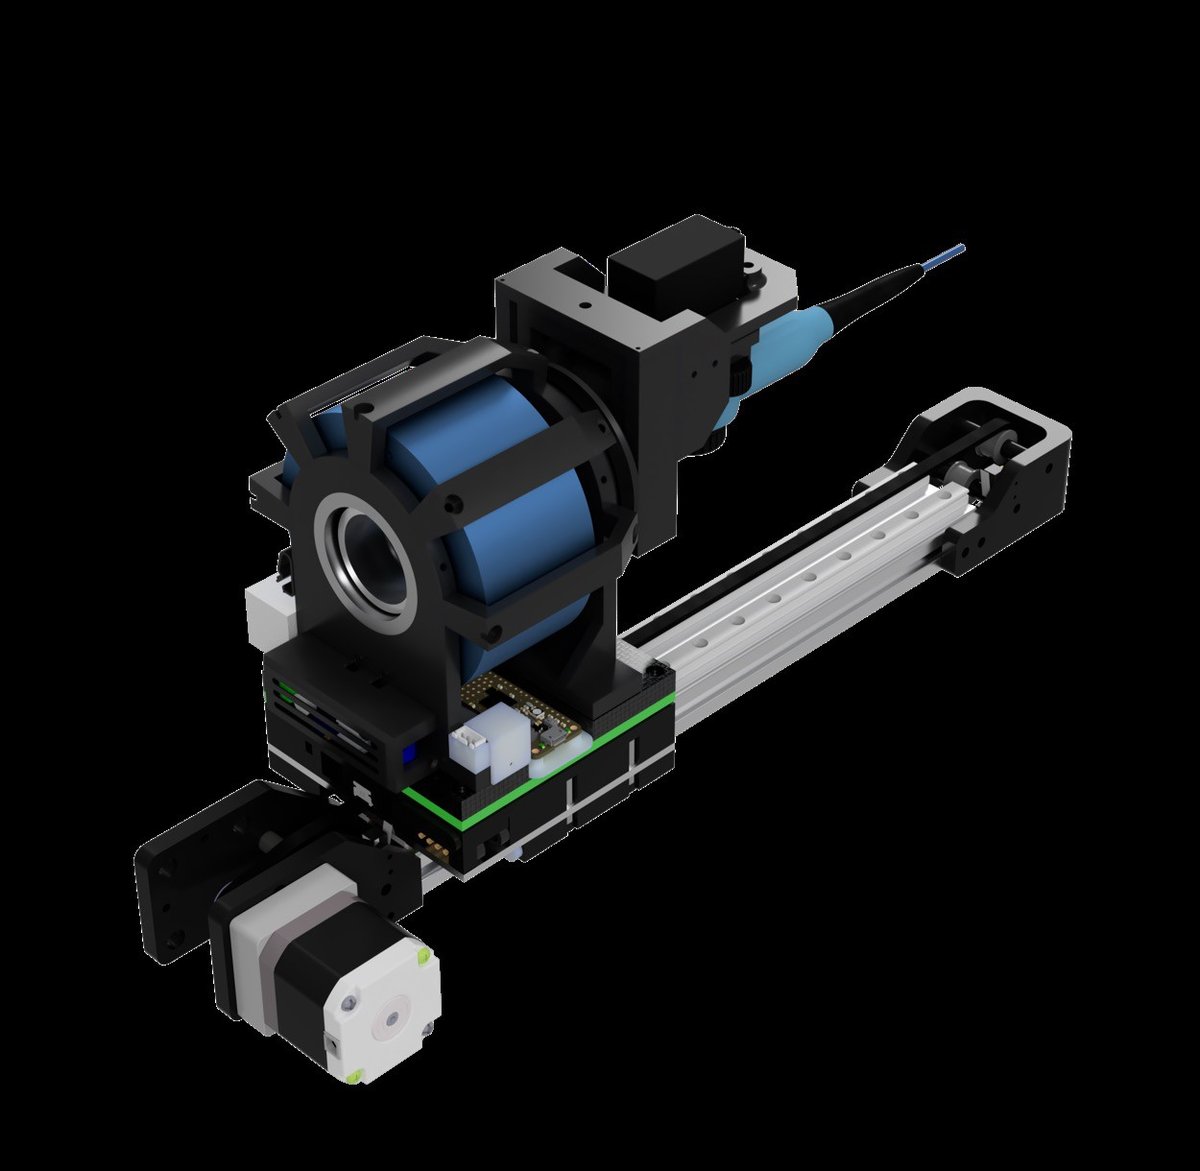
CardioXplorer open-source modular teleoperated robotic catheter-ablation system
 1 / 8
- Family
- Academic bedside robots (academic)
- Devices
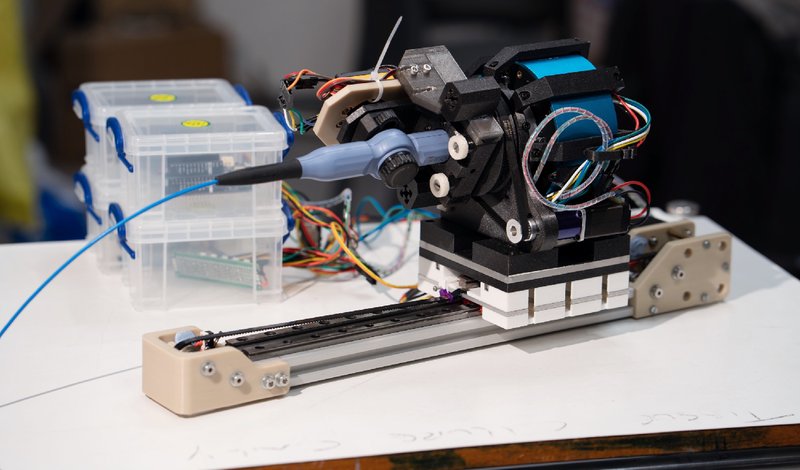
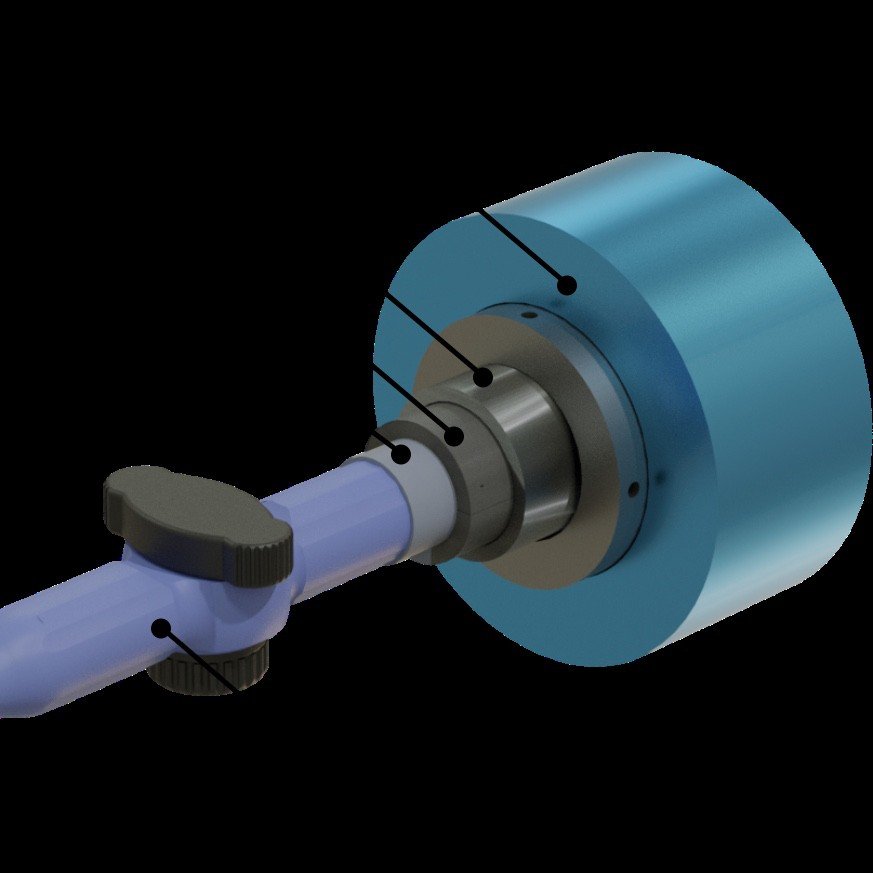
- commercial ablation catheters through a catheter-agnostic handle gripper: Thermocool SmartTouch SF and CS, Webster CS EZ Steer (Biosense Webster), Blazer II XP (Boston Scientific) (Sec. 2.1)
- Degrees of freedom
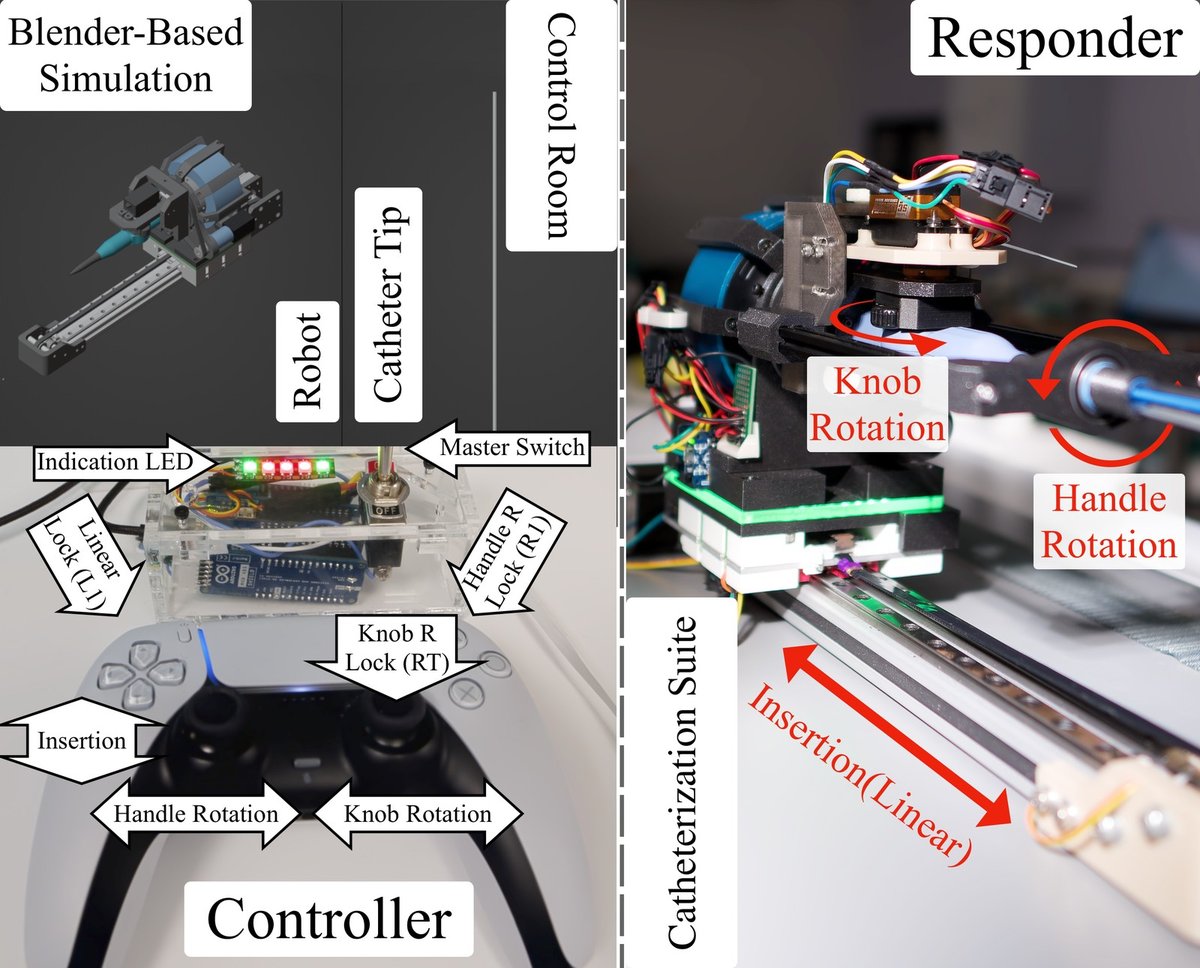
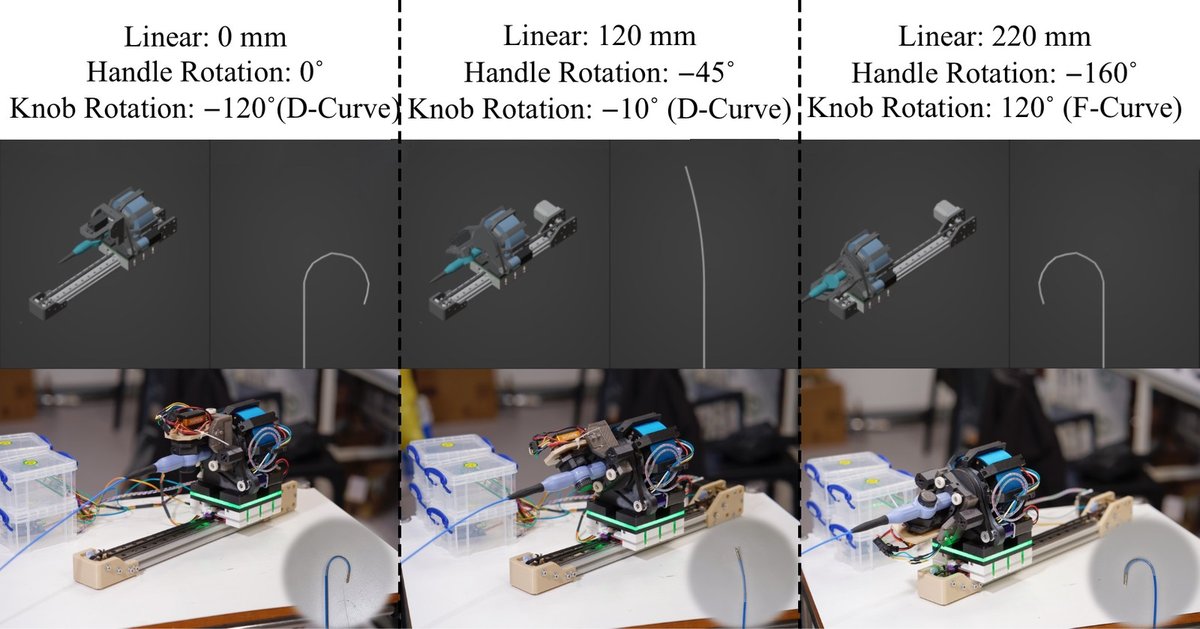
- 3 (insertion/retraction, handle rotation, knob)
- Push
- Linear stage
- Twist
- Handle or knob
- Tested up to
- Phantom
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Phantom
- What was tested
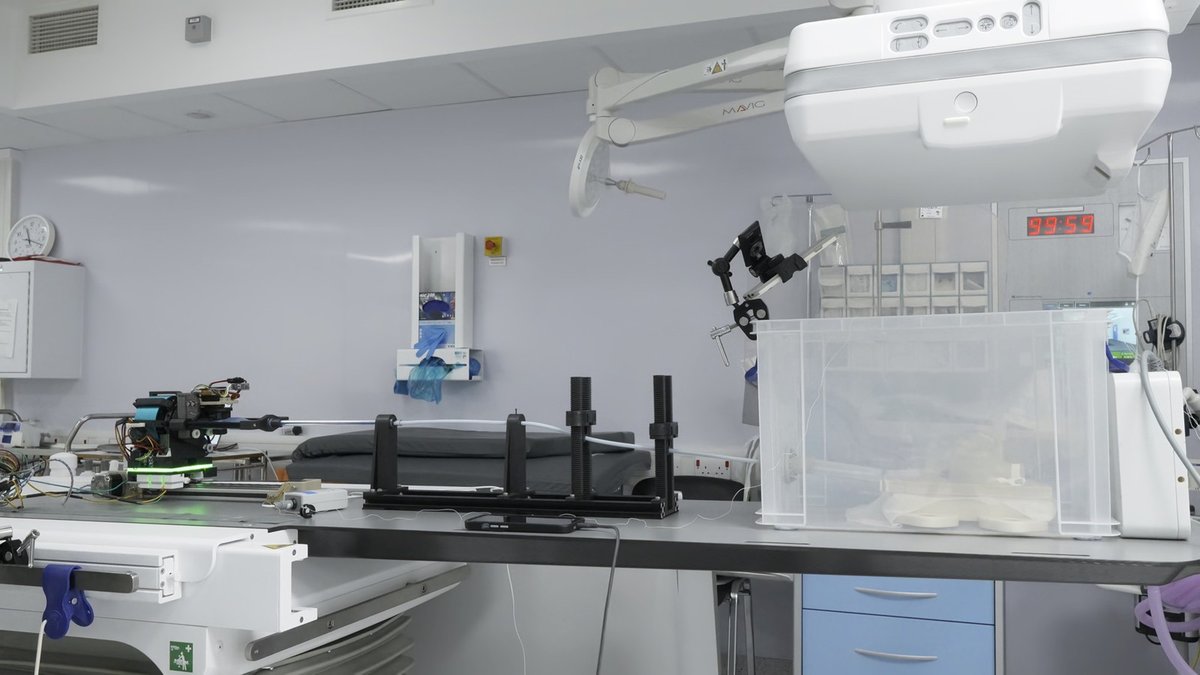
- benchtop targeting of left pulmonary veins in an AF-patient cardiac phantom; 3 cardiologists and 2 trainees, 5 trials, manual vs robot (Sec. 3)
- Key numbers
- task duration -1.59 s with the robot; robotic motion 35.2% smoother for experts than intermediates; jerk improvement vs manual 42.2% (experts) and 13.6% (intermediates); speeds up to +-25 mm/s, 0.5 deg rotation steps up to 9.375 rps; parts cost about USD 700 (abstract, Sec. 2)
Mechanism
- Push (translation)
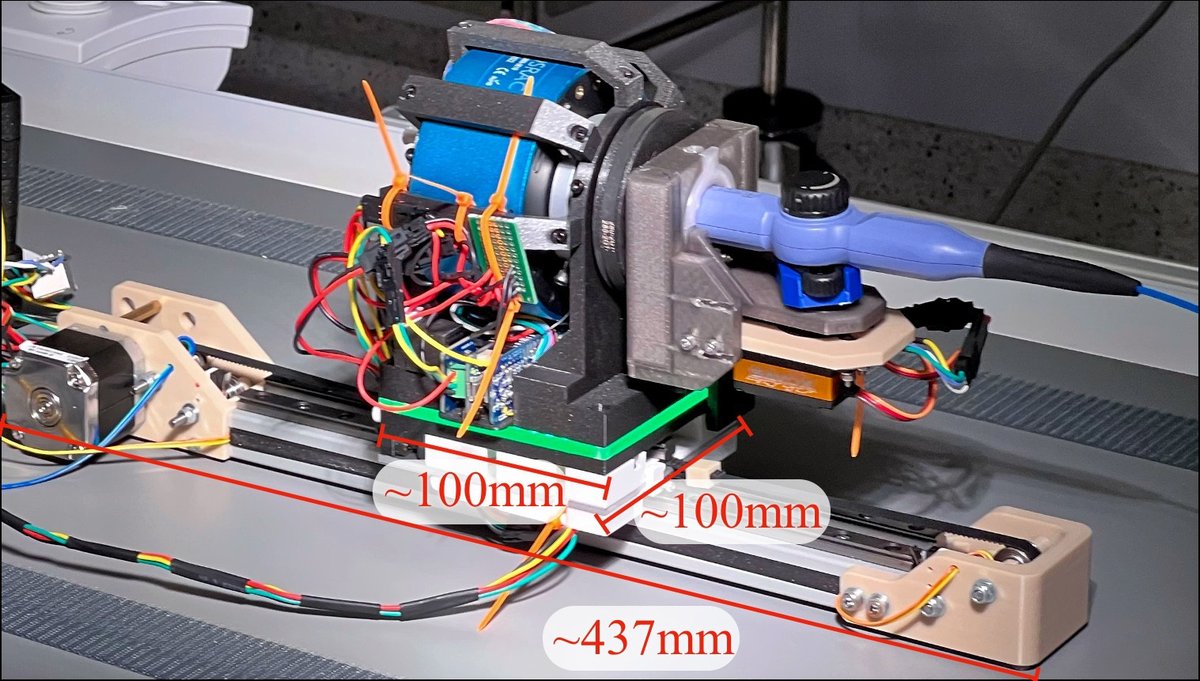
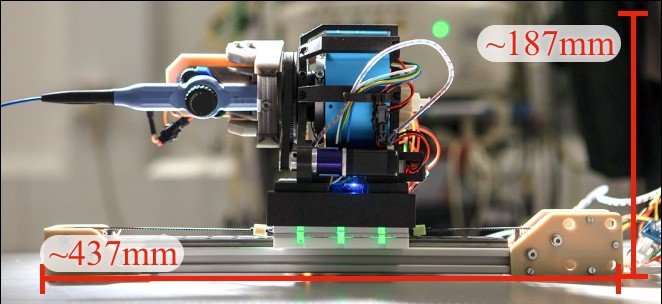
- linear-stage+clamp (linear module: NEMA-17 stepper with GT2 belt drive carries the handle, 220 mm insertion depth)
- Twist (rotation)
- NEMA-8 stepper (19:1) rotates the handle without limit through a slip ring; servo (12 kg.cm holding torque) turns the knob +-60 deg
- Device range
- four commercial ablation catheter models (open-source CAD handles)
- Target anatomy
- atrial-fibrillation catheter ablation (pulmonary vein isolation)
Sensing and interface
- Force sensing
- none on the robot (knob torque of about 6 kg.cm measured during design)
- Leader and haptics
- joystick, no haptics
- Imaging
- NDI Aurora EM tracking in tests; phantom imaged on a Siemens Artis Q biplane
- Sterility
- detachable disposable single-use catheter; N.R. further
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found
- Sim-trained controller
- none found
Versions
- Lineage
- 2024 MDPI Robotics (only); sibling KCL robot for transseptal puncture (kcl_tsp_zeidan2023)
Sources
- CardioXplorer: An Open-Source Modular Teleoperative Robotic Catheter Ablation System · Robotics, 2024 · doi:10.3390/robotics13050080 [xu2024_cardioxplorer]
Notes
- Notes
- Second KCL robot family next to the A3 neuro manipulator (kclneuro_sadati2025); open-source designs. CC BY 4.0.
This record
- Read level
- full
- Picture
- xu2024_cardioxplorer_Robotics Fig. 4 left photo (SmartTouch SF catheter in the catheter-agnostic gripper); full-size image https://mdpi-res.com/robotics/robotics-13-00080/article_deploy/html/images/robotics-13-00080-g004.png ↗ — licence: CC BY 4.0; grade A
- Picture changes
- cropped from the 3155x1185 MDPI full-size figure (caption text below the photo excluded); no other edits; not upscaled
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/kcl_cardioxplorer_xu2024.yaml - Correction
- Suggest a correction [repository not created yet]