Commercial and clinical-stage systems · liberty_microbot2024
LIBERTY
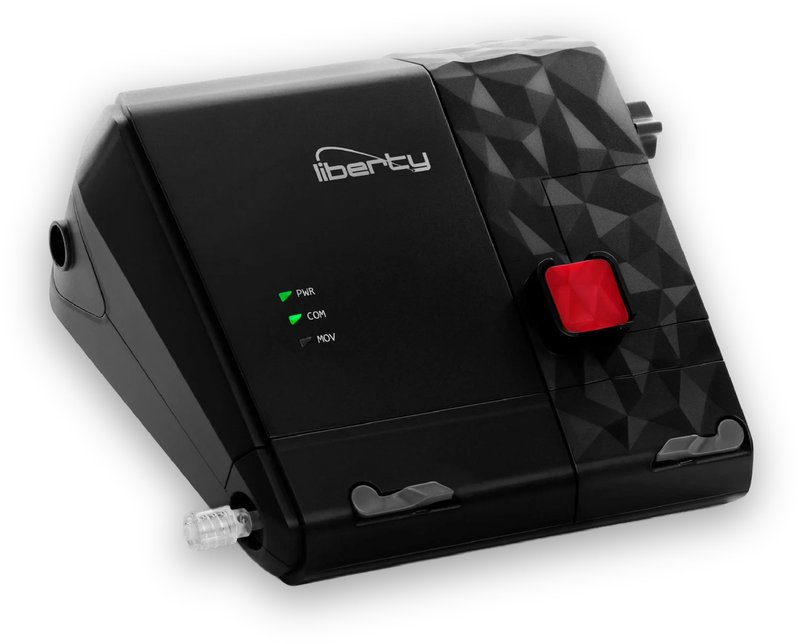
LIBERTY Endovascular Robotic System
 1 / 8
- Family
- Commercial and clinical-stage systems (commercial)
- Devices
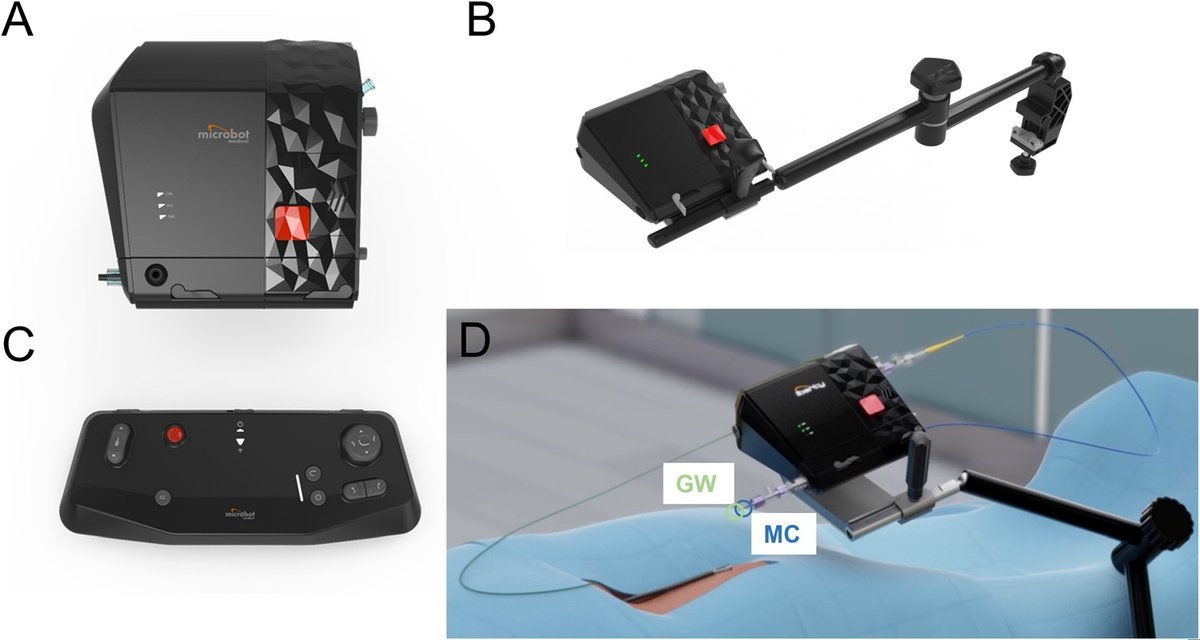
- guide catheter, microcatheter, guidewire (telescopic); standard 0.014-0.018-in guidewires with compatible microcatheters (2-3 F) and guide catheters (4-6 F) (cornelis2026_in p. 3); in the 20-patient study the robot advanced microwire and microcatheter (0.014-0.016-in wires, 2.7 F Progreat or Truselect), guide catheters (typically 5 F) placed by hand (cornelis2026_in p. 3-5, Fig. 2b); tested 0.016-in microwire, 2.4 F microcatheter, 5 F guide (vidal2024_performance)
- Degrees of freedom
- 3 (gao2026_legobot via S8); advance, retract, rotate (vidal2024_performance)
- Push
- Friction rollers
- Twist
- Not reported
- Tested up to
- Human
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Human
- What was tested
- 20 pts treated (21 screened), 3 centres (MSKCC, Miami Cardiac & Vascular Institute, Brigham and Women's), 3 interventional radiologists, 3-day follow-up; Y-90 mapping 10, UFE 3, haemangioma 2, TACE 2, sacral, intercostal and pulmonary 1 each; robot removed before embolisation (cornelis2026_in); 2 pigs x 6 operators (vidal2024_performance); simulator benchmark
- Key numbers
- navigation to target without conversion 20/20 (95% CI 83.2-100%); robotic navigation 6.3+-7.6 min (median 3, range 1-32) of 120.1+-34.5 min procedure; fluoroscopy median 7.9 min; operator dose median 1.4 uSv (abstract; 1.46 uSv in Table 2) (cornelis2026_in). Wiring on PCI simulator 27.1 s vs manual 36.9 s vs GRX 62.3 s (winsor2024_performance). FDA 510(k) K243789 decided 2025-09-04.
Mechanism
- Push (translation)
- friction-roller (inferred; mechanism not described in vidal2024_performance)
- Twist (rotation)
- N.R.
- Device range
- N.R.
- Target anatomy
- peripheral arterial/visceral (PAE, UFE, GAE, Y90, peripheral); neurovascular only a stated future target
Sensing and interface
- Force sensing
- none
- Leader and haptics
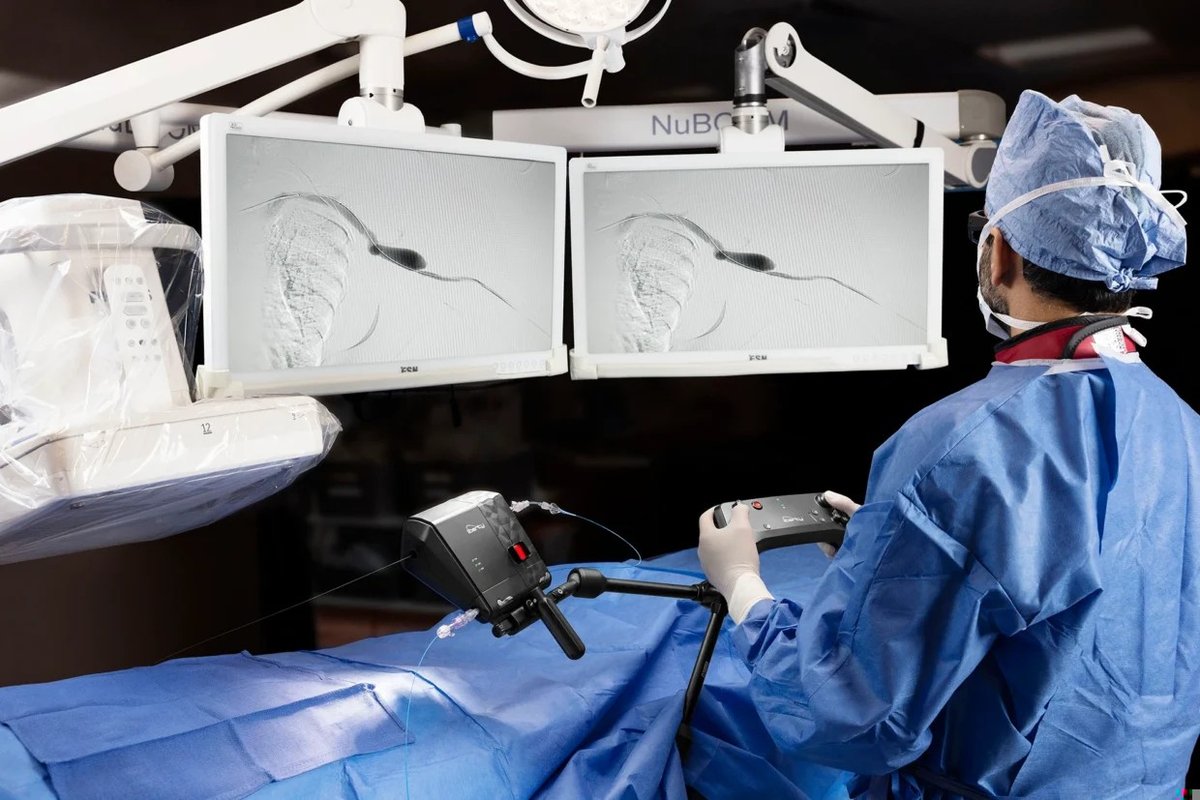
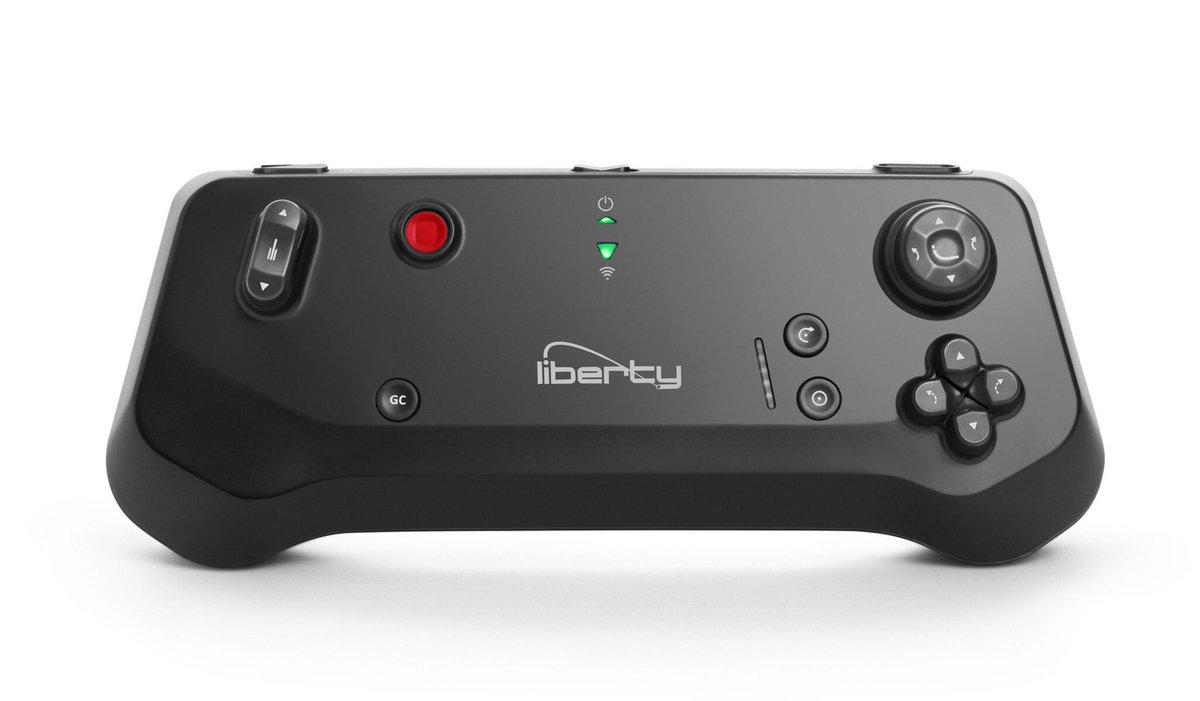
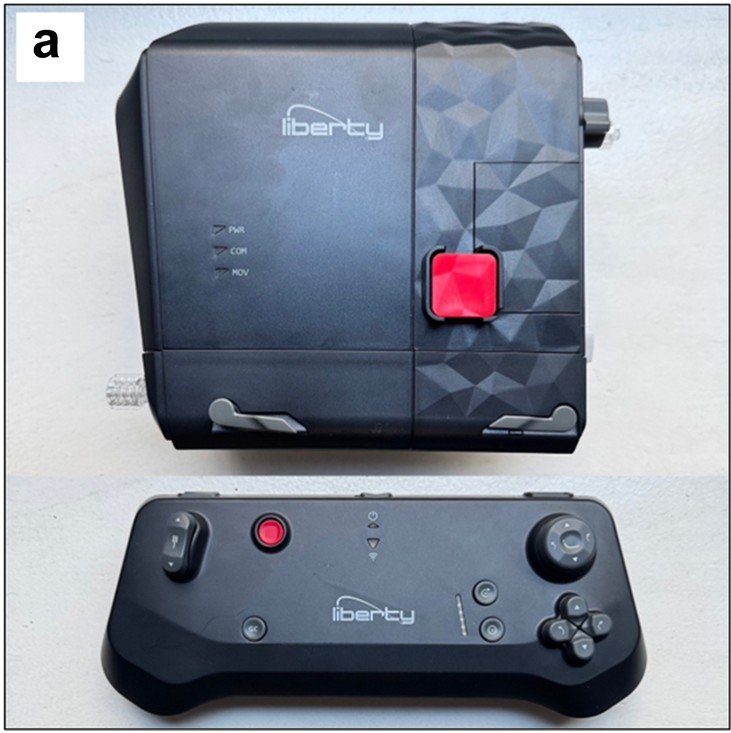
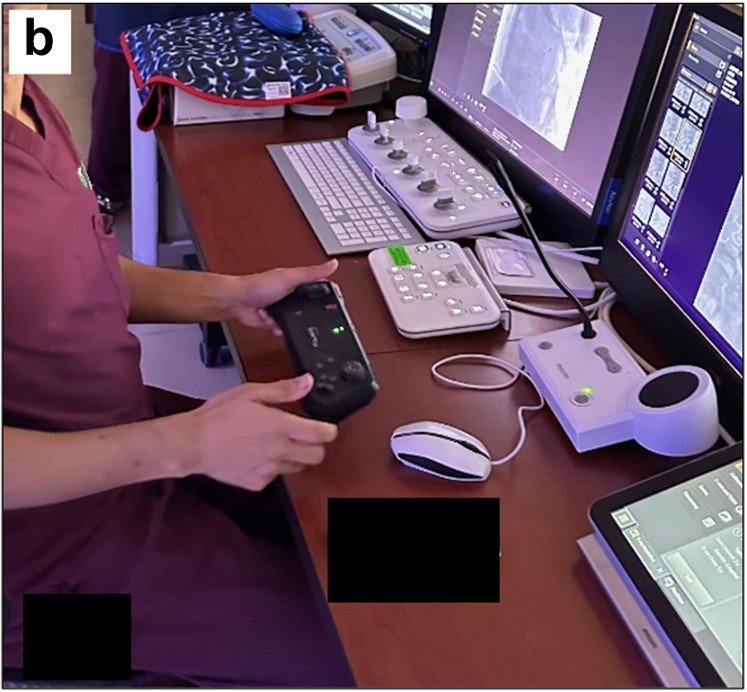
- no: remote controller operable up to 30 ft (9.1 m) away, e.g. from the control room (cornelis2026_in p. 3, Fig. 6b); wireless handheld per vidal2024_performance
- Imaging
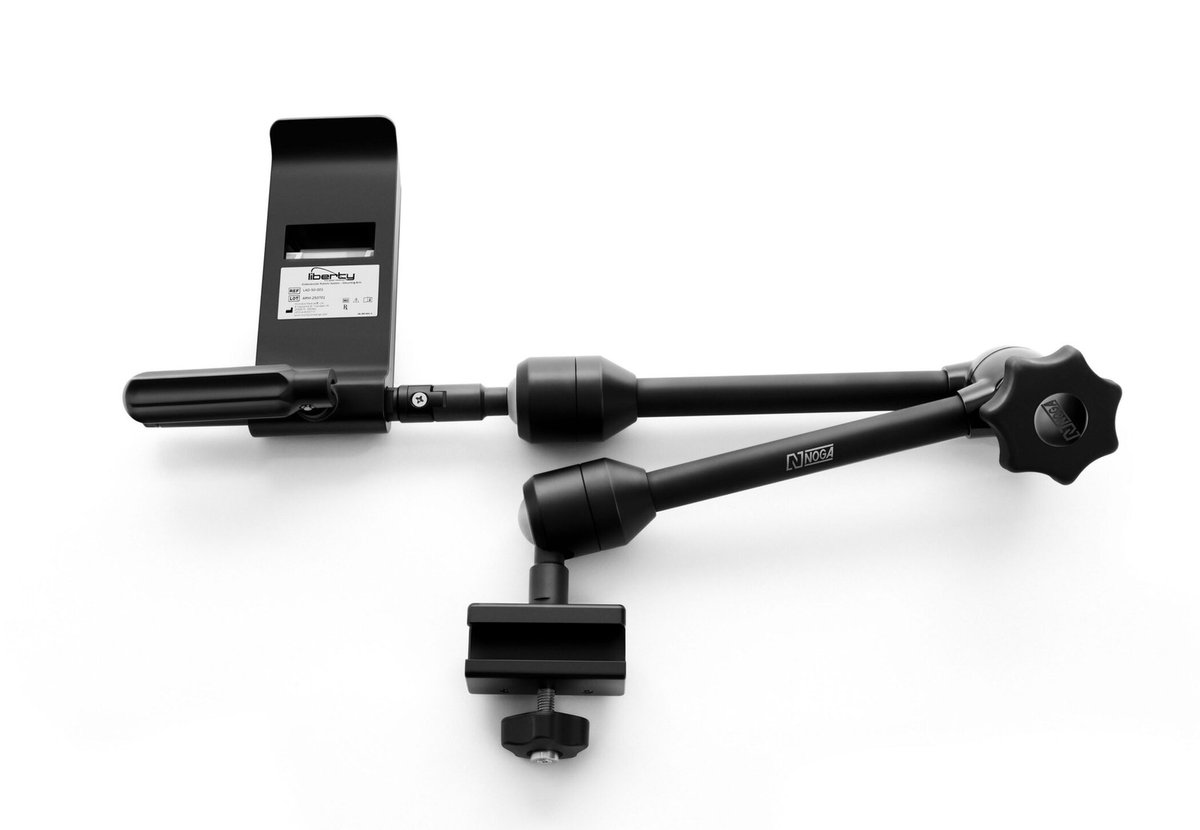
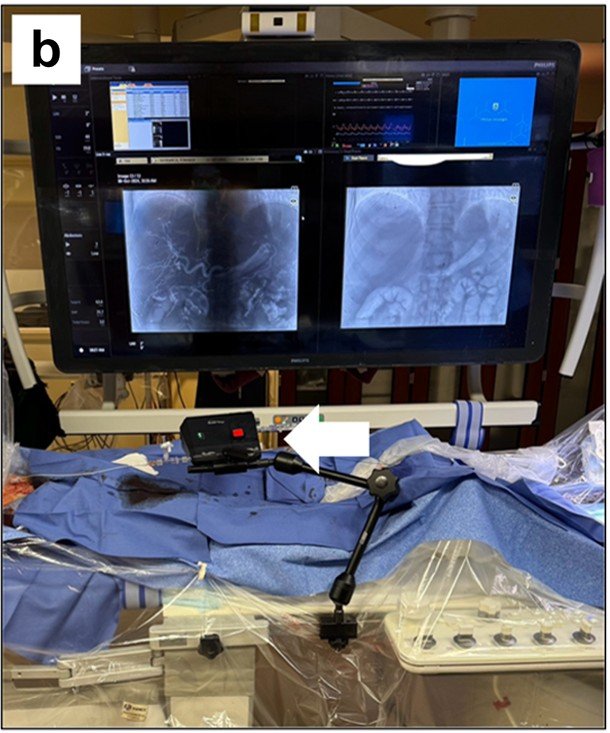
- fluoroscopy with registered DSA overlay (cornelis2026_in Fig. 2a); drive on a mounting arm fixed to the angiography table (Fig. 1b)
- Sterility
- fully disposable, single-use system: robotic drive, mounting arm and remote controller (cornelis2026_in p. 2, Fig. 1)
Size
- Footprint (mm)
- palm-size drive (vidal2024_performance); 'handheld' system fixed to the angiography table by a mounting arm (cornelis2026_in p. 2-3, Fig. 1b)
- Mass (kg)
- <1 each for drive and wireless hand controller (vidal2024_performance)
Simulation
- Simulation model
- none found
- Sim-trained controller
- none found
Versions
- Lineage
- single version; limited market release 2025-2026, full launch from SIR April 2026
Sources
- 510(k) Premarket Notification K243789: LIBERTY Endovascular Robotic System (Microbot Medical, Ltd.) · link [fda2025_k243789]
- In Vivo Evaluation of a Disposable Endovascular Robotic System for Arterial Peripheral Vascular Interventions: A Multicenter Feasibility Study · Journal of Vascular and Interventional Radiology, 2026 · doi:10.1016/j.jvir.2026.108591 [cornelis2026_in]
- Performance Evaluation of a Miniature and Disposable Endovascular Robotic Device · CardioVascular and Interventional Radiology, 2024 · doi:10.1007/s00270-024-03686-0 [vidal2024_performance]
- Safety and feasibility study of a novel robotic system in an in vivo porcine vascular model · CVIR Endovascular, 2024 · doi:10.1186/s42155-024-00425-x [moschovakizeiger2024_safety]
- Performance of a Novel Miniaturized Robotic System in Percutaneous Coronary Intervention: A Preclinical Study · Journal of the Society for Cardiovascular Angiography & Interventions, 2024 · doi:10.1016/j.jscai.2024.102148 [winsor2024_performance]
Notes
- Notes
- Remote ability: Corewell Health teleintervention collaboration did simulated navigation between two sites 5 miles apart (web summary, simulation only). Neuro not yet. Nasdaq/PR: full launch April 2026, territories 4 to 8, goal 12 by end 2026. | X2 2026-11-08: cornelis2026_in read in full; mechanism and DOF count not described there.
This record
- Read level
- full — full (cornelis2026_in); abstract + web (rest)
- Picture
- https://www.microbotmedical.com/wp-content/uploads/2026/04/LIBERTY-Base_image_v2-scaled.webp (RGBA, found via microbotmedical.com WordPress media API; home page https://www.microbotmedical.com/) ↗ — licence: press image (Microbot Medical); grade A
- Picture changes
- cropped (547,253)-(2095,1499) of 2560x1708, flattened on white; cut = same crop with the publisher alpha (no SAM)
- Found by
- commercial: Search of commercial and clinical-stage systems.
- Data
- JSON · YAML:
records/robots/liberty_microbot2024.yaml - Correction
- Suggest a correction [repository not created yet]
