Academic bedside robots · sjtu_coronary_meng2025
SJTU PCI robot
SJTU master-slave PCI robot with magnetic-coupling modular drive and thin-film force sensing
 1 / 2
- Family
- Academic bedside robots (academic)
- Devices
- guidewire (0.014-0.035 in), guide catheter, balloon/stent catheter
- Degrees of freedom
- 4 (guidewire advance and rotation; catheter linear insertion; balloon/stent linear transport)
- Push
- Friction rollers
- Twist
- Other
- Tested up to
- Bench
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Bench
- What was tested
- Simulink control simulation plus hardware experiments; number of trials N.R.
- Key numbers
- Displacement error within +/-1 mm and angular error within +/-15 deg; Smith predictor + RBF self-tuning PID
Mechanism
- Push (translation)
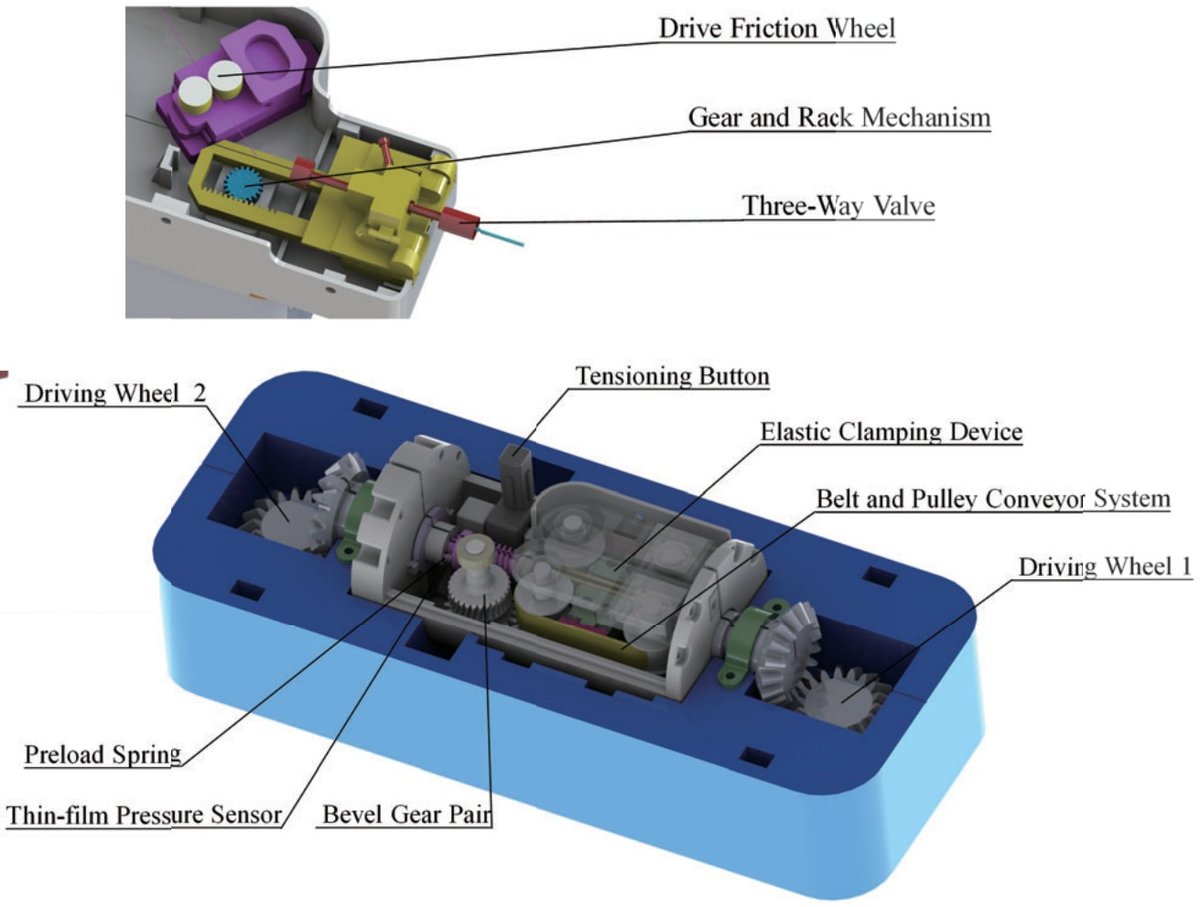
- friction-roller (guidewire: gear-driven dual friction wheels; balloon/stent: symmetric friction wheels; catheter: gear-rack clamping with linear drive)
- Twist (rotation)
- Guidewire rotated continuously through drive wheel 1 and bevel gears (360 deg)
- Device range
- guidewire 0.014 in to 0.035 in
- Target anatomy
- coronary PCI (complex vascular geometries in simulation and bench)
Sensing and interface
- Force sensing
- Thin-film pressure sensors between worm and housing give axial guidewire force
- Leader and haptics
- N.R.
- Imaging
- N.R.
- Sterility
- Electromechanical decoupling by magnetic coupling torque transmission so the distal module can be a hygienic, separable part
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- Simulink control-loop model only
- Sim-trained controller
- none found
Versions
- Lineage
- meng2025_design (ROBIO 2025)
Sources
- Design and Control of a Robotic System for Coronary Interventions · 2025 IEEE International Conference on Robotics and Biomimetics (ROBIO), 2025 · doi:10.1109/robio66223.2025.11378419 [meng2025_design]
Notes
- Notes
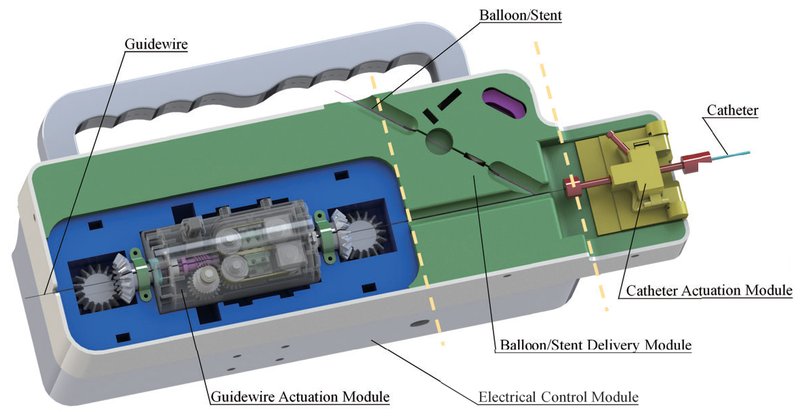
- CAD render only; no prototype photo in the paper.
This record
- Read level
- full — full (meng2025 text)
- Picture
- meng2025_design Fig. 1 (structure of the robotic system), ROBIO 2025, doi:10.1109/ROBIO66223.2025.11378419 ↗ — licence: publisher copyright; grade C
- Picture changes
- figure rebuilt from its 19 embedded raster tiles at native scale (labels and leader lines are inside the tiles); main panel cropped; fragments of neighbouring panels whitened; not upscaled
- Found by
- academic: Search of academic bedside robots.
- Data
- JSON · YAML:
records/robots/sjtu_coronary_meng2025.yaml - Correction
- Suggest a correction [repository not created yet]