Academic bedside robots · tut_ma2021
TUT catheter system
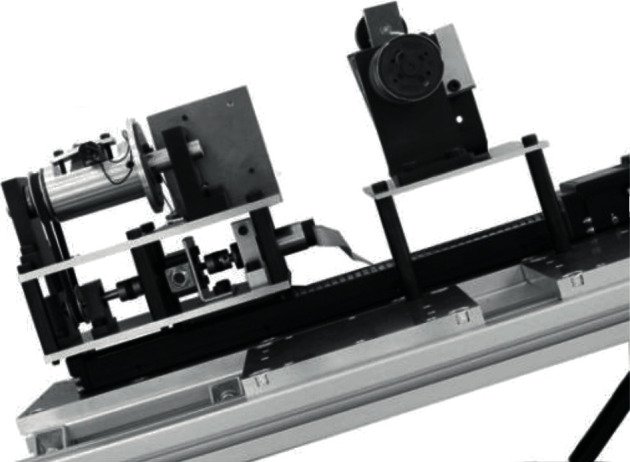
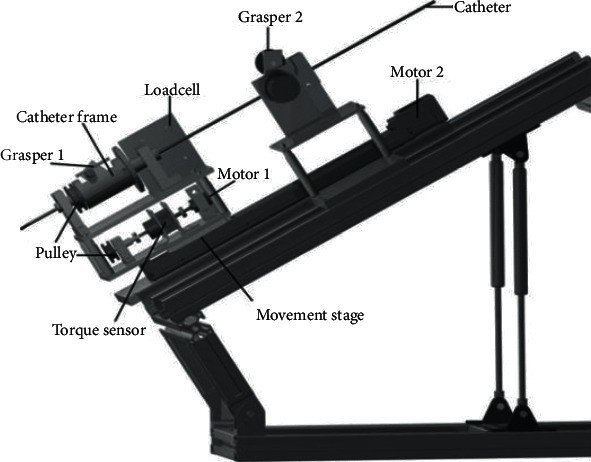
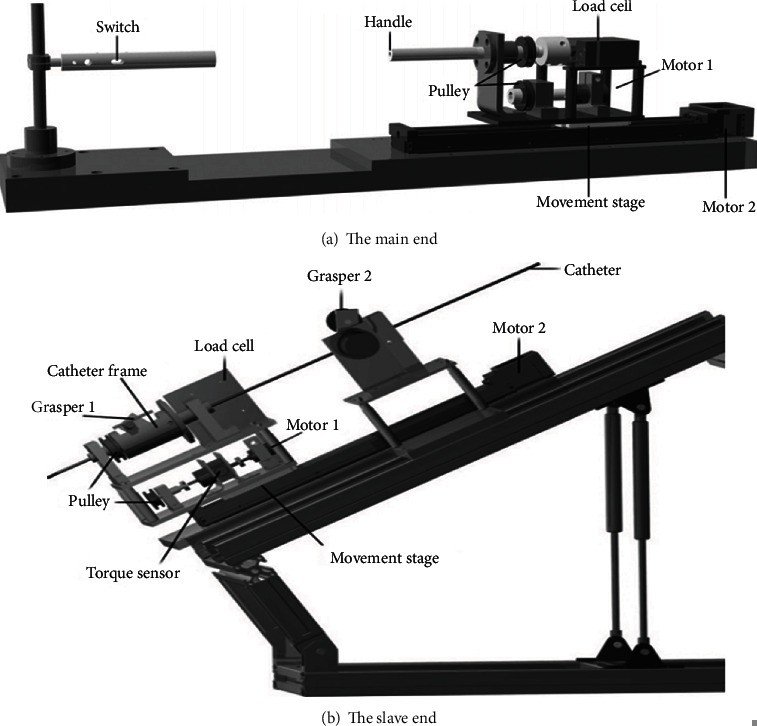
TUT catheter operating system with real-catheter master and clamp-relay slave
 1 / 6
- Family
- Academic bedside robots (academic)
- Devices
- catheter
- Degrees of freedom
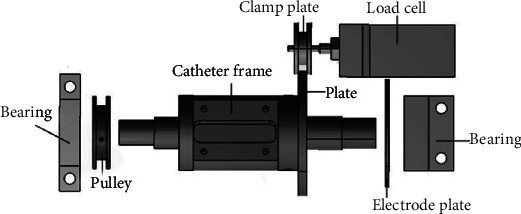
- 2 (axial + rotation frames)
- Push
- Clamp relay
- Twist
- Rotating drive unit
- Tested up to
- Bench
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Bench
- What was tested
- simulation and axial-displacement bench tests only; no phantom or animal (ma2021_design)
- Key numbers
- axial stroke 300 mm, push/withdraw 30 mm/s; BP-PID max axial error < 1.5 mm, mean 0.48 mm; step-response overshoot 20% (PID) vs 12% (BP-PID) in simulation; Maxon EC32 axial motor; DSP TMS320F28335, serial 19200 baud (ma2021_design)
Mechanism
- Push (translation)
- clamp-relay
- Twist (rotation)
- rotating frame (drive N.R.)
- Device range
- N.R.
- Target anatomy
- N.R.
Sensing and interface
- Force sensing
- proximal thrust measured during insertion; force sensor UNCSR and torque sensor OPT-563B listed (ma2021_design, PMC HTML)
- Leader and haptics
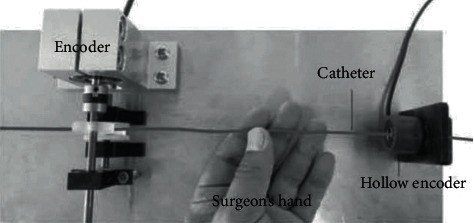
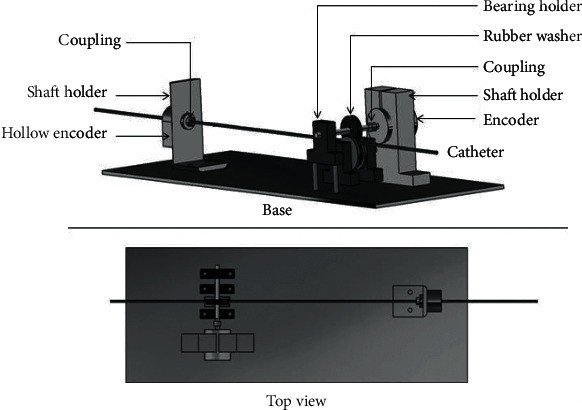
- real catheter used as the input handle on a pulley; DC motor with encoder on the pulley gives force/torque feedback
- Imaging
- N.R.
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found (controller simulated as a mass-spring-damper only)
- Sim-trained controller
- none found
Versions
- Lineage
- 2020 robotic catheter manipulation system with BP-neural-network PID (ma2020_development, title); 2021 new catheter operating system (ma2021_design)
Sources
- Design of a New Catheter Operating System for the Surgical Robot · Applied Bionics and Biomechanics, 2021 · doi:10.1155/2021/8898311 [ma2021_design]
- Development of a Robotic Catheter Manipulation System Based on BP Neural Network PID Controller · Applied Bionics and Biomechanics, 2020 · doi:10.1155/2020/8870106 [ma2020_development]
Notes
- Notes
- Same Tianjin Key Lab (TUT) as A2's tianjin_song2023 but a different robot; lineage of Shuxiang Guo's Kagawa/BIT group.
This record
- Read level
- partial — partial (PMC full-text HTML read through WebFetch)
- Picture
- ma2021_design Fig. 3 slave manipulator, https://cdn.ncbi.nlm.nih.gov/pmc/blobs/69b3/7861939/0d63d0cf83e2/ABB2021-8898311.003.jpg (page https://pmc.ncbi.nlm.nih.gov/articles/PMC7861939/) ↗ — licence: CC BY (Creative Commons Attribution License, as stated); grade C
- Picture changes
- PMC image as served; no edits; not upscaled
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/tut_ma2021.yaml - Correction
- Suggest a correction [repository not created yet]