Commercial and clinical-stage systems · roses_danieli2022
ROSES
ROSES (RObotic System for Endovascular Surgery)
 1 / 9
- Family
- Commercial and clinical-stage systems (clinical-stage)
- Devices
- guidewire plus balloon or stent catheter per slave; first-in-human: 6 Fr JR4 guide, 0.014 in BMW wire, 2.0 x 12 mm balloon, 2.5 x 15 mm DES (indolfi2023_first)
- Degrees of freedom
- 3 per slave (catheter advance/retract, guidewire advance/retract, common rotation); one console drives up to three slaves (techbriefs 2019 entry)
- Push
- Friction rollers
- Twist
- Rotating drive unit
- Tested up to
- Human
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Human
- What was tested
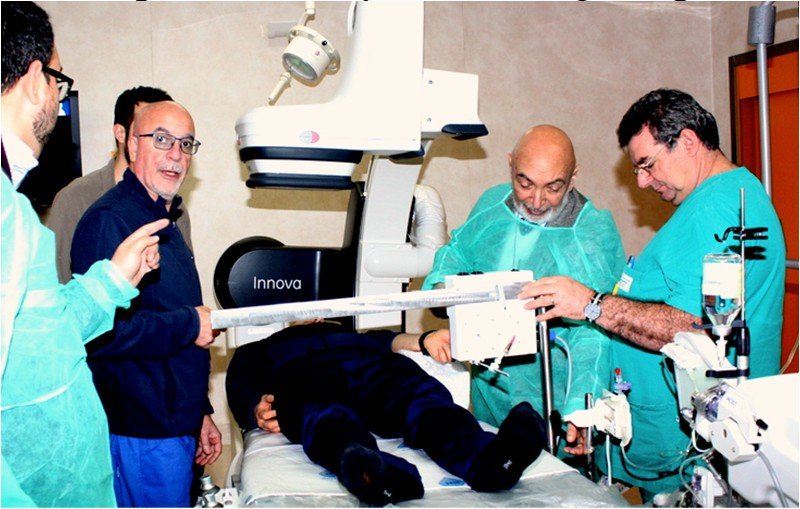
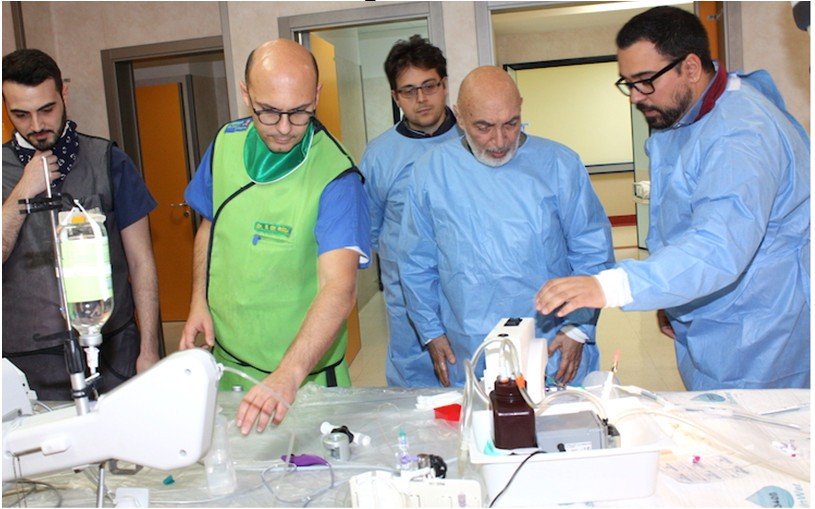
- in vitro tubing and X-ray tests; first patient 22 Jan 2019 (two stents), trials 'still in progress' in 2022 (danieli2022_development Sec. 2); 2023 case report of one 64-year-old patient (R-PCI of a PL branch)
- Key numbers
- case: procedure 35 min, contrast 110 mL, stent result satisfactory at 2.5-year follow-up (indolfi2023_first); fluoroscopy time N.R.
Mechanism
- Push (translation)
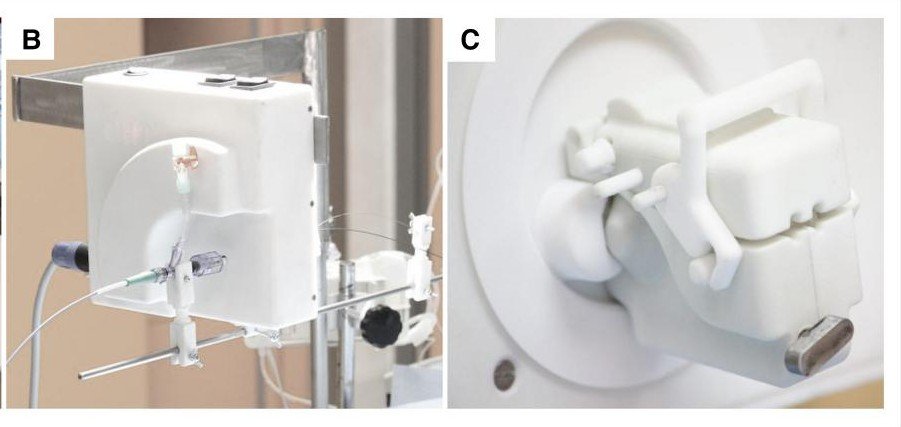
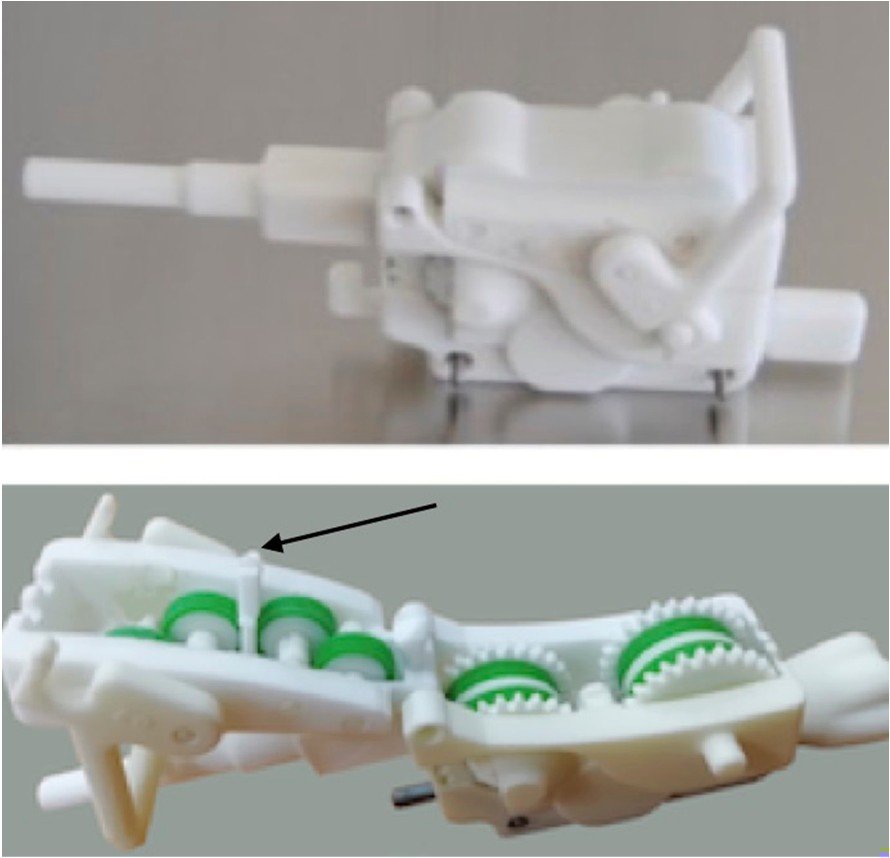
- friction-roller (3-D-printed disposables convert gear rotation into advance/retract through friction wheels)
- Twist (rotation)
- the disposable is rotated by a concentric gear train in the robot actuator (danieli2022_development Sec. 2)
- Device range
- 0.014 in guidewires to large catheters (36 mm passage in v3); exact Fr range N.R.
- Target anatomy
- coronary PCI; endovascular surgery, large catheters for aneurysm repair or TAVI (cart version)
Sensing and interface
- Force sensing
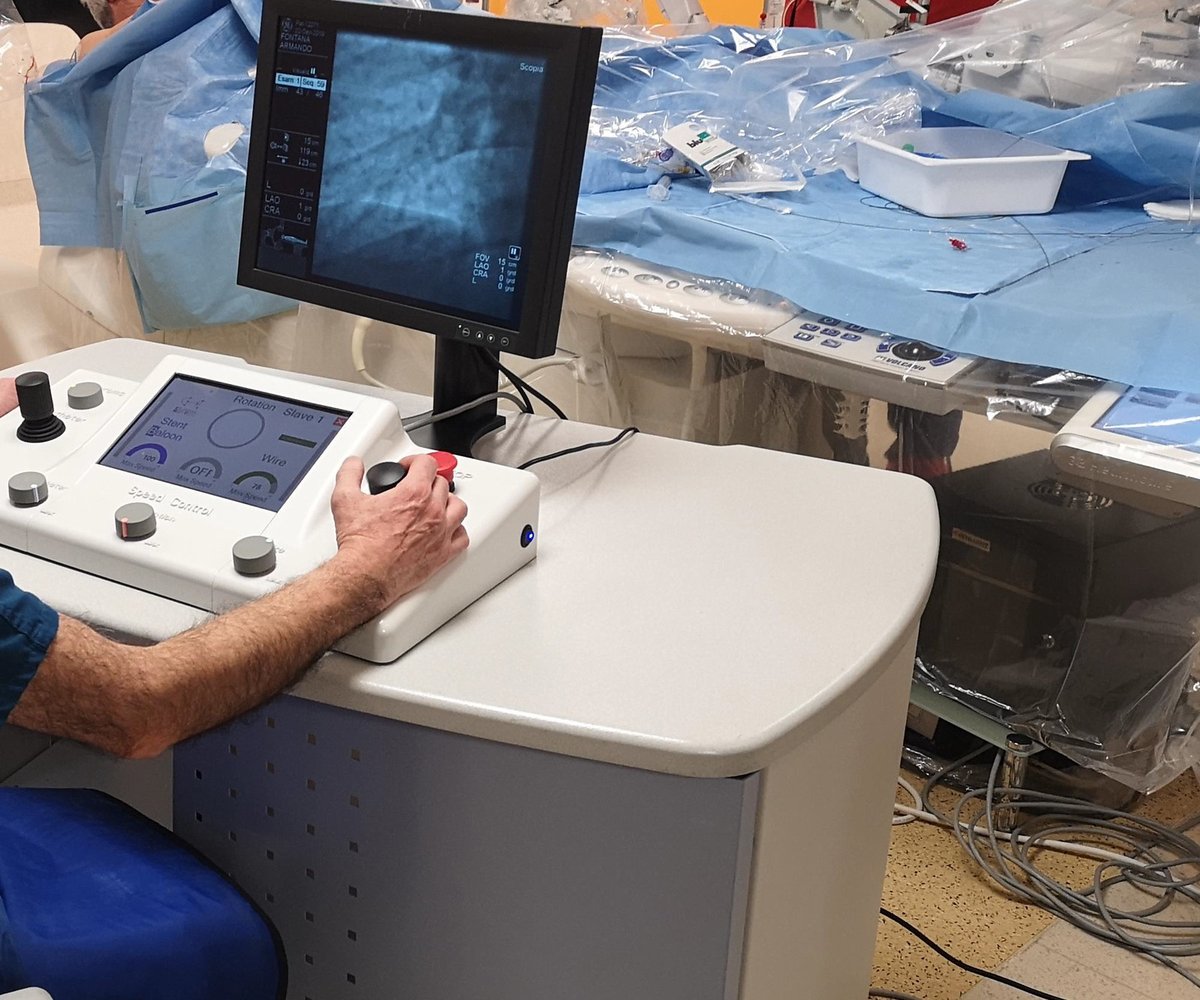
- resistance to advancement shown on the console; cart version measures forces opposed by the patient with a force transducer (danieli2022_development abstract, Sec. 3)
- Leader and haptics
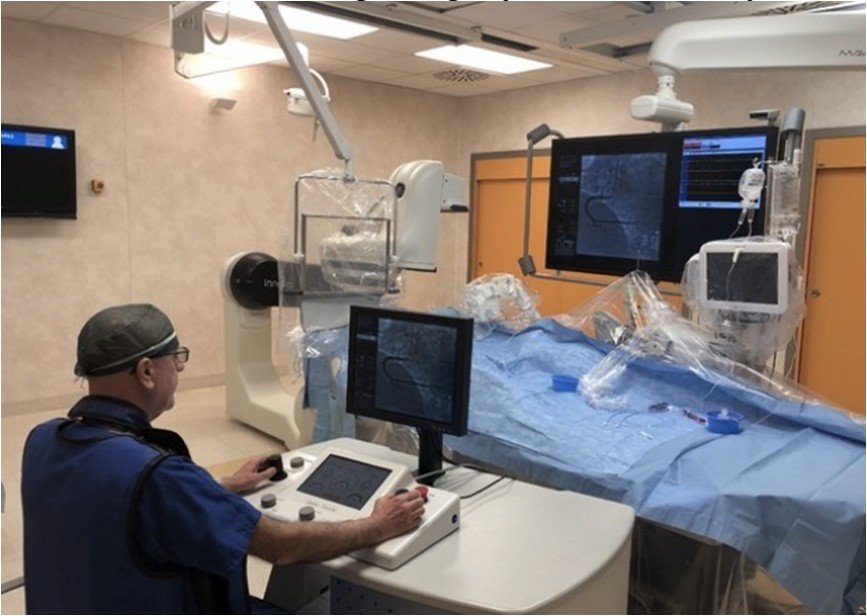
- passive master console with joysticks per track (one for the guidewire, one for devices); no force rendering reported
- Imaging
- fluoroscopy; cockpit inside or outside the cath lab
- Sterility
- sterile disposables in contact with the devices, split upper/lower so they can be removed without withdrawing the device (danieli2022_development abstract)
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found
- Sim-trained controller
- none found
Versions
- Lineage
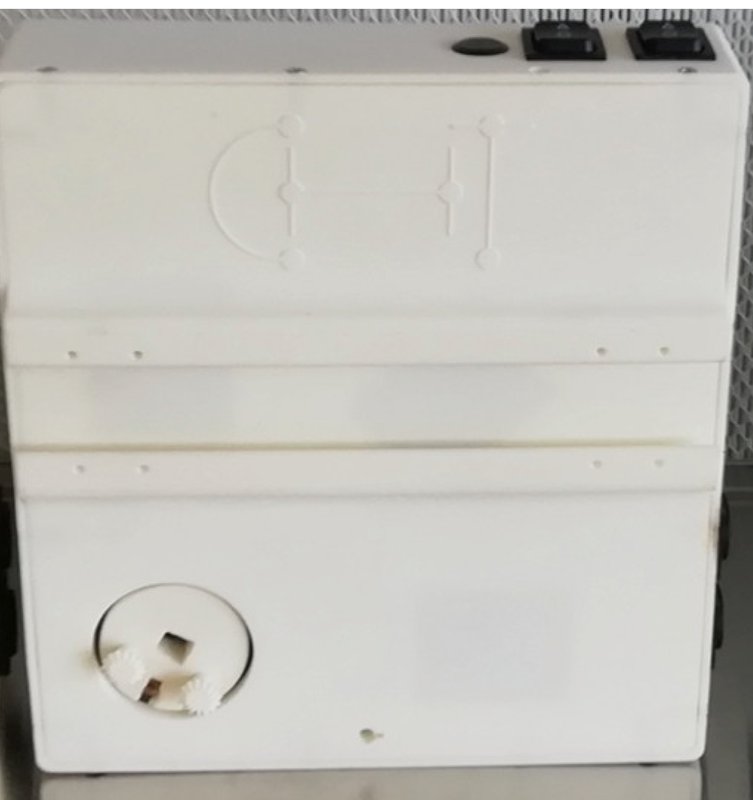
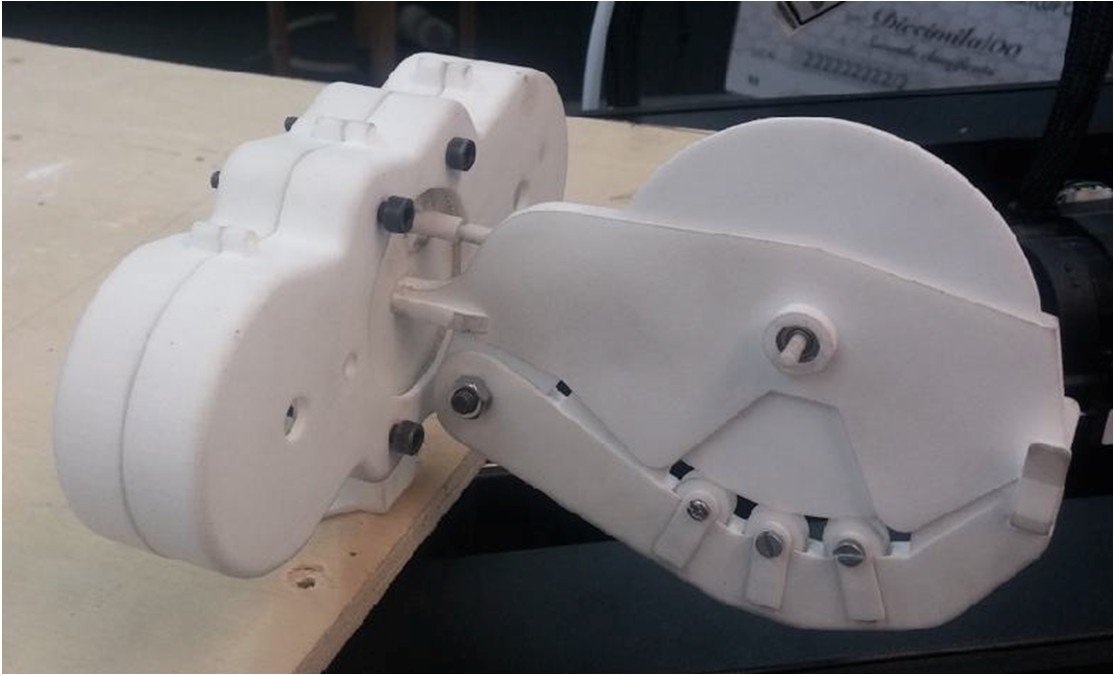
- 2018 PCT patent (ref. 6 of indolfi2023_first); robot actuator v1 (motor axes parallel to the gear train), v2 (motors perpendicular, thinner), v3 (36 mm central passage for haemostasis valve and large catheters) (danieli2022_development Fig. 12); disposables for angioplasty (DA), big catheters (DEBC), movable-core guidewires and a tip-curvature catheter; cart with rail and force transducer for endovascular surgery (Fig. 13); first patient 22 Jan 2019; 2023 case report
Sources
- Development of Disposables and Accessories for ROSES and Their In Vitro Experimentation · Applied Mechanics, 2022 · doi:10.3390/applmech3030054 [danieli2022_development]
- First-in-human robotic percutaneous coronary intervention by the ROSES robotic system: a case report · European Heart Journal - Case Reports, 2023 · doi:10.1093/ehjcr/ytad506 [indolfi2023_first]
Notes
- Notes
- In S8_systems.csv but in no catalogue file before A9. A larger multicentre pivotal trial is described as ongoing in the case report (status not found).
This record
- Read level
- full — full (danieli2022_development, indolfi2023_first); web (techbriefs 2019 contest entry)
- Picture
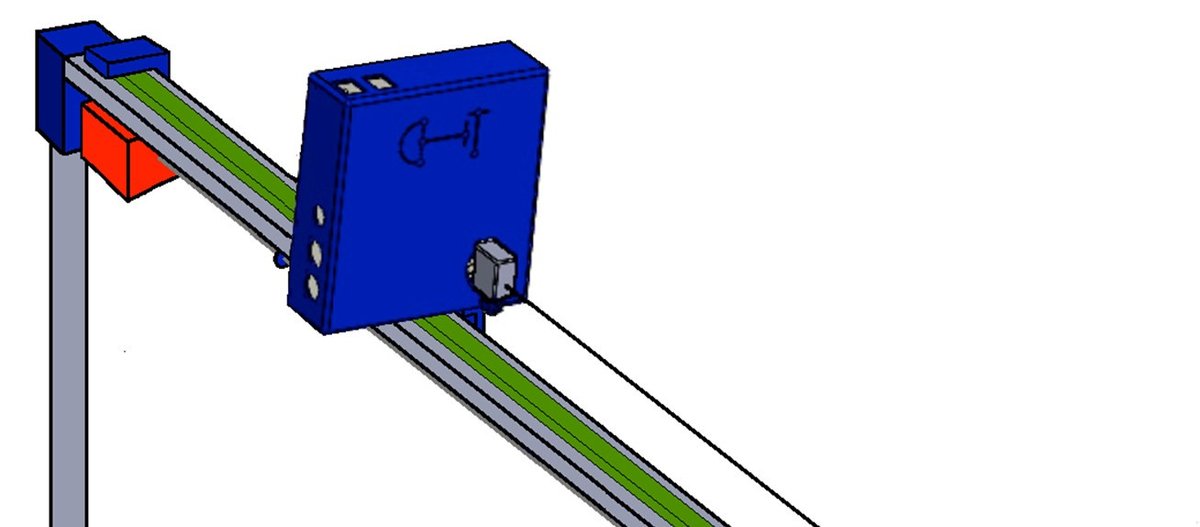
- danieli2022_development Fig. 12, centre unit (robot actuator, second edition); https://mdpi-res.com/applmech/applmech-03-00054/article_deploy/html/images/applmech-03-00054-g012.png (article https://doi.org/10.3390/applmech3030054) ↗ — licence: CC BY 4.0; grade B
- Picture changes
- full-size MDPI figure image; cropped to the centre unit; not upscaled
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/roses_danieli2022.yaml - Correction
- Suggest a correction [repository not created yet]