Academic bedside robots · harvard_ice_loschak2017
ICE catheter robot
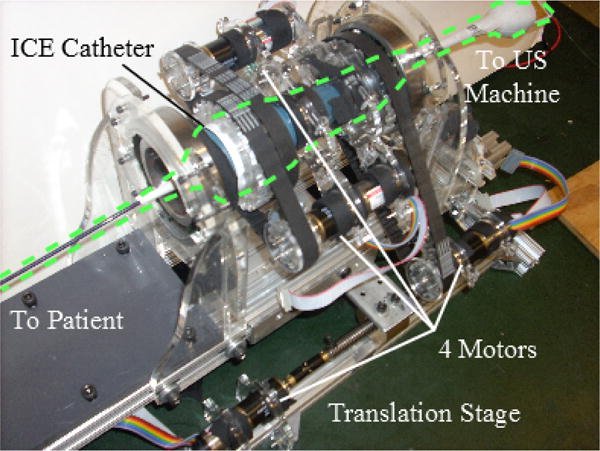
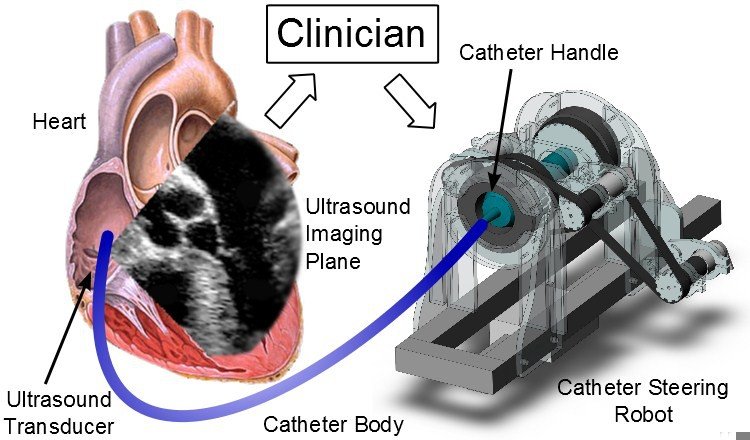
Harvard 4-DOF robotic ultrasound (ICE) catheter steering system
 1 / 2
- Family
- Academic bedside robots (academic)
- Devices
- AcuNav 10 Fr (3.30 mm) 110 cm ICE catheter with 64-element array (Biosense Webster) (TRO 2017 Sec. II)
- Degrees of freedom
- 4 (pitch knob, yaw knob, handle roll, handle translation)
- Push
- Linear stage
- Twist
- Handle or knob
- Tested up to
- Animal
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Animal
- What was tested
- 2017: benchtop water tank with gelatin left-atrium phantom; 2020: one 64 kg live pig, US catheter via a 14 Fr femoral-vein introducer into the right atrium, target 6 Fr quadpolar catheter in the left ventricle, heart paced at 120 bpm; volume-imaging steps (18 steps, 133 s), instrument tracking (329 s) and tracking a manually steered target (431 s) (IJRR 2020 Sec. 3.2-3.3)
- Key numbers
- benchtop position RMS 1.9 mm; imager spinning 0.25 deg RMS with 1.0 mm tip drift; 3-D pointing 1.6 mm and 0.17 deg RMS; test speeds <= 1 mm/s and <= 0.5 deg/s; 6.5 W brushed DC motors with Maxon EPOS2 (TRO 2017); in vivo 1.05 mm and 1.33 deg mean absolute error with respiratory compensation (IJRR 2020 abstract); in vivo step imaging 2.56 mm / 0.98 deg MAE over 134 s of well-modelled breathing, 6.59 mm / 2.27 deg when the model was outdated; manual-target tracking 2.81 deg MAE and 2.14 mm position MAE over 431 s (Sec. 3.3)
Mechanism
- Push (translation)
- linear-stage+clamp (lead-screw translation stage carries the whole handle)
- Twist (rotation)
- motor grounded to the stage turns the handle by timing belt; two handle-mounted motors turn the knobs by timing belts
- Device range
- one ICE catheter model
- Target anatomy
- intracardiac echocardiography in the heart chambers
Sensing and interface
- Force sensing
- none reported
- Leader and haptics
- none (automatic target-based steering)
- Imaging
- ICE ultrasound; EM tracking of instrument tip in tests; IJRR 2020: four EM trackers (two on the US catheter, one on the target catheter, one on the chest wall for respiration) (Sec. 3.2)
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found
- Sim-trained controller
- none found
Versions
- Lineage
- 2017 TRO algorithms for automatically pointing ICE catheters, benchtop (full, PMC author manuscript); 2020 IJRR in-vivo automatic steering with respiratory motion compensation (full, loschak2020_automatically); earlier in vivo navigation study Degirmenci et al. 2016 (cited in loschak2020 Sec. 1, not read)
Sources
- Algorithms for Automatically Pointing Ultrasound Imaging Catheters · IEEE Transactions on Robotics, 2017 · doi:10.1109/tro.2016.2623331 [loschak2017_algorithms]
- Automatically steering cardiac catheters in vivo with respiratory motion compensation · The International Journal of Robotics Research, 2020 · doi:10.1177/0278364920903785 [loschak2020_automatically]
Notes
- Notes
- Second ICE-handle robot next to the Siemens one (siemens_ice_kim2020), which cites it as prior work. | 2026-11-08 X3: IJRR 2020 read in full; it has no photograph of the robot (only a small drawing in Fig. 3), so the main picture stays the TRO 2017 Fig. 11; one 64 kg pig confirms the animal level
This record
- Read level
- full — full (TRO 2017 via PMC HTML; IJRR 2020, )
- Picture
- loschak2017_algorithms Fig. 11 (US catheter steering robot with 4 DOF); https://cdn.ncbi.nlm.nih.gov/pmc/blobs/5311/5295822/ec2024e38a33/nihms820364f11.jpg (PMC5295822) ↗ — licence: publisher copyright (IEEE; NIH author manuscript in PMC); grade C
- Picture changes
- PMC figure image as is; not upscaled; labels and green dashed outline left in place (they cross the robot)
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/harvard_ice_loschak2017.yaml - Correction
- Suggest a correction [repository not created yet]