Academic bedside robots · sjtu_xie_shen2019
SJTU hybrid drive
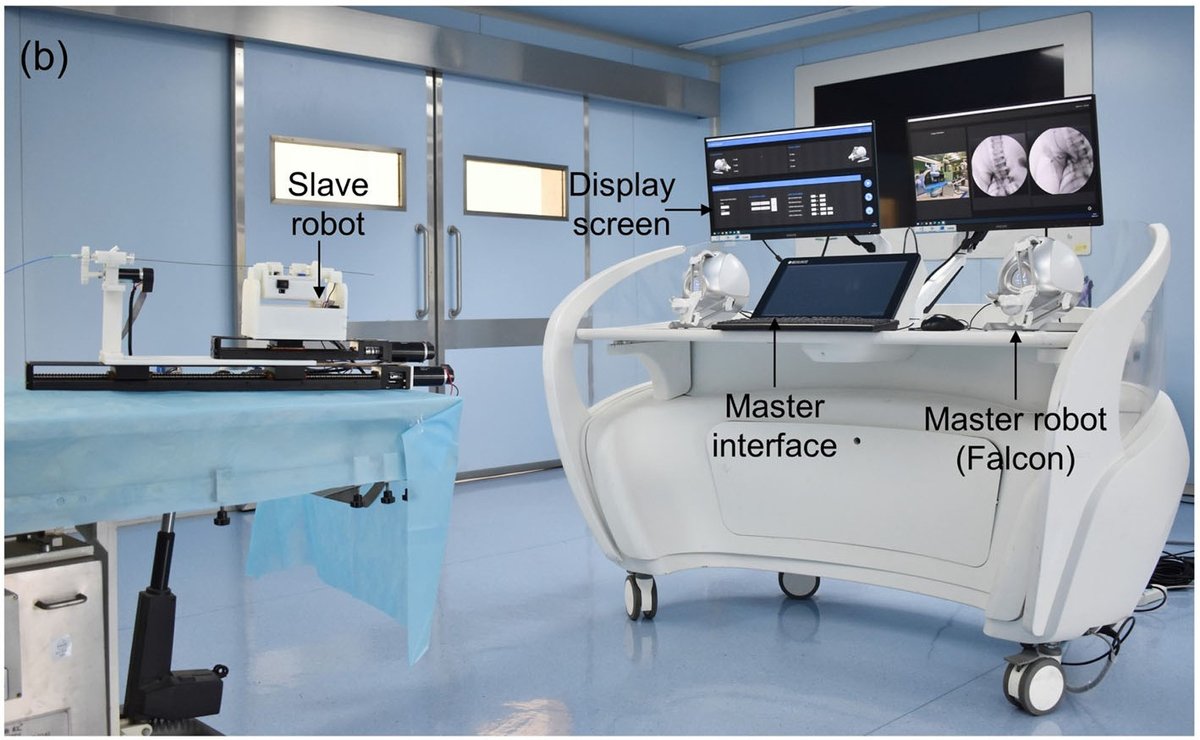
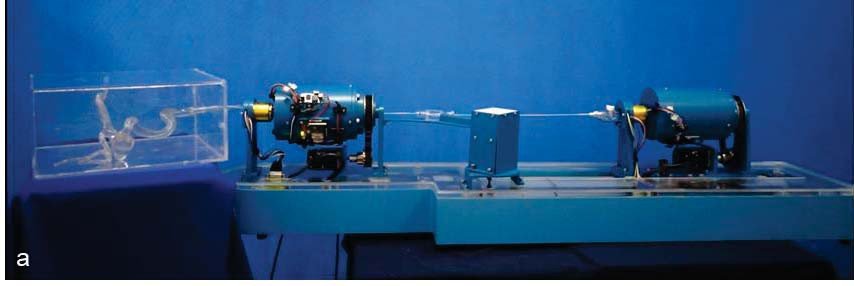
SJTU master-slave vascular intervention robot with progressive (friction + clamp) drive and force display
 1 / 13
- Family
- Academic bedside robots (academic)
- Devices
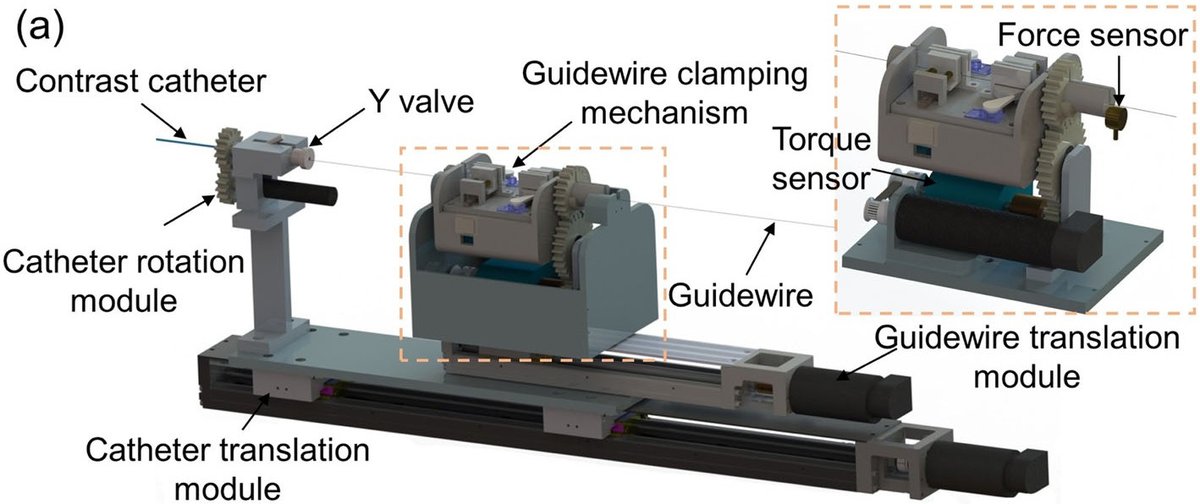
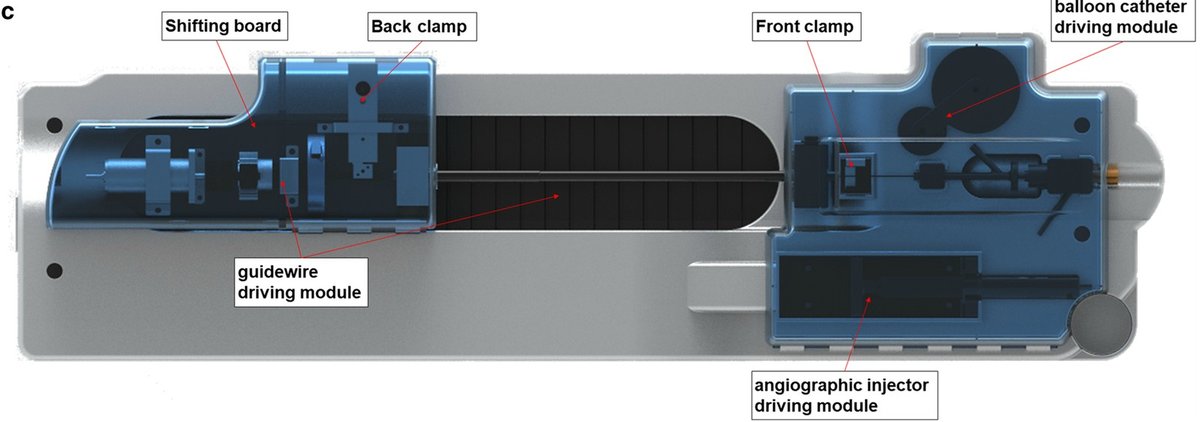
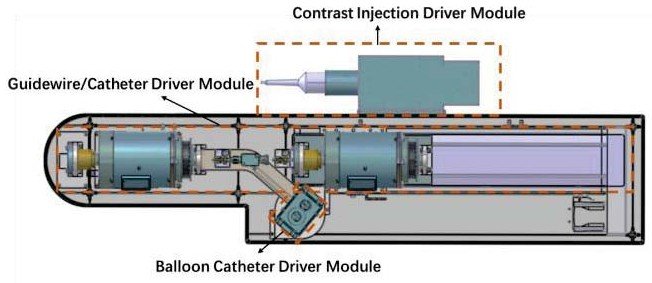
- guidewire (0.035 in in wang2024), balloon catheter, plus contrast injector
- Degrees of freedom
- 3 plus injector (S8 evidence reading of shen2019)
- Push
- Other drives
- Twist
- Not reported
- Tested up to
- Animal
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Animal
- What was tested
- shen2019: bench performance tests plus four in vivo swine trials including carotid stent revascularisation; wang2024: silicone left-coronary model, five repeats per condition
- Key numbers
- Translational error <= 0.45 %, rotational error <= 2.6 deg, contrast injection error < 0.2 mL (shen2019 abstract); safety threshold 0.3 N and distal error larger than proximal error (wang2024, S8 evidence)
Mechanism
- Push (translation)
- friction-roller + clamp hybrid ('progressive' drive; guidewire clamps on a shifting board, balloon catheter on a friction module; shen2019 Fig. 1c)
- Twist (rotation)
- Guidewire rotation by the actuator (mechanism detail not extracted; text of shen2019 is column-mangled)
- Device range
- 0.035 in guidewire (wang2024)
- Target anatomy
- carotid and coronary (swine; left coronary silicone model)
Sensing and interface
- Force sensing
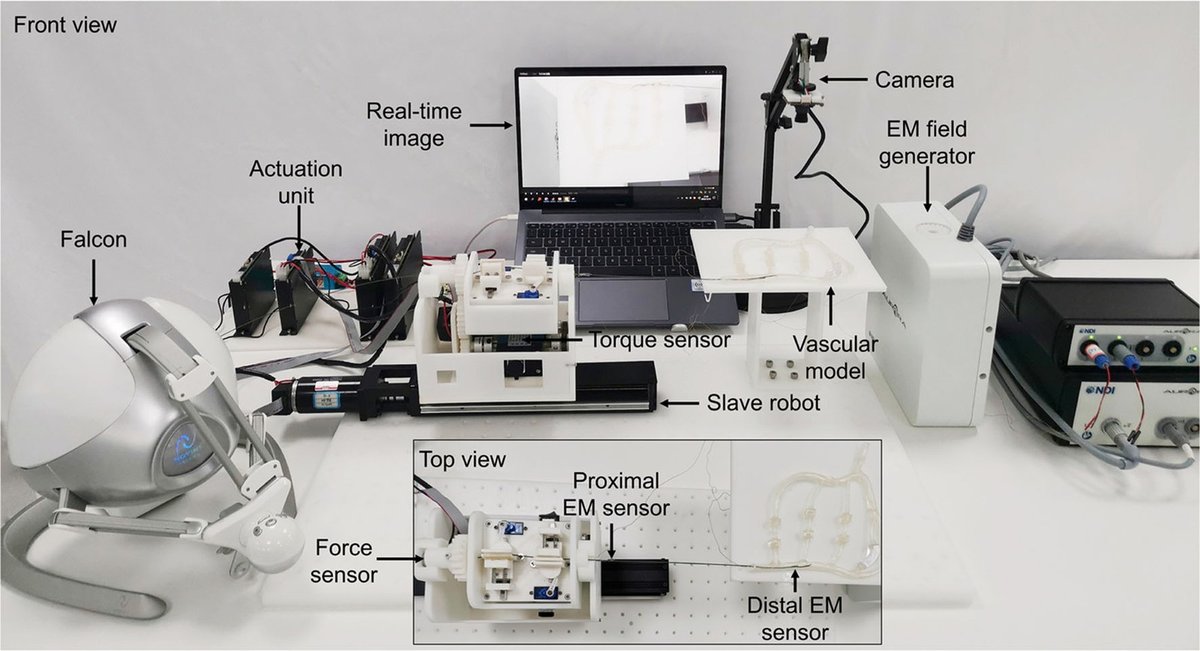
- Force and torque at the drive (shen2019); wang2024 adds force sensors at the proximal guidewire and electromagnetic (Aurora) sensors at both ends for delivered motion
- Leader and haptics
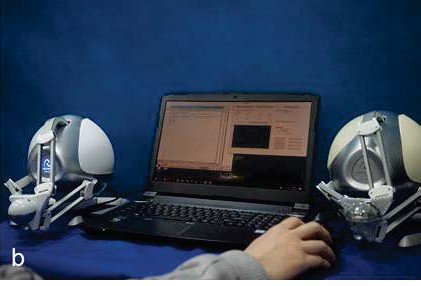
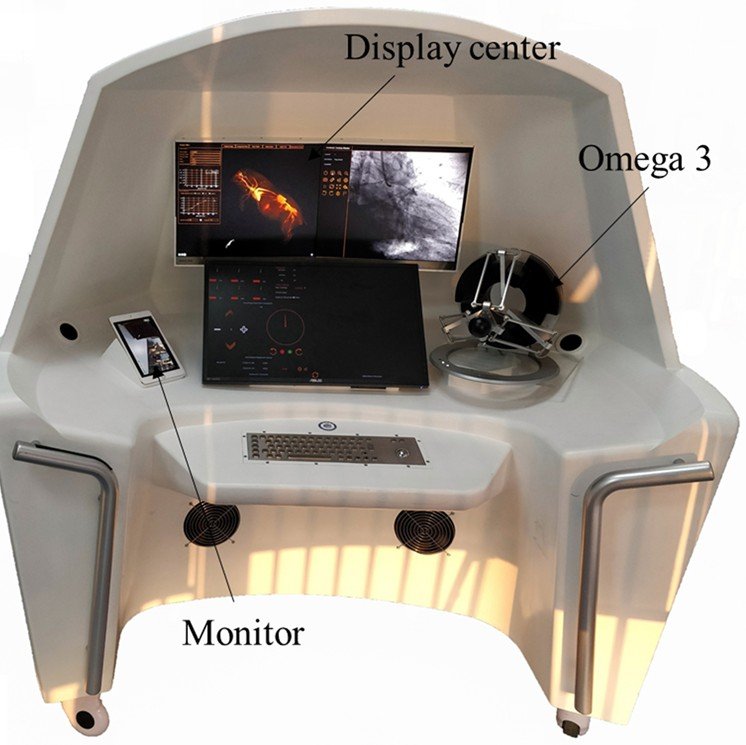
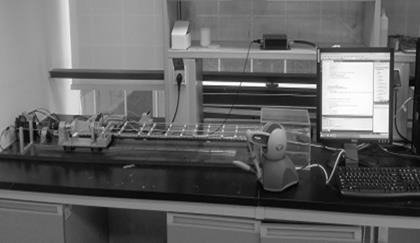
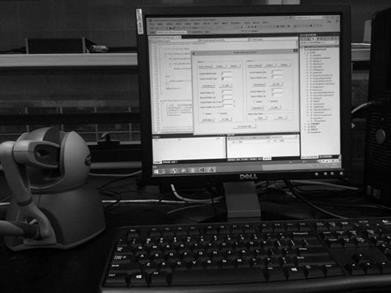
- Omega 3 (Force Dimension) in a console with display (shen2019 Fig. 1a); MRF leader in liu2022
- Imaging
- X-ray angiography in the swine trials; MR N.R.
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found (control simulations in MATLAB only)
- Sim-trained controller
- none found
Versions
- Lineage
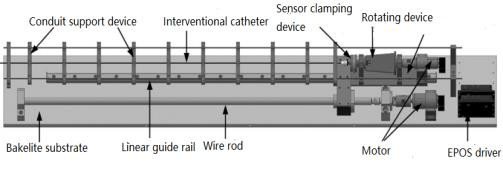
- xiang2019_masterslave (RO-MAN 2019: guidewire between two electric grippers on a lead-screw base, balloon catheter by friction wheels, two master manipulators, Kalman filter) -> shen2019_novel (IJCARS 2019: hybrid progressive drive, contrast injector, Omega 3 leader, in vivo swine) -> liu2022_magnetorheological (MRF leader, abstract not read) -> wang2024_improved (force sensors integrated, admittance control); 2016-17: earlier SJTU (Le Xie, Hao Shen) lead-screw catheter/guidewire pusher with a chuck on an ATI Nano43 six-axis sensor (Lin et al. 2016, Machine Design & Research), run by Wuhan Univ. of Technology as MISR with a Phantom Omni, 3:1 motion scaling and vibration warning, PVC-tube phantom (Xie 2017 ACIRS; Alekseeva 2025 Table 3 row 3, Fig. 10b) (xie2017_masterslave; alekseeva2025_design); 2012: guidewire tele-manipulation system with a laser-mouse-sensor motion detector as leader and a guidewire manipulation appliance, tested by operating time against tip-to-target distance and angle (Shen 2012 Zhongguo Yi Liao Qi Xie Za Zhi 36:32-35, PMID 22571149); group link only by Zhao 2022 Table 1 row 10c (PubMed affiliation: The 455 Hospital of PLA, Shanghai 200240) (shen2012_design; zhao2022_remote)
Sources
- A novel robotic system for vascular intervention: principles, performances, and applications · International Journal of Computer Assisted Radiology and Surgery, 2019 · doi:10.1007/s11548-018-01906-w [shen2019_novel]
- Master-Slave Guidewire and Catheter Robotic System for Cardiovascular Intervention · 2019 28th IEEE International Conference on Robot and Human Interactive Communication (RO-MAN), 2019 · doi:10.1109/ro-man46459.2019.8956423 [xiang2019_masterslave]
- Improved precise guidewire delivery of a cardiovascular interventional surgery robot based on admittance control · International Journal of Computer Assisted Radiology and Surgery, 2023 · doi:10.1007/s11548-023-03017-7 [wang2024_improved]
- A Magnetorheological Fluid Based Force Feedback Master Robot for Vascular Interventional Surgery · Journal of Intelligent & Robotic Systems, 2022 · doi:10.1007/s10846-022-01716-y [liu2022_magnetorheological]
- Research and implementation of master-slave control for interventional robot system · 2017 2nd Asia-Pacific Conference on Intelligent Robot Systems (ACIRS), 2017 · doi:10.1109/ACIRS.2017.7986099 [xie2017_masterslave]
- The Design of Endovascular Robots for Cardiac Interventions: A Survey · Journal of Field Robotics, 2024 · doi:10.1002/rob.22480 [alekseeva2025_design]
- shen2012_design · no DOI on file [shen2012_design]
- Remote vascular interventional surgery robotics: a literature review · Quantitative Imaging in Medicine and Surgery, 2022 · doi:10.21037/qims-21-792 [zhao2022_remote]
Notes
- Notes
- S8 evidence lists this system as 'SJTU-SIAT'; the shen2019 affiliation lines show SJTU, a CAS institute in Beijing and PUMCH, so SIAT is not confirmed.
This record
- Read level
- partial — partial (shen2019, wang2024, xiang2019 text); abstract (liu2022)
- Picture
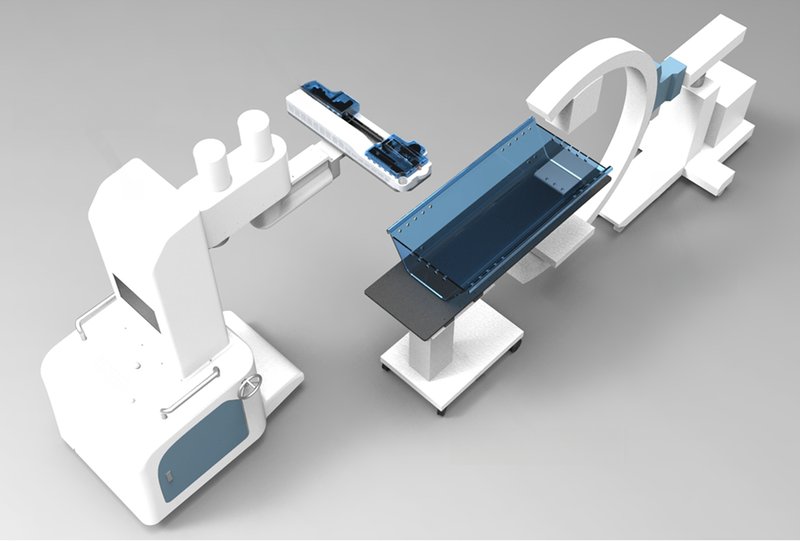
- shen2019_novel Fig. 1(b) (patient-side system: robotic arm, actuator, table, C-arm), IJCARS 2019, doi:10.1007/s11548-018-01906-w ↗ — licence: publisher copyright; grade B
- Picture changes
- native extract (2032x1561); cropped to panel (b); 4 text tags and 4 leader arrows erased on the plain grey render background (LaMa, two passes); not upscaled
- Found by
- academic: Search of academic bedside robots.
- Data
- JSON · YAML:
records/robots/sjtu_xie_shen2019.yaml - Correction
- Suggest a correction [repository not created yet]