Academic bedside robots · polimi_zhang2022
MitraClip stabiliser
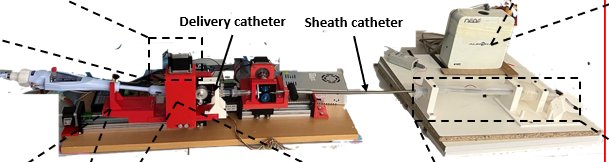
PoliMi motorised stabiliser for the MitraClip delivery catheter with IRL path planning
 1 / 2
- Family
- Academic bedside robots (academic)
- Devices
- Abbott MitraClip delivery catheter, 16 Fr (5.28 mm), 109.5 cm, three pull wires 90 deg apart, inside its sheath (Sec. III-C)
- Degrees of freedom
- 3 (medio-lateral bending, antero-posterior bending, insertion in the sheath)
- Push
- Linear stage
- Twist
- None
- Tested up to
- Phantom
- Sim-to-real
- Yes — A controller or perception model trained in simulation ran on this robot.
Testing
- Highest level
- Phantom
- What was tested
- patient-specific silicone phantom of femoral vein and IVC with rigid fossa ovalis and mitral replicas registered to Unity (Sec. IV-A)
- Key numbers
- closed-loop tip error 1.12 +- 0.75, 1.09 +- 0.68, 1.66 +- 0.62 mm (X/Y/Z), maximum 2.64 mm; PID reduces mean error by 32.68% vs open loop; planned path 60.63 +- 0.96 mm (BC+GAIL) vs 64.99 +- 6.11 mm (manual) (Sec. V)
Mechanism
- Push (translation)
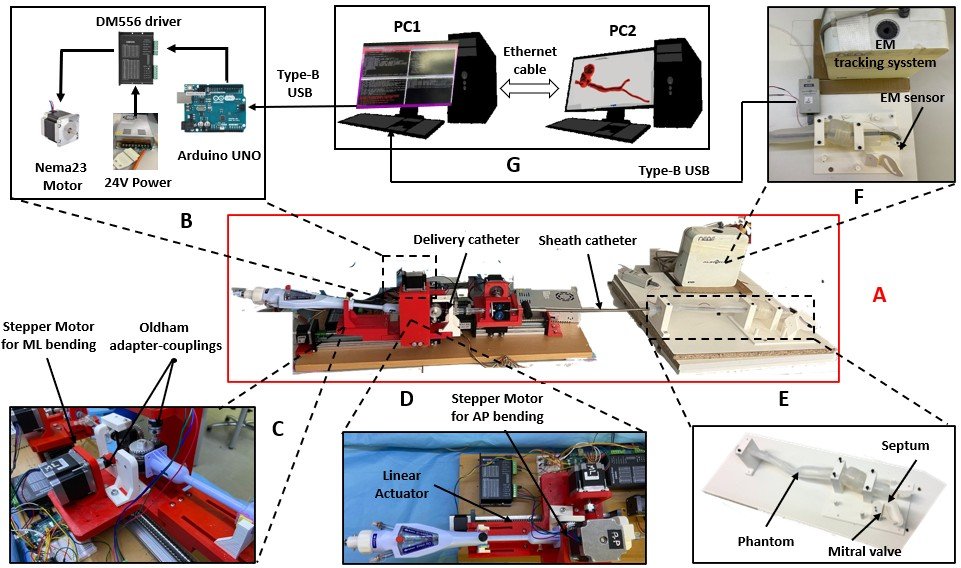
- linear-stage+clamp (linear actuator on the motorised stabiliser advances the delivery catheter)
- Twist (rotation)
- none; two bending DOF actuated through the handle
- Device range
- one clinical delivery system
- Target anatomy
- structural heart: transseptal mitral edge-to-edge repair
Sensing and interface
- Force sensing
- none
- Leader and haptics
- none (autonomous execution of planned path, PID on EM feedback)
- Imaging
- NDI Aurora EM: 5-DOF tip sensor (0.7 +- 1.4 mm) for feedback, 6-DOF probe (0.48 +- 0.88 mm) for recording
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R. (3-D-printed PLA)
Simulation
- Simulation model
- yes: Unity scene of the patient anatomy with a Cosserat-rod-based catheter kinematic model (zhang2022_robotic Sec. III)
- Sim-trained controller
- yes (phantom): a BC+GAIL inverse-RL path planner trained in the Unity environment generated the path that the robot executed in the physical phantom with EM closed loop (zhang2022_robotic Sec. IV, Fig. 7)
- Studies on this robot
- 2022 · Robotic Actuation and Control of a Catheter for Structural Intervention Cardiology — sim N.R.; robot N.R. (position error 1.12 / 1.09 / 1.66 mm X/Y/Z, max 2.64 mm)
Versions
- Lineage
- 2022 IROS (only)
Sources
- Robotic Actuation and Control of a Catheter for Structural Intervention Cardiology · 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022 · doi:10.1109/iros47612.2022.9981676 [zhang2022_robotic]
Notes
- Notes
- Fills the Politecnico di Milano gap of A3. Only robot in A9 with a simulation-trained planner run on hardware.
This record
- Read level
- full
- Picture
- zhang2022_structural_IROS Fig. 4(A) catheter actuation plant (inside the red frame) ↗ — licence: publisher copyright (IEEE); grade C
- Picture changes
- native extract (961x568, the whole composite is one raster); cropped to panel A interior; labels and dashed callout lines are baked in and left; not upscaled
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/polimi_zhang2022.yaml - Correction
- Suggest a correction [repository not created yet]