Academic bedside robots · toronto_nazari2024
EP-catheter robot
Master-follower EP-catheter teleoperation system (Althea II lineage)
 1 / 8
- Family
- Academic bedside robots (academic)
- Devices
- one bidirectional steerable ablation catheter (handle, shaft, knob)
- Degrees of freedom
- 3 (insertion, rotation, knob bending)
- Push
- Clamp relay
- Twist
- Handle or knob
- Tested up to
- Bench
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Bench
- What was tested
- open-loop path tracking: circle, infinity, spiral
- Key numbers
- mean Euclidean error 0.64-1.53 cm; mean absolute error 0.81-1.92 cm; UDP latency 1-2 ms
Mechanism
- Push (translation)
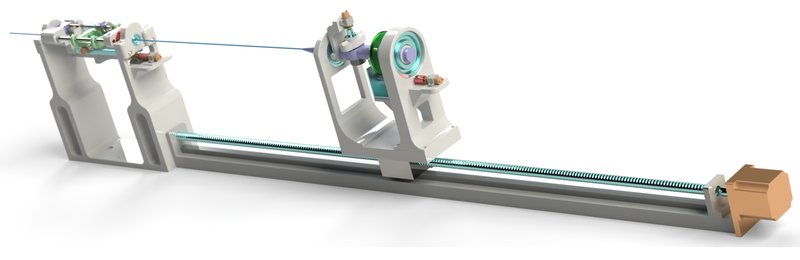
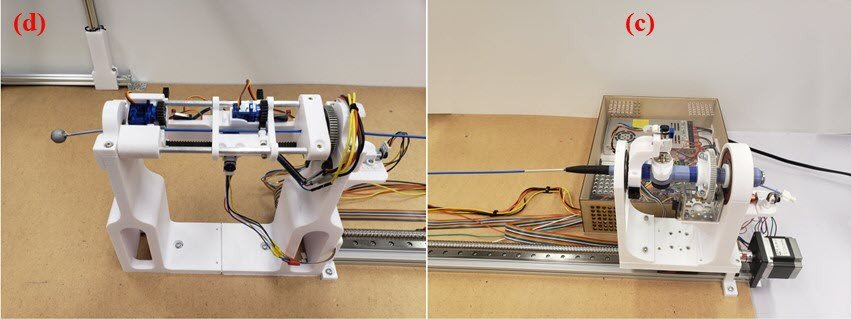
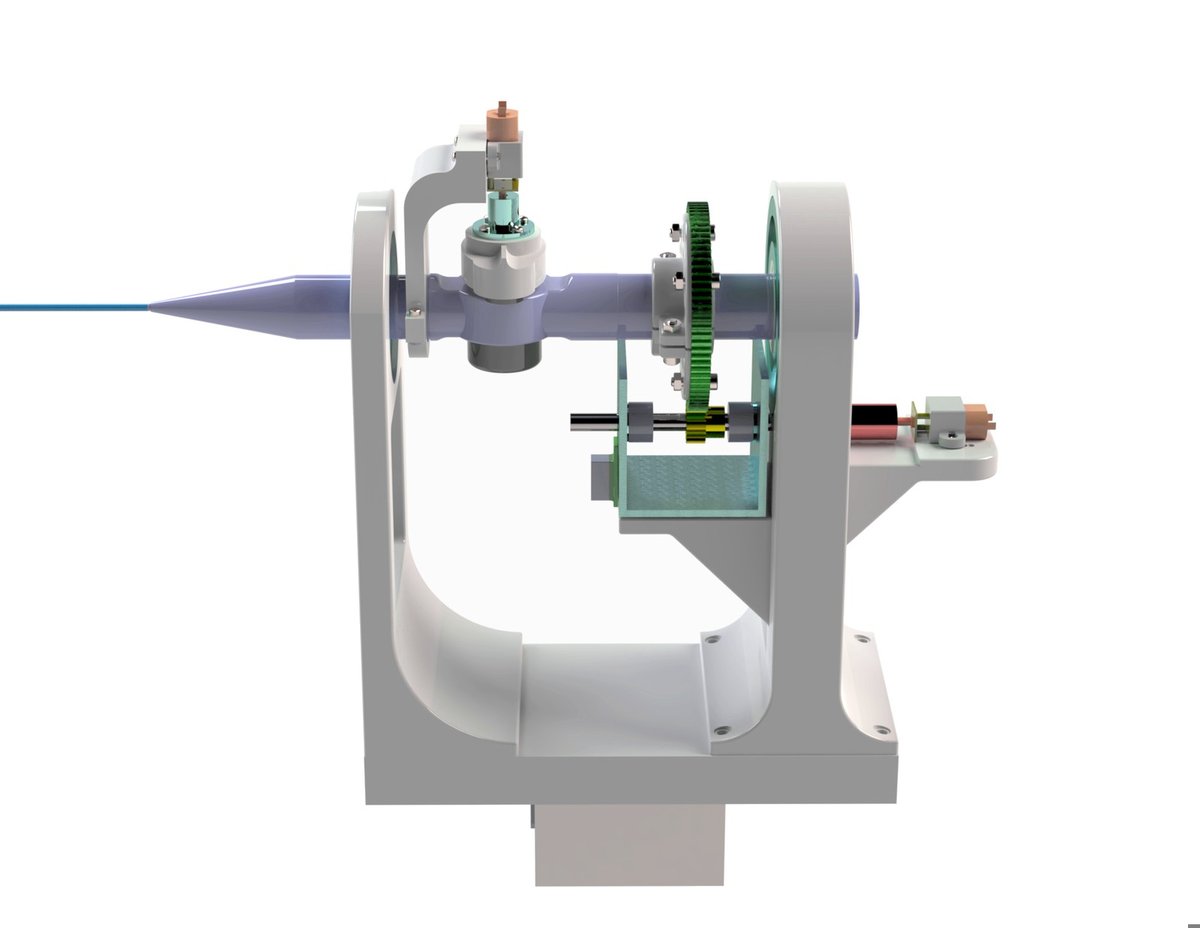
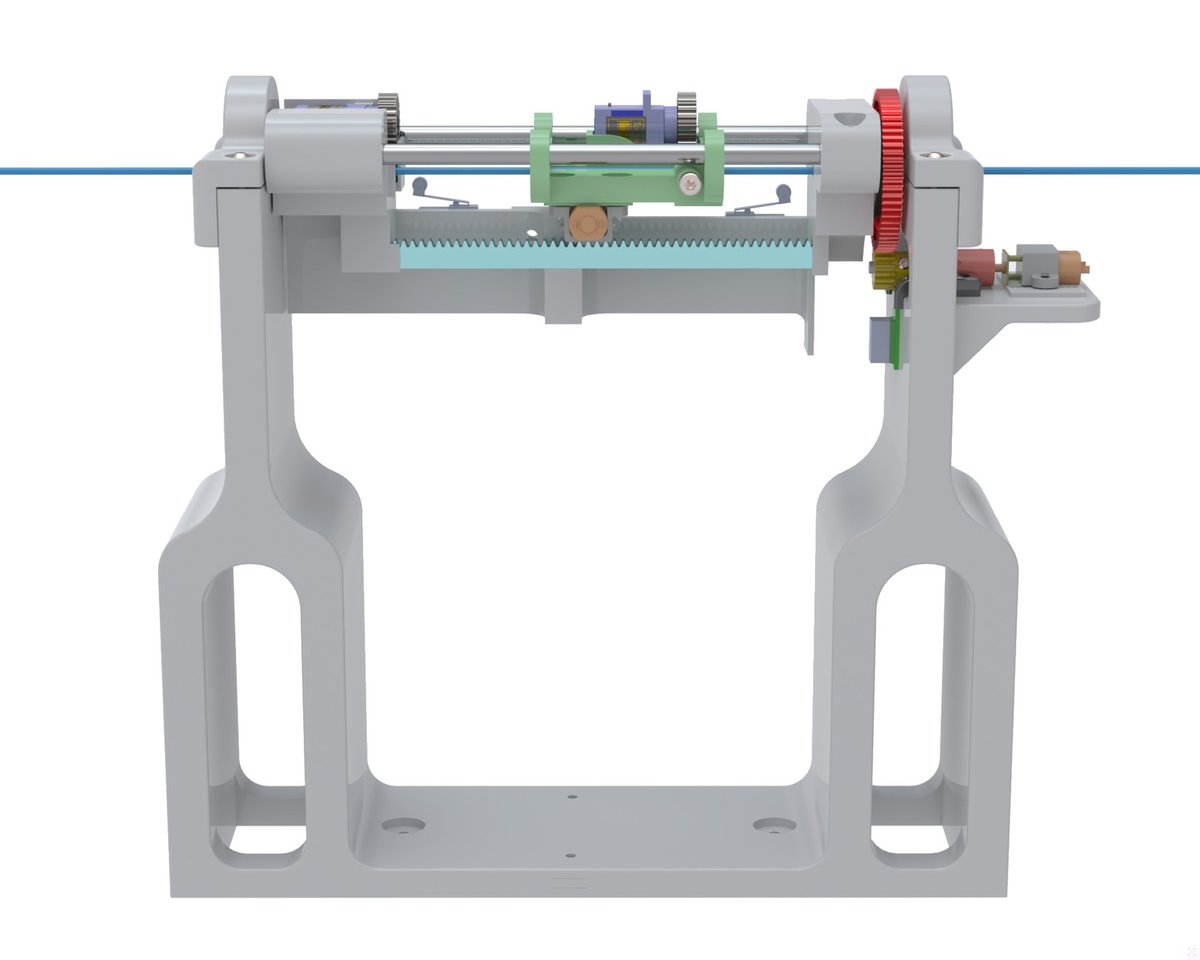
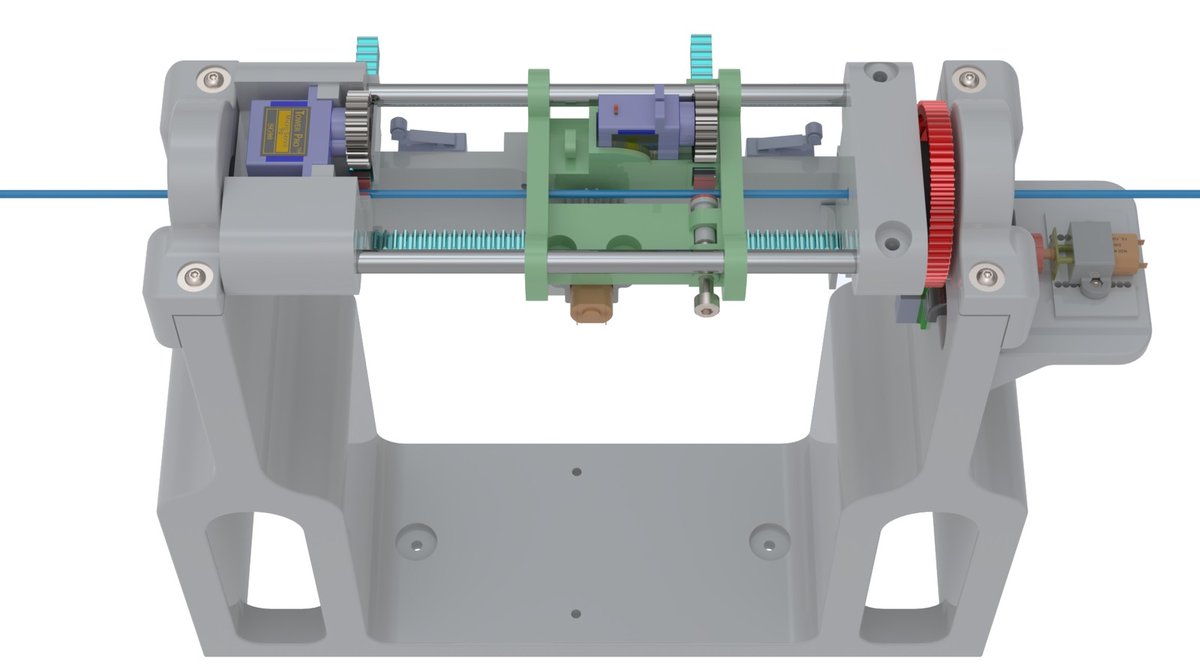
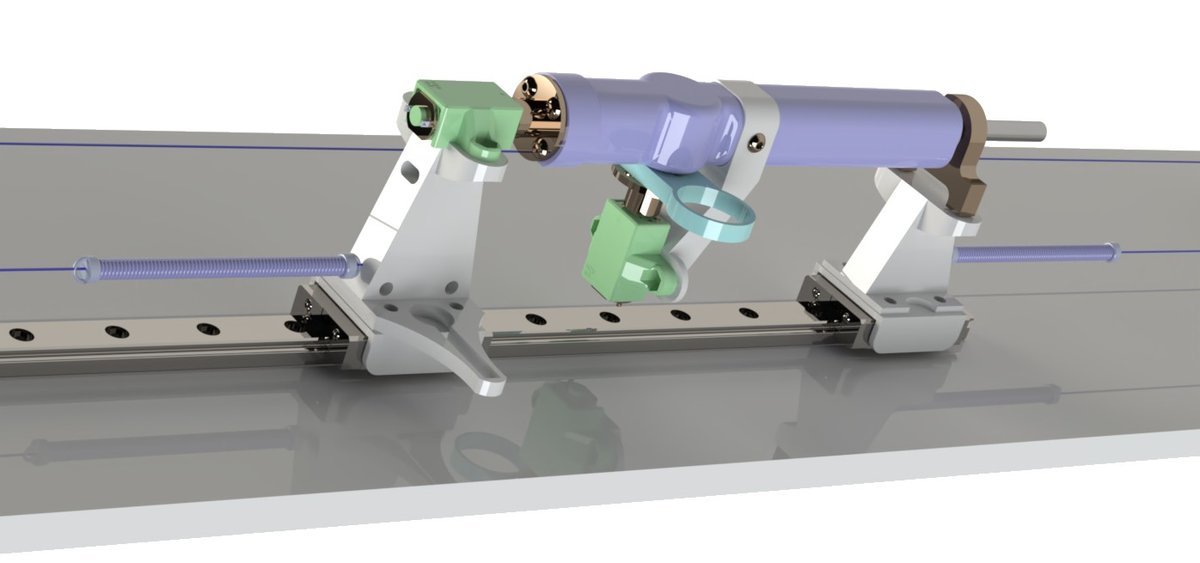
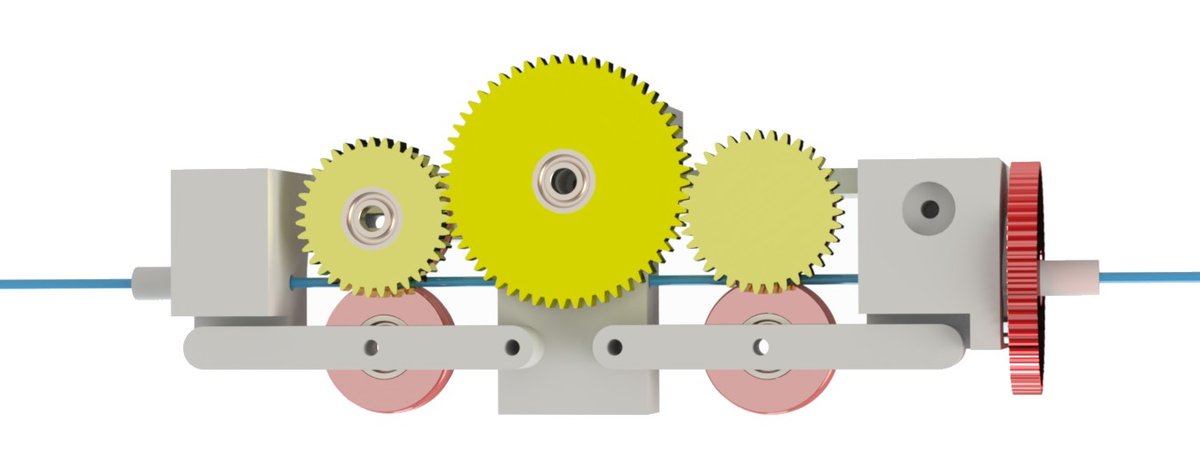
- clamp-relay (grip-insert-release with rack gears; feeder supports the shaft)
- Twist (rotation)
- DC motors turn the held handle
- Device range
- one ablation catheter
- Target anatomy
- cardiac ablation catheterisation
Sensing and interface
- Force sensing
- N.R. (motor characterisation)
- Leader and haptics
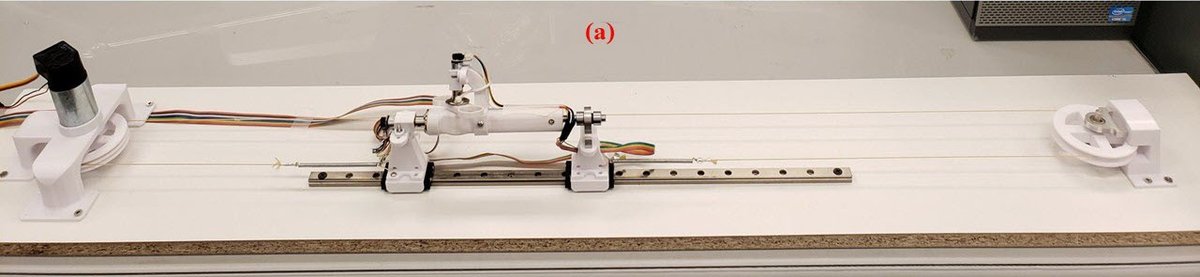
- yes: master models handle, shaft and knob with reaction motors on rail (3 DOF force feedback)
- Imaging
- N.R.
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found (master tested earlier in a simulated environment, ref [39] of the paper)
- Sim-trained controller
- none found
Versions
- Lineage
- Althea II (earlier, year N.R.); 2024 grip-insert-release follower
Sources
- A Master-Follower Teleoperation System for Robotic Catheterization: Design, Characterization, and Tracking Control · link [nazari2024_master]
Notes
- Notes
- Steerable EP catheter handle driver; boundary case for the endovascular scope.
This record
- Read level
- full
- Picture
- nazari2024_master Fig. 3 (follower CAD: handler, feeder, linear rail; embedded 1868x695) ↗ — licence: arXiv non-exclusive distribution licence (authors' copyright); grade B
- Picture changes
- native extract; cropped; 30 px white padding at the bottom; not upscaled
- Found by
- academic: Search of academic bedside robots.
- Data
- JSON · YAML:
records/robots/toronto_nazari2024.yaml - Correction
- Suggest a correction [repository not created yet]