Academic bedside robots · hit_fu2011
HIT catheter robot
HIT master-slave robotic catheter system for a steerable pull-wire catheter
 1 / 3
- Family
- Academic bedside robots (academic)
- Devices
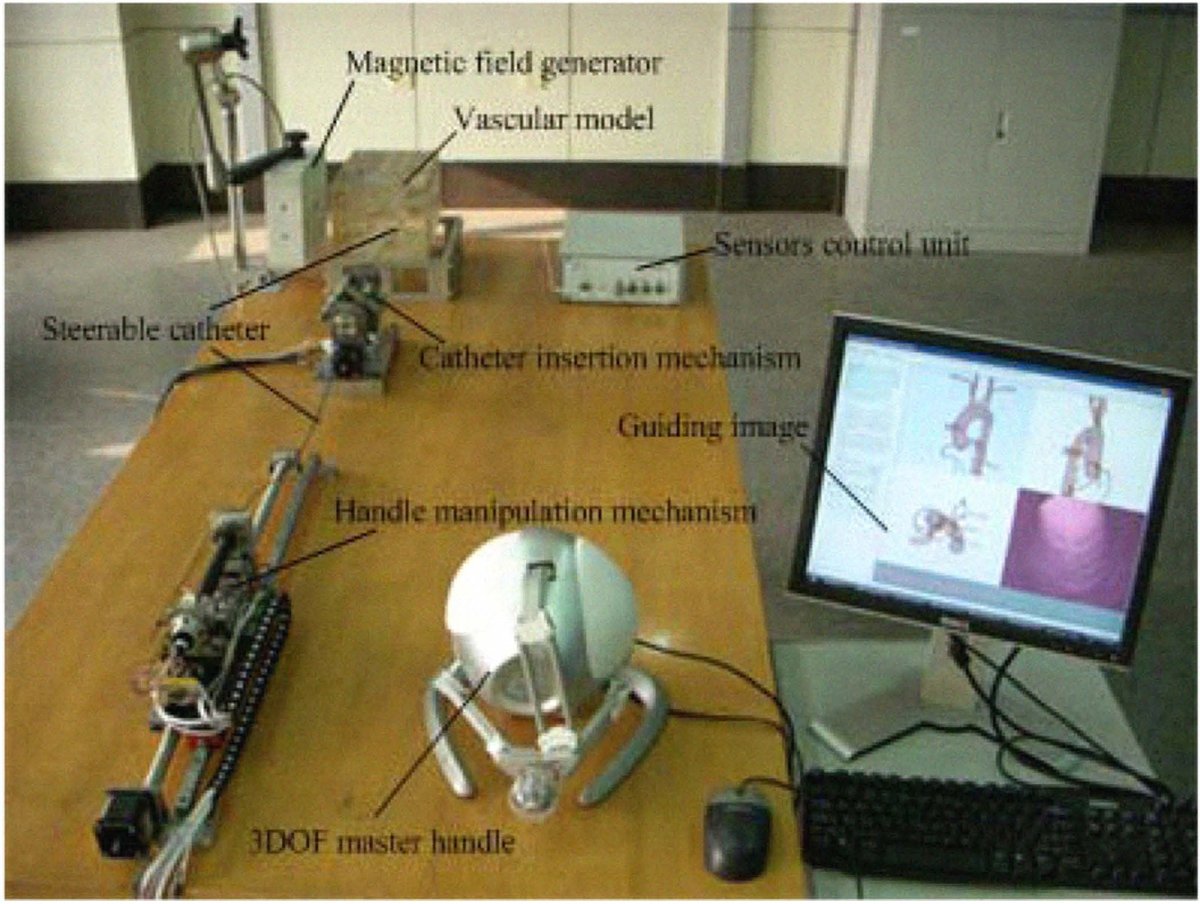
- custom 7 Fr single-curve pull-wire steerable catheter with two 5-DOF magnetic tracking sensors, two electrodes and a thermocouple (fu2011_development Sec. III)
- Degrees of freedom
- 3 (push/pull, rotate, bend; fu2011_development Sec. II-C)
- Push
- Friction rollers
- Twist
- Rotating drive unit
- Tested up to
- Phantom
- Sim-to-real
- None found — No simulation-trained controller found for this robot.
Testing
- Highest level
- Phantom
- What was tested
- thorax vascular phantom (Shelley Medical), catheterisation to the brachiocephalic trunk (fu2011_development Sec. VI)
- Key numbers
- image-sensor registration error mean 0.19 mm, RMS 0.49 mm, SD 0.46 mm over 700 wall points (fu2011_development Sec. VI, Fig. 9)
Mechanism
- Push (translation)
- friction-roller
- Twist (rotation)
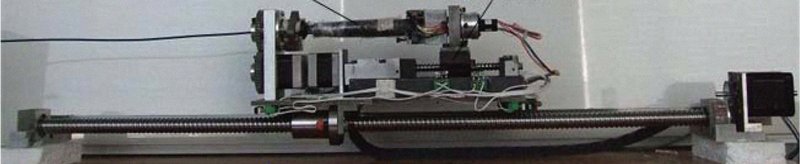
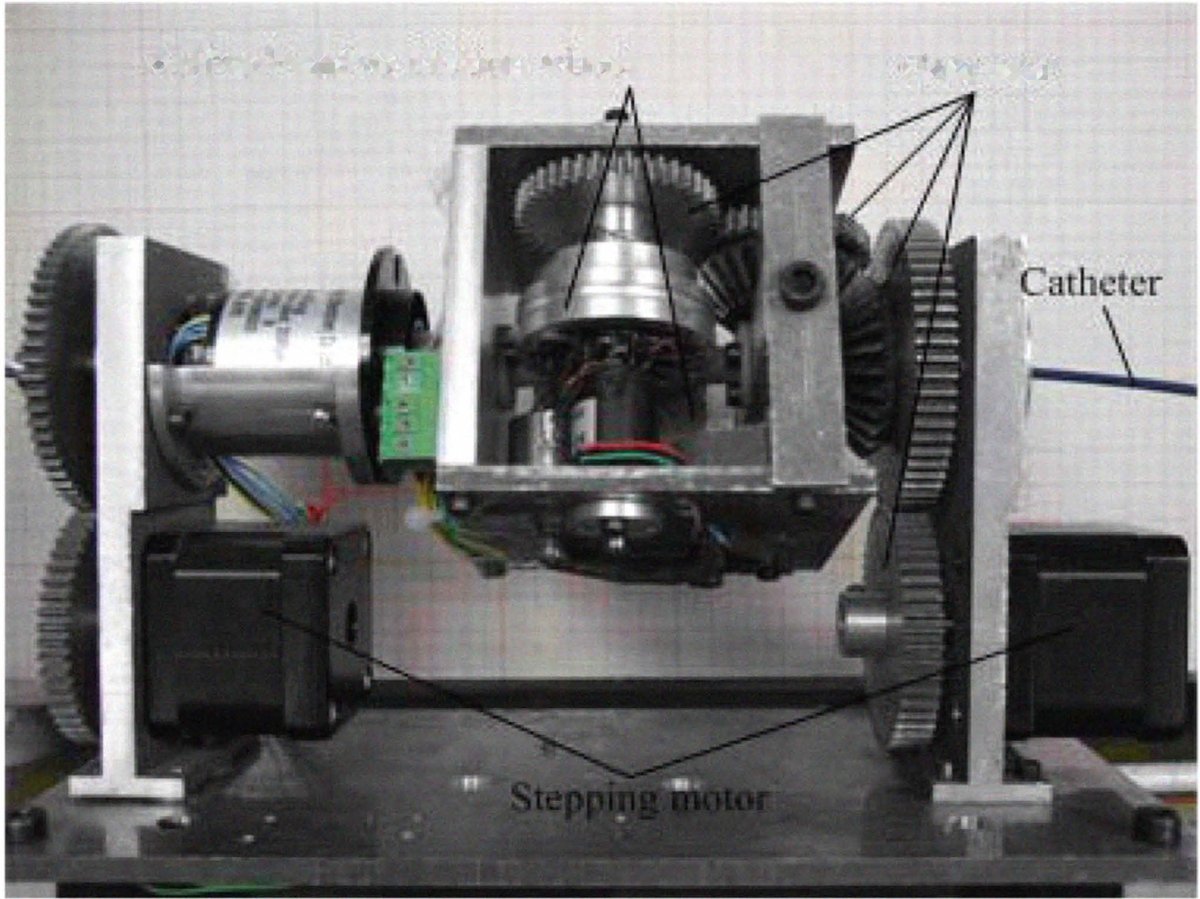
- other: both stepping motors at equal speed rotate the whole friction-wheel unit about the catheter (fu2011_development Sec. IV); bending by a lead-screw slide unit moving the handle sleeve
- Device range
- N.R.
- Target anatomy
- thoracic/cardiac vessels (thorax vascular phantom, brachiocephalic trunk)
Sensing and interface
- Force sensing
- proximal: two force-sensing elements between the inner and outer wheel of the active friction wheel (fu2011_development Fig. 6)
- Leader and haptics
- Novint Falcon 3-DOF handle with force feedback (fu2011_development Fig. 2)
- Imaging
- EM magnetic tracking + MR-derived 3D guiding image (20 slices); intended to reduce X-ray use
- Sterility
- N.R.
Size
- Footprint (mm)
- N.R.
- Mass (kg)
- N.R.
Simulation
- Simulation model
- none found
- Sim-trained controller
- none found
Versions
- Lineage
- 2008-2010 active/steerable catheter navigation studies (Fu et al., IJMRCAS 2008-2009, titles); 2011 robotic catheter system (fu2011_development, full); 2011 master-slave catheterisation system (fu2011_masterslave, title)
Sources
- Development of a novel robotic catheter system for endovascular minimally invasive surgery · The 2011 IEEE/ICME International Conference on Complex Medical Engineering, 2011 · doi:10.1109/iccme.2011.5876772 [fu2011_development]
- The master-slave catheterisation system for positioning the steerable catheter · International Journal of Mechatronics and Automation, 2011 · doi:10.1504/ijma.2011.045271 [fu2011_masterslave]
Notes
- Notes
- Anzhu Gao later moved to SJTU (row sjtumr_huang2022). The full-system photo (Fig. 1) and insertion mechanism (Fig. 5) carry baked-in labels.
This record
- Read level
- full — full (fu2011_development, OCR of a scanned PDF); title (fu2011_masterslave)
- Picture
- fu2011_development Fig. 7 handle manipulation mechanism (native scan raster p. 3) ↗ — licence: publisher copyright; grade C
- Picture changes
- native extract; cropped below baked-in text labels and above a blue arrow; two thin leader lines on the robot left; not upscaled
- Found by
- gap: Gap searches for robots the other searches missed.
- Data
- JSON · YAML:
records/robots/hit_fu2011.yaml - Correction
- Suggest a correction [repository not created yet]